Hello,Hallo
Heute Vormittag hatte ich endlich mal wieder Zeit mich mit den Motoren zu beschäftigen.
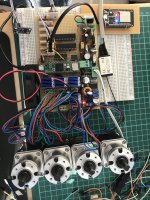
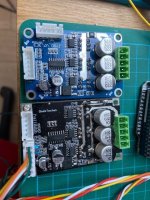
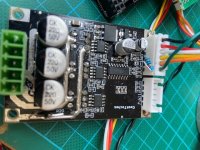
Bin noch nicht großartig weiter gekommen. Vom PCB habe ich mal alles entfernt außer das Uhrenmodul und mein selbstgebautes Adapterboard das Treiberboard und Motor.
Beim Einschalten läuft der Motor kurz an , dann kommt ein „Piep“ und er bleibt stehen.
Dies konnte ich auch mit messen zwischen EL und GND nachvollziehen(Spannung da / Spannung weg). Wenn ich mit dem seriellen Monitor mitlese kommt folgendes:
10:33:05.847 -> RESET cause: unknown
10:33:05.847 -> Ardumower Sunray,1.0.234
10:33:05.847 -> compiled for: Arduino Due
10:33:05.847 -> MOTOR_DRIVER_BRUSHLESS: yes
10:33:05.863 -> enableCharging 0
10:33:05.863 -> trying to detect Bluetooth 4.0/BLE module (make sure your phone is NOT connected)9600...
10:33:06.324 -> BLE: AT
10:33:06.324 -> At
⸮trying to detect Bluetooth 4.0/BLE module (make sure your phone is NOT connected)115200...
10:33:07.070 -> BLE: AT
10:33:07.070 -> AT
10:33:07.251 -> error: no BLE module found!
10:33:07.251 -> SERIAL_BUFFER_SIZE=1024 (increase if you experience GPS checksum errors)
10:33:07.251 -> -----------------------------------------------------
10:33:07.251 -> UBLOX::begin serial
10:33:07.251 -> UBLOX::begin
10:33:07.251 -> sizeof Point=4
10:33:07.251 -> map dump - mapCRC=0
10:33:07.251 -> points:
10:33:07.251 -> perimeter pts: 0
10:33:07.251 -> exclusion pts: 0
10:33:07.251 -> exclusions: 0
10:33:07.251 -> dock pts: 0
10:33:07.251 -> mow pts: 0
10:33:07.251 -> free pts: 0
10:33:07.251 -> mowPointsIdx=0 dockPointsIdx=0 freePointsIdx=0 wayMode=3
10:33:07.763 -> WIFI (ESP8266) not found! If the problem persist, you may need to flash your ESP to firmware 2.2.1
10:33:07.763 -> MPU ID=0x0
10:33:07.763 -> MPU6050/9150/9250/9255 not found - Did you connect AD0 to 3.3v and choose it in config.h?
10:33:10.297 -> WARN: PID unmet cycle time Ta=3.03 TaMax=0.07
10:33:10.297 -> WARN: PID unmet cycle time Ta=3.04 TaMax=0.07
10:33:10.297 ->
10:33:10.297 -> 0:0:5 ctlDur=0.00 op=0 freem=81831 sp=2 bat=19.31(0.07) chg=0.00(0.00) tg=0.00,0.00 x=0.02 y=0.00 delta=0.11 tow=0 lon=0.00000000 lat=0.00000000 h=0.0 n=0.00 e=0.00 d=0.00 sol=0 age=5.98
10:33:15.305 -> 0:0:10 ctlDur=0.02 op=0 freem=81831 sp=2 bat=19.31(3.30) chg=0.15(0.04) tg=0.00,0.00 x=0.02 y=0.00 delta=0.11 tow=0 lon=0.00000000 lat=0.00000000 h=0.0 n=0.00 e=0.00 d=0.00 sol=0 age=10.99
Die rot markierte Warnung kann ich überhaupt nicht deuten , vielleicht weiß von euch jemand was diese zu bedeuten hat.
Mache ich einen Odemetrietest mit AT+E passiert erstmal nichts aber wenn ich mal kurz die Spannung (24V) wegnehme und zuschalte Läut der Motor zehn Umdrehungen und ich sehe die Ticks .
Ein weiters Problem ist das der rechte Motor verkehrt rum dreht egal was ich in der config.h
(#define MOTOR_RIGHT_SWAP_DIRECTION 1 // uncomment to swap right motor direction)einstelle.
Ich hoffe es hat jemand ein paar Tipps für mich.
Dank Waage
for the direction, please check the voltage on the Z/F pin of the BLDC. You should have 5V in one direction and 0V in the other.
I had a issue with a version of BLDC, it was not 0V, I had to change one resistor on the BLDC board (330 ohm to 10K) to allow to drive to 0
Good luck