Du verwendest einen veralteten Browser. Es ist möglich, dass diese oder andere Websites nicht korrekt angezeigt werden.
Du solltest ein Upgrade durchführen oder einen alternativen Browser verwenden.
Du solltest ein Upgrade durchführen oder einen alternativen Browser verwenden.
Arctic Hare mod by Jussi
- Ersteller jussip
- Erstellt am
Bernard, your code. do you use it with left and right perimeter coil or just one in middle?
I just added second mower motor to code and noticed that there was perimeterCenter on pin A6. I commented that out and its now second mow motor sense pin.
Other thing, mower.cpp and mower.h, theres same pin #defines on both files.
Timer setting "start dist/station" what units these are? minutes, meters? I assume that this defines starting point/area
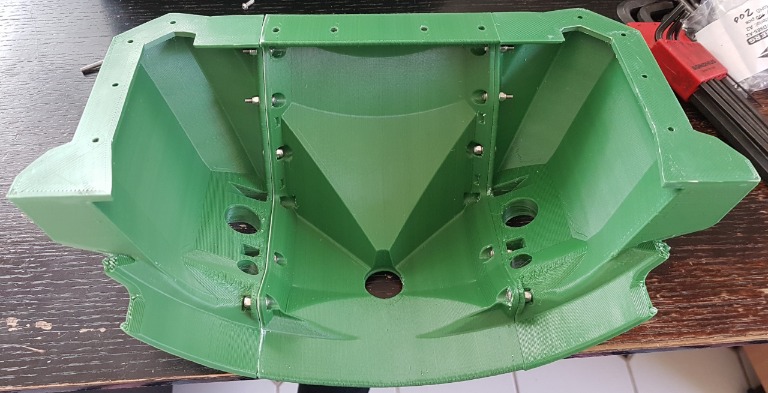
Almost there.. Nose is printed and partly assembled  Bigger holes are for us-sensors and smaller ones for charging contacts. Also place for d-shaped bumper tube




Attachment: https://forum.ardumower.de/data/media/kunena/attachments/4741/2019-04-2114.16.31.jpg/
Bigger holes are for us-sensors and smaller ones for charging contacts. Also place for d-shaped bumper tube
Attachment: https://forum.ardumower.de/data/media/kunena/attachments/4741/2019-04-2114.16.31.jpg/
Zuletzt bearbeitet von einem Moderator:
Hi
Only left input on PCB1.3 is used by my code same as Azurit ( And the coil is center on the chassis) ,But be carrefull that what i have post is only the Due part and i never test it without the Raspberry Pi.(But normaly only the RFID parts is manage by the Pi).
This Code and the By Lane Mowing can only work well if you have a GY88 IMU.
The Center Coil Input on PCB is never use by all firmware i have see in this forum ,so you can use this input without issue.
The 2 Coils are used by Roland Raindancer firmware, so if you want to test it you need to have the left and right coil on your chassis connected to left and right on PCB1.3.
The result of the 2 coil reading help a lot in the mowing behaviour,( when the mower hit the perimeter the roll angle is easier to define) and the random mowing is better than with only one coil.
I change this.
.Bernard, your code. do you use it with left and right perimeter coil or just one in middle?
Only left input on PCB1.3 is used by my code same as Azurit ( And the coil is center on the chassis) ,But be carrefull that what i have post is only the Due part and i never test it without the Raspberry Pi.(But normaly only the RFID parts is manage by the Pi).
This Code and the By Lane Mowing can only work well if you have a GY88 IMU.
The Center Coil Input on PCB is never use by all firmware i have see in this forum ,so you can use this input without issue.
The 2 Coils are used by Roland Raindancer firmware, so if you want to test it you need to have the left and right coil on your chassis connected to left and right on PCB1.3.
The result of the 2 coil reading help a lot in the mowing behaviour,( when the mower hit the perimeter the roll angle is easier to define) and the random mowing is better than with only one coil.
It's meter and yes it's define the starting point,you can also find area or beacon in the Timer for high precision starting,but this work only with Rfid and PITimer setting "start dist/station" what units these are? minutes, meters? I assume that this defines starting point/area
Ooops :huh:Other thing, mower.cpp and mower.h, theres same pin #defines on both files.
I change this.
Concerning the US SENSOR location.
It's depend on how there are manage.
Into Azurit when trigger the speed is reduce and the mower run until bumper is trigger so your location can work but it's possible that they are Always trigger on high grass.
Into my version when trigger the distance is recorded and the mower use Odometry to brake slowly and stop and reverse before hit the obstacle .
So if you use the same US than mine the location on the chassis is not perfect like that because there are locate really near the ground on your chassis, so certainly you need some test to find perfect location and maybe print again some parts
These us-sensors are waterproof and blind under 20-25cm also beam is very narrow. Working well inside but not tested real outside conditions yet, we'll see how it goes. I have few kilos spare parts waiting to be printed
Can you share that Pi-code also?
I have to study more raindancer code, don't know yet how to add second motor current sensing. It's totally different code but definitely worth to try.
Can you share that Pi-code also?
I have to study more raindancer code, don't know yet how to add second motor current sensing. It's totally different code but definitely worth to try.
In raspbian lite you Don't have the desktop so it's not possible to run the software .raspbian lite
In fact i Don't understand how CC can work if your garden is not totaly WIFI cover by your box ??
So to simplify my soft can work on the Pi zero W (Certainly Slowly) but You need to use the Raspbian Stretch with desktop: https://www.raspberrypi.org/downloads/raspbian/ And if you Don't have a screen you need to install the RaspAp or other to connect to the mower and see the interface eveywhere in your garden.
By
.
If you Don't have a screen on the mower you need to use VNC or
Garden is quite well wifi-covered, no screen on zero, it is mainly supposed to be onboard camera. Maybe its time to put 3b+ in, it would be nice to have some kind of remote monitoring system
I need that 'starting point' -feature for sure, theres one narrow spot and I doubt that w/o it mower wount newer found its way trough..
I need that 'starting point' -feature for sure, theres one narrow spot and I doubt that w/o it mower wount newer found its way trough..
Hi
Here The Pi code for Azuritber (do not work with azurit1.10 see paddy CC for it).
Copy the PiArdumower folder into Pi/Documents
Edit config.py to deactivate all except the Due
and start with python3 Pyardu90.py
Into Azuritber the Usepi need to be set to Yes with Arduremote into Setting R/C and the Pi is connected on the DUE NativeUsb port.
Plot need KST-plot (see internet) on the Pi or you need to use Excel to open the file generate.
By.

Attachment: https://forum.ardumower.de/data/media/kunena/attachments/3545/PIAZURIT.zip/
Here The Pi code for Azuritber (do not work with azurit1.10 see paddy CC for it).
Copy the PiArdumower folder into Pi/Documents
Edit config.py to deactivate all except the Due
and start with python3 Pyardu90.py
Into Azuritber the Usepi need to be set to Yes with Arduremote into Setting R/C and the Pi is connected on the DUE NativeUsb port.
Plot need KST-plot (see internet) on the Pi or you need to use Excel to open the file generate.
By.
Attachment: https://forum.ardumower.de/data/media/kunena/attachments/3545/PIAZURIT.zip/
Zuletzt bearbeitet von einem Moderator:
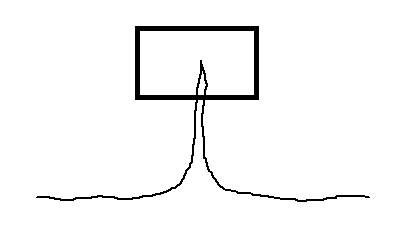
Does it work if station and perimeter wire is that way? Mower can drive to station at both directions?
Attachment: https://forum.ardumower.de/data/media/kunena/attachments/4741/perimeter_wire.png/
Attachment: https://forum.ardumower.de/data/media/kunena/attachments/4741/perimeter_wire.png/
Zuletzt bearbeitet von einem Moderator:
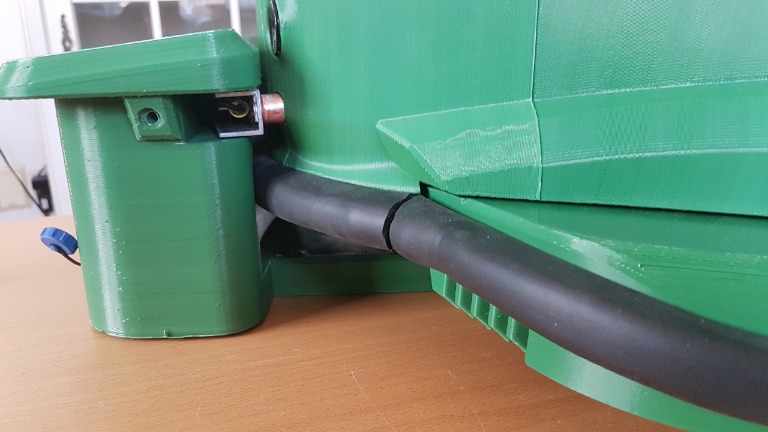
Mower is now almost completed. Only thing to do for now is d-tube installation better, glue wont hold enough. I'm thinking zip ties to end of tubes where gaps are.
More pictures is on thingiverse: https://www.thingiverse.com/thing:3563727


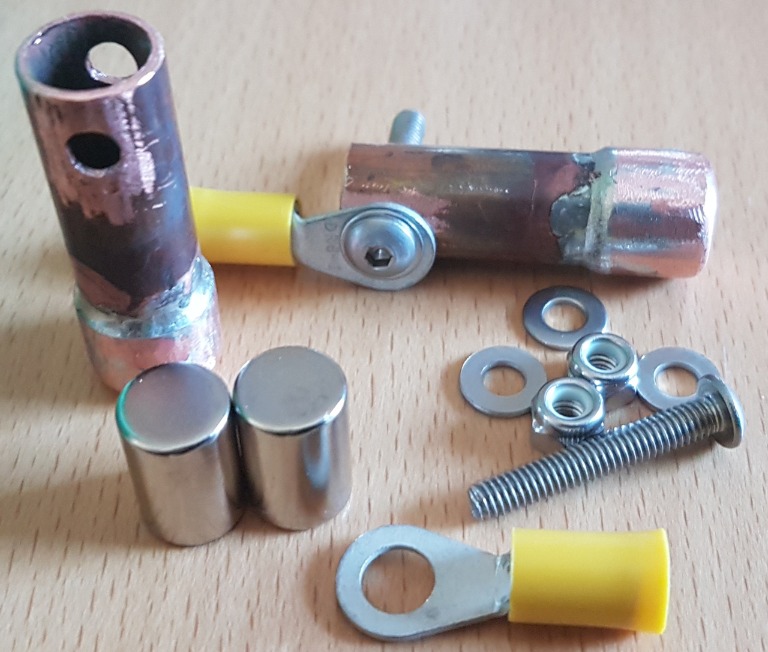
Charging contacts 12 mm copper pipe and capillary hats, magnets inside.


Test video with Bernards code. I had to lower rpm's to 20 and pwm to 150 because of low friction on the floor
[video]https://www.youtube.com/watch?v=zPInJqTAmYc[/video]
Attachment: https://forum.ardumower.de/data/media/kunena/attachments/4741/2019-04-2813.43.40.jpg/
More pictures is on thingiverse: https://www.thingiverse.com/thing:3563727
Charging contacts 12 mm copper pipe and capillary hats, magnets inside.
Test video with Bernards code. I had to lower rpm's to 20 and pwm to 150 because of low friction on the floor
[video]https://www.youtube.com/watch?v=zPInJqTAmYc[/video]
Attachment: https://forum.ardumower.de/data/media/kunena/attachments/4741/2019-04-2813.43.40.jpg/
Zuletzt bearbeitet von einem Moderator:
Hi.
Cool .
Concerning the charging station contact:
Maybe you need to enlarge them or create a full perfect flat surface on the doking area to have a perfect horizontal mower.
I am also surprise that the code work without IMU, Rfid, Pi etc and low ticks/cm on Odometry.
You use the random Mode (This mode never stop the Wheel while rotate) and maybe in the motor Control you need to adjust the Speed Odo Minimum and Maximum to have more smooth motor transition.
For the perimeter wire you have the perfect Area to do some test and you can see that if you put 2 parallel wire togetther the coil ignore them totaly It's usefull arround tree, flower etc....
For a correct docking the Bumper need to be trigger when hit the station.
Congratulation.


If the sonar is connected you can dock at the speed you want.
I use a 1.7 diviser
Change ActualSpeedPeriPWM = MaxSpeedperiPwm / 1.7; by the speed you want.
Remember that the station is detected by the Bumper.
Code:
void Robot::checkSonarPeriTrack() {
  if (!sonarUse) return;
  if (millis() < nextTimeCheckSonar) return;
  nextTimeCheckSonar = millis() + 200;
  if (millis() > timeToResetSpeedPeri) {
    timeToResetSpeedPeri = 0; //brake the tracking during 6 secondes
    ActualSpeedPeriPWM = MaxSpeedperiPwm ;
  }
  if (sonarRightUse) sonarDistRight = readSensor(SEN_SONAR_RIGHT);
  //if (sonarLeftUse) sonarDistLeft = readSensor(SEN_SONAR_LEFT);
  //if (sonarCenterUse) sonarDistCenter = readSensor(SEN_SONAR_CENTER);

  //if (sonarDistCenter < 30 || sonarDistCenter > 150) sonarDistCenter = NO_ECHO; //need to be adjust if sonar is directly in front of mower 25Cm in my case
  if (sonarDistRight < 30 || sonarDistRight > 150) sonarDistRight = NO_ECHO; // Object is too close to the sensor JSN SR04T can't read <20 CM . Sensor value is useless
  //if (sonarDistLeft < 30 || sonarDistLeft  > 150) sonarDistLeft = NO_ECHO;

  //disabled the left and center sonar during tracking with this line
  sonarDistLeft = NO_ECHO;
  sonarDistCenter = NO_ECHO;

  if ((sonarDistRight != NO_ECHO) && (sonarDistRight < sonarTriggerBelow))  {
    //if (((sonarDistCenter != NO_ECHO) && (sonarDistCenter < sonarTriggerBelow))  ||  ((sonarDistRight != NO_ECHO) && (sonarDistRight < sonarTriggerBelow)) ||  ((sonarDistLeft != NO_ECHO) && (sonarDistLeft < sonarTriggerBelow))  ) {
    setBeeper(1000, 50, 50, 60, 60);
    nextTimeCheckSonar = millis() + 2500;  //wait before next reading
    timeToResetSpeedPeri = millis() + 3000; //brake the tracking during 6 secondes
    ActualSpeedPeriPWM = MaxSpeedperiPwm / 1.7;
  }
}
I use a 1.7 diviser
Change ActualSpeedPeriPWM = MaxSpeedperiPwm / 1.7; by the speed you want.
Remember that the station is detected by the Bumper.
Ok, thanks. I'll check that when station is installed. Theres raspi 3b+ now installed and PiArdumower works great. Do you use gps via raspi? I cant get it work via pcb, tx3 and rx3 pins are crossed bit still nothing. gps works, tested it on nano
Front wheel shaft is not strong enough, its made from 5 mm stainless threaded rod. It bends when hit something bump etc. I have to make new, 8 mm rod this time. Mower is quite heavy, around 20 kg I think
Front wheel shaft is not strong enough, its made from 5 mm stainless threaded rod. It bends when hit something bump etc. I have to make new, 8 mm rod this time. Mower is quite heavy, around 20 kg I think