ZS-X12H Treiber und Sunray

YL02D is easier for 2 wheels drive, but i don't know how to manage the motor right or left sense, only the sense is measure on the power input of the board.
Other is the version : i see 4 version with 2.5V and 5V or with or without safe start that i don't really understand.
So i have ordered the 457E 2.5V without safe start, and i give you a feedback when i test it.

In all case after very long test duration (more the 500 hours of mowing on MI632) of ZSX11H, i need to say that it work well except the safety feature in some case.
It can freeze sometime after 1 or 3 hours of mowing ,always on hard move with high sense, and this append more often with smaller ZSX12-H.
Certainly i need to try to shunt the R05 sense resistor locate on the PCB to see if it's only sense protection ???.

Also freeze is more present if i use the brake feature of the board, and i also never see the PCB hot.
 
So i have ordered the 457E 2.5V without safe start, and i give you a feedback when i test it.
If I understand the description correctly in the 2.5V Version the Z/F input have to be controlled with 0-5V why? And what about speed input is that also TTL 5V logic? If that the case, the 2.5V version doesn‘t make any sence
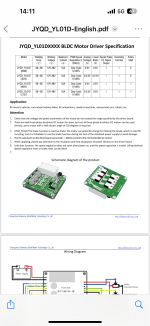
 
I didn't understand the security function either. That's why I'm leaning toward the version without the security feature.
If I understand the description correctly in the 2.5V Version the Z/F input have to be controlled with 0-5V why? And what about speed input is that also TTL 5V logic? If that the case, the 2.5V version doesn‘t make any sence
yes, the discription is not very clear in that case. Lets try the 5V-Version. In this case we may test the 2.5V- (@bernard) and the 5V-Version.
correction: I think, the 2.5V-Version is the right one for the PICO, cause speed- and brake-controll are working with 2.5V.
 
Zuletzt bearbeitet:
I didn't understand the security function either. That's why I'm leaning toward the version without the security feature.

yes, the discription is not very clear in that case. Lets try the 5V-Version. In this case we may test the 2.5V- (@bernard) and the 5V-Version.
correction: I think, the 2.5V-Version is the right one for the PICO, cause speed- and brake-controll are working with 2.5V.
I ordered the 2.5V version to directly correct 3.3V controller to the PCB with 2 small resistor to reduce 3.3V to 2.5V.
With 5V version you need to use a 5V controller or use a level shifter ,or do not have max speed.

Now for the safe start : In the past i test green driver JYQD V1 and they can't work on wheel because it take sometime 1 or 2 seconds to accelerate and it's not compatible with our firmware. It's the reason i prefer to avoid this feature.
 
I've now published my current PID configuration on GitHub. The base is the landrumower from @EinEinfach. There are two separate PIDs for speed and brake. I don't know if this is the best way, but for now, it's the best for me. It's only been tested with @bernard's Bottle test. So I don't know if it works in real life.
 
Moin,
falls Änderungen an der Landrumower PCB gemacht werden sollen/müssen, könnt ihr mir das gerne mitteilen.
Ich habe schon angefangen und die Motoranschlüsse korrigiert, durch ein Update von KiCad muss ich aber noch mal anfangen, da da einiges nicht mehr funktioniert.
 
Danke für das Angebot. Allerdings bin ich für meinen Teil leider noch nicht so weit. Ich kämpfe immer noch mit der Bremse. Mit Levelshifter geht es bei mir gar nicht und ohne Levelshifter geht es zwar. Das Ergebnis ist aber nicht befriedigend. Ich habe den Aufbau jetzt erstmal für einen Moment zur Seite gelegt, um nochmal grundsätzlich über das Konzept nachzudenken...
Bin sehr gespannt auf die Erfahrungen von @bernard mit dem JYQD-YL01D.
 
Hi,
ärgere mich gerade mit der Drehrichtung der Motoren rum. Sie drehen nur in eine Richtung.
Ich nutze PCB-Layout und Code von @EinEinfach (danke dafür) und den ZS-X11H v2.
Ich hatte gelesen, dass @Silberstreifen auch das Drehrichtungsproblem hatte. (Post #24)
Wie kann ich das lösen, bzw. wie habt ihr das gelöst?
Danach würde ich auch gern den PID für meine Motoren einstellen.
Gibt es irgendwo eine Beschreibung für den Testaufbau?
Danke schon mal.
 
Ich nutze PCB-Layout und Code von @EinEinfach (danke dafür) und den ZS-X11H v2.
Ich hatte gelesen, dass @Silberstreifen auch das Drehrichtungsproblem hatte.
Ich gehe davon aus, dass du den Python-Code nutzt. Ich habe den C-Code genutzt. Der ist aber noch "work in progress", also nicht einsetzbar. Ich gehe davon aus, dass @EinEinfach mit dem Python-Code fährt. Ich habe meine Brushless-Ambitionen zunächst zurückgestellt, da ich Unmengen von Brushed-Komponenten aus einem aufgegebenen Projekt geerbt habe. Für mich laufen den Brushed-Motoren auf hügeligem Gelände deutlich präziser und sind sehr viel einfacher zu handhaben.
 
Ich gehe davon aus, dass du den Python-Code nutzt. Ich habe den C-Code genutzt. Der ist aber noch "work in progress", also nicht einsetzbar. Ich gehe davon aus, dass @EinEinfach mit dem Python-Code fährt. Ich habe meine Brushless-Ambitionen zunächst zurückgestellt, da ich Unmengen von Brushed-Komponenten aus einem aufgegebenen Projekt geerbt habe. Für mich laufen den Brushed-Motoren auf hügeligem Gelände deutlich präziser und sind sehr viel einfacher zu handhaben.
Danke für deine Antwort.
Ich habe den C-Code genutzt und die PID Werte aus Sunray.
Hatte das so verstanden, dass das wohl bei @EinEinfach so auch schon läuft.
Oder habe ich mich da verlesen?
 
Die ist nicht fertig, da läuft noch überhaupt nichts.
Am besten du nimmst die V1.X, V2.X hat zwar mehr Feautures und deutlich sauberer programmiert, entpuppte sich aber leider als eine Sackgasse, deswegen der Wechsel auf 3.X und somit auch ein Wechsel auf C++
 
Ach, schade.
mit dem Phyton auf dem pico bekomme ich nach dem booten des PI5 folgende Fehler über den Seriellen Monitor des pico:
Received data are corrupt. Data: AT+S
. Exception: substring not found
Received data are corrupt. Data: AT+S2
. Exception: substring not found
Habe keine Ahnung woran das lieget???
Hab nur den pico C++ gegen pico phyton getauscht.
 
firmware V2 und sunray 1.0.324
Habe Cassandra deaktiviert - jetzt erhalte ich zwar keine Fehlermeldungen mehr, aber die Motoren drehen nicht/lassen sich nicht ansprechen - auch nicht über service.h .. 1) .. 4) Run sunray executable with motor test.
 
Zuletzt bearbeitet:
Oben