
EinEinfach
Well-known member
Ich habe den YL01D angefragt, Rest per PNBei den JYQD-YL01D würde ich 3 nehmen.
Ich habe den YL01D angefragt, Rest per PNBei den JYQD-YL01D würde ich 3 nehmen.
If I understand the description correctly in the 2.5V Version the Z/F input have to be controlled with 0-5V why? And what about speed input is that also TTL 5V logic? If that the case, the 2.5V version doesn‘t make any senceSo i have ordered the 457E 2.5V without safe start, and i give you a feedback when i test it.

yes, the discription is not very clear in that case. Lets try the 5V-Version. In this case we may test the 2.5V- (@bernard) and the 5V-Version.If I understand the description correctly in the 2.5V Version the Z/F input have to be controlled with 0-5V why? And what about speed input is that also TTL 5V logic? If that the case, the 2.5V version doesn‘t make any sence
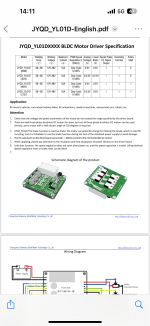
I ordered the 2.5V version to directly correct 3.3V controller to the PCB with 2 small resistor to reduce 3.3V to 2.5V.I didn't understand the security function either. That's why I'm leaning toward the version without the security feature.
yes, the discription is not very clear in that case. Lets try the 5V-Version. In this case we may test the 2.5V- (@bernard) and the 5V-Version.
correction: I think, the 2.5V-Version is the right one for the PICO, cause speed- and brake-controll are working with 2.5V.
yes, now it works. But not like a charme. Can't find good parameters for the PID. I will keep trying.You also need to add a Pull down or Pull up resistor on the brake line .
If i remember my test : pwm on brake was OK.
Ich gehe davon aus, dass du den Python-Code nutzt. Ich habe den C-Code genutzt. Der ist aber noch "work in progress", also nicht einsetzbar. Ich gehe davon aus, dass @EinEinfach mit dem Python-Code fährt. Ich habe meine Brushless-Ambitionen zunächst zurückgestellt, da ich Unmengen von Brushed-Komponenten aus einem aufgegebenen Projekt geerbt habe. Für mich laufen den Brushed-Motoren auf hügeligem Gelände deutlich präziser und sind sehr viel einfacher zu handhaben.Ich nutze PCB-Layout und Code von @EinEinfach (danke dafür) und den ZS-X11H v2.
Ich hatte gelesen, dass @Silberstreifen auch das Drehrichtungsproblem hatte.
Danke für deine Antwort.Ich gehe davon aus, dass du den Python-Code nutzt. Ich habe den C-Code genutzt. Der ist aber noch "work in progress", also nicht einsetzbar. Ich gehe davon aus, dass @EinEinfach mit dem Python-Code fährt. Ich habe meine Brushless-Ambitionen zunächst zurückgestellt, da ich Unmengen von Brushed-Komponenten aus einem aufgegebenen Projekt geerbt habe. Für mich laufen den Brushed-Motoren auf hügeligem Gelände deutlich präziser und sind sehr viel einfacher zu handhaben.