
Ich habe gestern immer den MQTT Explorer beobachtet und da kam halt nichts mehr, sobald ich bestimmte Karten in Cassandra native ausgewählt hatte. Cassandra läuft ansonsten normal weiter.


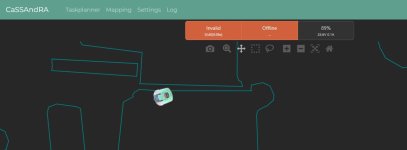
Möchtest du ein eigenes haben? Sonst hast du dort eine kleine Auswahlbtw: kann man in Cassandra native eigentlich das mower icon ändern?
Feb 28 15:19:18 mowerraspi python3[25678]: 2026-02-28 15:19:18 INFO RX: CON:AT+S
Feb 28 15:19:18 mowerraspi python3[25678]: 2026-02-28 15:19:18 INFO RX: S,25.03,-9.17,-0.81,-0.85,2,0,0,0.11,0,0.00,0.00,0.02,38,0.01,37,-223721,0.00,-1,0,0x73
Feb 28 15:19:20 mowerraspi python3[25678]: 2026-02-28 15:19:20 INFO RX: CON:AT+S
Feb 28 15:19:20 mowerraspi python3[25678]: 2026-02-28 15:19:20 INFO RX: S,25.03,-9.18,-0.80,-0.85,2,0,0,0.14,0,0.00,0.00,0.02,37,0.01,36,-223721,0.00,-1,0,0x74
Feb 28 15:19:21 mowerraspi python3[25678]: 2026-02-28 15:19:21 INFO RX: CON:AT+S2
Feb 28 15:19:21 mowerraspi python3[25678]: 2026-02-28 15:19:21 INFO RX: S2,0,0xe1
Feb 28 15:19:22 mowerraspi python3[25678]: 2026-02-28 15:19:22 INFO RX: CON:AT+S
Feb 28 15:19:22 mowerraspi python3[25678]: 2026-02-28 15:19:22 INFO RX: S,25.03,-9.18,-0.80,-0.85,2,0,0,0.33,0,0.00,0.00,0.02,37,0.01,36,-223721,0.00,-1,0,0x75
Feb 28 15:19:23 mowerraspi python3[25678]: 2026-02-28 15:19:23 INFO RX: 1:28:19 ctlDur=0.02 op=Idle(initiatedByOperator 0) freem=228131 sp=2000004C bat=25.03,-0.002(0.01) chg=0.05,0(0.00) diff=-24.972 tg=0.00,0.00 x=-9.18 y=-0.81 delta=-0.85 tow=569980600 lon=12.16856222 lat=50.64791871 h=371.4 n=-0.81 e=-9.18 d=2.75 sol=2 age=0.41
Feb 28 15:19:24 mowerraspi python3[25678]: 2026-02-28 15:19:24 INFO RX: CON:AT+S
Feb 28 15:19:24 mowerraspi python3[25678]: 2026-02-28 15:19:24 INFO RX: S,25.03,-9.17,-0.80,-0.85,2,0,0,0.36,0,0.00,0.00,0.02,37,0.01,36,-223721,0.00,-1,0,0x77
Feb 28 15:19:26 mowerraspi python3[25678]: 2026-02-28 15:19:26 INFO RX: CON:AT+S
Feb 28 15:19:27 mowerraspi python3[25678]: 2026-02-28 15:19:27 INFO RX: S,25.03,-9.18,-0.80,-0.85,2,0,0,0.46,0,0.00,0.00,0.02,37,0.01,36,-223721,0.00,-1,0,0x79
Feb 28 15:19:27 mowerraspi python3[25678]: 2026-02-28 15:19:27 INFO Backend: Create a shapely figure from data frame
Feb 28 15:19:27 mowerraspi python3[25678]: 2026-02-28 15:19:27 INFO Backend: Create a shapely figure from data frame
Feb 28 15:19:27 mowerraspi python3[25678]: 2026-02-28 15:19:27 INFO RX: Info - LoopTime: 3 - 2 - 3.03 - 17ms
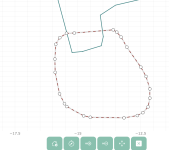
Feb 28 15:19:27 mowerraspi python3[25678]: 2026-02-28 15:19:27 WARNING Backend: Could not create new perimeter, new figure is: MultiPolygon
Feb 28 15:19:27 mowerraspi python3[25678]: 2026-02-28 15:19:27 INFO RX: 1:28:24 ctlDur=0.02 op=Idle(initiatedByOperator 0) freem=228131 sp=2000004C bat=25.03,-0.002(0.01) chg=0.05,0(0.00) diff=-24.973 tg=0.00,0.00 x=-9.18 y=-0.80 delta=-0.85 tow=569985600 lon=12.16856221 lat=50.64791873 h=371.4 n=-0.80 e=-9.18 d=2.75 sol=2 age=0.34
Feb 28 15:19:28 mowerraspi python3[25678]: 2026-02-28 15:19:28 INFO RX: CON:AT+S
Feb 28 15:19:29 mowerraspi python3[25678]: 2026-02-28 15:19:29 INFO RX: S,25.03,-9.18,-0.80,-0.85,2,0,0,0.55,0,0.00,0.00,0.02,37,0.01,35,-223721,0.00,-1,0,0x78
Feb 28 15:19:31 mowerraspi python3[25678]: 2026-02-28 15:19:31 INFO RX: CON:AT+S
Feb 28 15:19:31 mowerraspi python3[25678]: 2026-02-28 15:19:31 INFO RX: S,25.03,-9.17,-0.80,-0.85,2,0,0,0.63,0,0.00,0.00,0.02,37,0.01,35,-223721,0.00,-1,0,0x76
Feb 28 15:19:32 mowerraspi python3[25678]: 2026-02-28 15:19:32 INFO RX: CON:AT+S2
Feb 28 15:19:32 mowerraspi python3[25678]: 2026-02-28 15:19:32 INFO RX: S2,0,0xe1
Feb 28 15:19:32 mowerraspi python3[25678]: 2026-02-28 15:19:32 INFO RX: 1:28:29 ctlDur=0.02 op=Idle(initiatedByOperator 0) freem=228131 sp=2000004C bat=25.03,-0.002(0.01) chg=0.07,0(0.00) diff=-24.970 tg=0.00,0.00 x=-9.18 y=-0.81 delta=-0.85 tow=569990600 lon=12.16856222 lat=50.64791872 h=371.4 n=-0.81 e=-9.18 d=2.74 sol=2 age=0.38
Feb 28 15:19:33 mowerraspi python3[25678]: 2026-02-28 15:19:33 INFO RX: CON:AT+S
Feb 28 15:19:33 mowerraspi python3[25678]: 2026-02-28 15:19:33 INFO RX: S,25.03,-9.18,-0.81,-0.85,2,0,0,0.64,0,0.00,0.00,0.02,38,0.01,35,-223721,0.00,-1,0,0x7a
^CWARNING Backend: Could not create new perimeter, new figure is: MultiPolygon
{"robot":{"command": "resume"}}