Du verwendest einen veralteten Browser. Es ist möglich, dass diese oder andere Websites nicht korrekt angezeigt werden.
Du solltest ein Upgrade durchführen oder einen alternativen Browser verwenden.
Du solltest ein Upgrade durchführen oder einen alternativen Browser verwenden.
Ardumower zum laufen bringen Teil 1
- Ersteller MarioFFK
- Erstellt am


Ich finde es toll das Du nicht aufgegeben hastFehler gefunden
ich überlege gerade wie ich meine Dummheit beschreiben soll


MarioFFK
Member
Ich sag es mal frei raus
ich habe ständig diese Seite hier "http://grauonline.de/alexwww/ardumower/ardumower-sunray-app/index.html"
mit https geöffnet.
Und mir ist gerade aufgefallen das ich gar nicht schuld bin (eigentlich sind es ja immer die anderen)
Der beschi... Chrombrowser macht mir aus allem egal ob ich die Seite händisch eintrage (kenne ich auswendig) aus einem http:// ein https://
ist mir nie aufgefallen da ich ja immer nur http eingegeben habe.
Nun schau ich mal ob ich mich wieder mit Chrome vertragen kann.
Danke das ihr alle so schön mitgemacht und mir geholfen habt es waren ja auch noch andere Fehler bei mir drin.
ich habe ständig diese Seite hier "http://grauonline.de/alexwww/ardumower/ardumower-sunray-app/index.html"
mit https geöffnet.
Und mir ist gerade aufgefallen das ich gar nicht schuld bin (eigentlich sind es ja immer die anderen
)Der beschi... Chrombrowser macht mir aus allem egal ob ich die Seite händisch eintrage (kenne ich auswendig) aus einem http:// ein https://
ist mir nie aufgefallen da ich ja immer nur http eingegeben habe.
Nun schau ich mal ob ich mich wieder mit Chrome vertragen kann.
Danke das ihr alle so schön mitgemacht und mir geholfen habt es waren ja auch noch andere Fehler bei mir drin.
Ja , der liebe Chrome-Browser, der macht sowas!
Deshalb hatte ich dich ja auch einmal gefragt, ob du schon mal einen anderen Browser probiert hast.
Nun kannst du ja mal noch versuchen, ob du auf deinem Raspberry Cassandra installieren kannst, das ist für meine Begriffe die bessere Lösung.
Deshalb hatte ich dich ja auch einmal gefragt, ob du schon mal einen anderen Browser probiert hast.
Hast du die Evothings-Viewer-App oder schon einmal einen anderen Browser probiert?
Nun gut, wenn es jetzt funktioniert ist ja alles OK.Ist das vielleicht ein Firewall-Problem oder dass der Browser nur https zulässt?
Nun kannst du ja mal noch versuchen, ob du auf deinem Raspberry Cassandra installieren kannst, das ist für meine Begriffe die bessere Lösung.
MarioFFK
Member
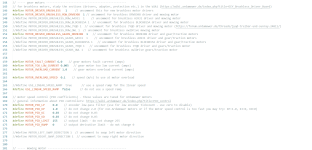
Ich bin ja noch guter Hoffnung, dass ich hier noch ein Hinweis bekomme. Ist wahrscheinlich wegen der ganzen esp32 Geschichte untergegangenDiese Einstellung habe ich für meine Motoren mit Treiber genommen ( siehe Bild)
Vielleicht könnte einer mal drüber schauen.
Anhang anzeigen 7781
MarioFFK
Member
So läuft.Ja , der liebe Chrome-Browser, der macht sowas!
Deshalb hatte ich dich ja auch einmal gefragt, ob du schon mal einen anderen Browser probiert hast.
Nun gut, wenn es jetzt funktioniert ist ja alles OK.
Nun kannst du ja mal noch versuchen, ob du auf deinem Raspberry Cassandra installieren kannst, das ist für meine Begriffe die bessere Lösung.
Nun die Motoren.
MarioFFK
Member
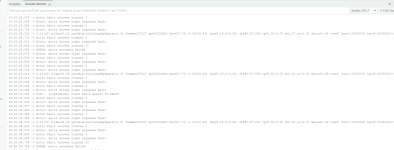
So Startet mein M4 Board
16:23:33.902 -> SD card found!
16:23:33.902 -> RESET cause: power-on
16:23:33.902 -> Sunray,1.0.324
16:23:33.902 -> compiled for: Adafruit Grand Central M4
16:23:33.902 -> using robot driver: AmRobotDriver
16:23:33.902 -> robot id: 5b:cd:5a:24:53:38:57:57:51:20:20:20:ff:08:1d:26
16:23:33.902 -> MOTOR_DRIVER_BRUSHLESS: yes
16:23:33.902 -> enableCharging 0
16:23:33.902 -> probing for HM-10 module (NOTE: will fail for ESP32)...
16:23:33.902 -> trying to detect Bluetooth 4.0/BLE (HM-10 module) (make sure your phone is NOT connected)9600...
16:23:34.413 -> BLE: AT
16:23:36.368 -> trying to detect Bluetooth 4.0/BLE (HM-10 module) (make sure your phone is NOT connected)115200...
16:23:36.906 -> BLE: AT
16:23:36.906 -> OK
16:23:37.093 -> Bluetooth 4.0/BLE (HM-10) module found!
16:23:37.602 -> BLE: AT+VERSION
16:23:37.602 -> +VERSION=ESP32 firmware V0.4.5,Bluetooth V4.0 LE
16:23:38.302 -> BLE: AT+NAMEArdumower
16:23:38.302 -> +NAME=Ardumower
16:23:38.984 -> BLE: AT+RESET
16:23:38.984 -> +RESET
16:23:39.215 -> RCModel disabled in config
16:23:39.215 -> using bumper driver: LiDAR
16:23:39.215 -> ENABLE_PASS
16:23:39.215 -> ENABLE_TILT_DETECTION
16:23:39.215 -> FREEWHEEL_IS_AT_BACKSIDE: 1
16:23:39.215 -> WHEEL_BASE_CM: 36
16:23:39.215 -> WHEEL_DIAMETER: 250
16:23:39.215 -> ENABLE_ODOMETRY_ERROR_DETECTION: 0
16:23:39.215 -> TICKS_PER_REVOLUTION: 650
16:23:39.215 -> MOTOR_DRIVER_BRUSHLESS
16:23:39.215 -> MOTOR_DRIVER_BRUSHLESS_MOW_DRV8308
16:23:39.215 -> MOTOR_DRIVER_BRUSHLESS_GEARS_DRV8308
16:23:39.215 -> MOTOR_FAULT_CURRENT: 6.00
16:23:39.215 -> MOTOR_OVERLOAD_CURRENT: 1.00
16:23:39.215 -> USE_LINEAR_SPEED_RAMP: 0
16:23:39.215 -> MOTOR_PID_KP: 2.00
16:23:39.215 -> MOTOR_PID_KI: 0.03
16:23:39.215 -> MOTOR_PID_KD: 0.03
16:23:39.215 -> MOW_FAULT_CURRENT: 8.00
16:23:39.215 -> MOW_OVERLOAD_CURRENT: 2.00
16:23:39.215 -> ENABLE_OVERLOAD_DETECTION: 1
16:23:39.215 -> ENABLE_FAULT_DETECTION: 1
16:23:39.215 -> ENABLE_FAULT_OBSTACLE_AVOIDANCE: 1
16:23:39.215 -> ENABLE_RPM_FAULT_DETECTION: 1
16:23:39.215 -> SONAR_INSTALLED
16:23:39.215 -> SONAR_ENABLE: 1
16:23:39.215 -> SONAR_TRIGGER_OBSTACLES: 1
16:23:39.215 -> RAIN_ENABLE: 0
16:23:39.215 -> BUMPER_ENABLE: 1
16:23:39.215 -> BUMPER_DEADTIME: 1000
16:23:39.215 -> BUMPER_TRIGGER_DELAY: 0
16:23:39.215 -> BUMPER_MAX_TRIGGER_TIME: 30
16:23:39.215 -> LIDAR_BUMPER_ENABLE: 0
16:23:39.215 -> CURRENT_FACTOR: 1.98
16:23:39.215 -> GO_HOME_VOLTAGE: 21.50
16:23:39.215 -> BAT_FULL_VOLTAGE: 28.70
16:23:39.215 -> BAT_FULL_CURRENT: 0.20
16:23:39.215 -> BAT_SWITCH_OFF_IDLE: 0
16:23:39.215 -> BAT_SWITCH_OFF_UNDERVOLTAGE: 1
16:23:39.215 -> GPS_USE_SKYTRAQ
16:23:39.215 -> REQUIRE_VALID_GPS: 1
16:23:39.215 -> GPS_SPEED_DETECTION: 1
16:23:39.215 -> GPS_MOTION_DETECTION: 1
16:23:39.215 -> GPS_REBOOT_RECOVERY: 1
16:23:39.215 -> GPS_CONFIG: 1
16:23:39.215 -> GPS_CONFIG_FILTER: 1
16:23:39.215 -> CPG_CONFIG_FILTER_MINELEV: 10
16:23:39.215 -> CPG_CONFIG_FILTER_NCNOTHRS: 10
16:23:39.215 -> CPG_CONFIG_FILTER_CNOTHRS: 30
16:23:39.215 -> ALLOW_ROUTE_OUTSIDE_PERI_METER: 1.00
16:23:39.215 -> OBSTACLE_DETECTION_ROTATION: 0
16:23:39.215 -> KIDNAP_DETECT: 1
16:23:39.215 -> KIDNAP_DETECT_ALLOWED_PATH_TOLERANCE: 1.00
16:23:39.215 -> DOCKING_STATION: 0
16:23:39.215 -> DOCK_IGNORE_GPS: 0
16:23:39.215 -> DOCK_AUTO_START: 1
16:23:39.215 -> TARGET_REACHED_TOLERANCE: 0.10
16:23:39.215 -> STANLEY_CONTROL_P_NORMAL: 3.00
16:23:39.215 -> STANLEY_CONTROL_K_NORMAL: 1.00
16:23:39.215 -> STANLEY_CONTROL_P_SLOW: 3.00
16:23:39.215 -> STANLEY_CONTROL_K_SLOW: 0.10
16:23:39.215 -> BUTTON_CONTROL: 1
16:23:39.215 -> USE_TEMP_SENSOR: 0
16:23:39.215 -> BUZZER_ENABLE
16:23:39.215 -> SERIAL_BUFFER_SIZE=1024 (increase if you experience GPS checksum errors)
16:23:39.215 -> -----------------------------------------------------
16:23:39.215 -> SKYTRAQ::begin serial
16:23:39.215 -> using gps driver: SKYTRAQ
16:23:39.215 -> using skytraq gps...
16:23:39.215 -> Map::begin
16:23:39.215 -> sizeof Point=4
16:23:39.215 -> map load... no map file!
16:23:39.215 -> map dump - mapCRC=0
16:23:39.215 -> points:
16:23:39.215 -> perimeter pts: 0
16:23:39.215 -> exclusion pts: 0
16:23:39.215 -> exclusions: 0
16:23:39.215 -> dock pts: 0
16:23:39.215 -> mow pts: 0
16:23:39.215 -> free pts: 0
16:23:39.215 -> mowPointsIdx=0 dockPointsIdx=0 freePointsIdx=0 wayMode=3
16:23:39.215 -> probing for ESP8266 (NOTE: will fail for ESP32)...
16:23:39.727 -> WIFI (ESP8266) not found! If you have ESP8266 and the problem persist, you may need to flash your ESP to firmware 2.2.168
16:23:39.727 -> MPU6050/9150 found
16:23:39.727 -> using imu driver: MpuDriver
16:23:41.030 -> resuming is activated
16:23:41.030 -> state load... ok
16:23:41.075 -> dumpState: X=0.00 Y=0.00 delta=0.18 mapCRC=0 mowPointsIdx=0 dockPointsIdx=0 freePointsIdx=0 wayMode=4 op=0 sensor=9 sonar.enabled=1 fixTimeout=100 absolutePosSource=0 lon=0.00 lat=0.00 pwmMaxMow=255 finishAndRestart=0 motorMowForwardSet=1
16:23:41.075 -> timetable (UTC times) 00 01 02 03 04 05 06 07 08 09 10 11 12 13 14 15 16 17 18 19 20 21 22 23
16:23:41.075 -> timetable (UTC times) mon * * * * * * * * * * *
16:23:41.075 -> timetable (UTC times) tue * * * * * * * * * * *
16:23:41.075 -> timetable (UTC times) wed * * * * * * * * * * *
16:23:41.075 -> timetable (UTC times) thu * * * * * * * * * * *
16:23:41.075 -> timetable (UTC times) fri * * * * * * * * * * *
16:23:41.075 -> timetable (UTC times) sat * * * * * * * * * * *
16:23:41.075 -> timetable (UTC times) sun * * * * * * * * * * *
16:23:41.075 -> * means mowing allowed
16:23:41.075 -> current GPS UTC weektime: dayOfWeek=mon hour=0
16:23:41.075 -> timetable enabled: 0
16:23:41.075 -> mowing allowed: 1
16:23:41.075 -> Error: motor driver right signaled fault
16:23:41.158 -> batTemp=998 cpuTemp=33
16:23:41.158 -> GPS time (UTC): dayOfWeek=sun hour=0
16:23:41.158 -> AUTOSTOP: timetable is disabled
16:23:41.158 -> AUTOSTART: not defined DOCKING_STATION
16:23:41.158 -> ==> changeOp:ImuCalibration(initiatedByOperator 0)->Idle
16:23:41.158 -> IMU gyro calibration (robot must be static)... 1
16:23:41.158 -> sending encryptMode=1 encryptChallenge=155
16:23:41.158 -> 0:0:9 ctlDur=0.00 op=ImuCalibration(initiatedByOperator 0)->Idle freem=237587 sp=20000084 bat=0.00,0.000(0.00) chg=0.00,0(0.00) diff=0.000 tg=0.00,0.00 x=0.00 y=0.00 delta=0.18 tow=0 lon=0.00000000 lat=0.00000000 h=0.0 n=0.00 e=0.00 d=0.00 sol=0 age=9.15
16:23:42.018 -> WARNING - LoopTime: 3 min=2 mean=7.41 max=9146
16:23:42.098 -> motor fault recover counter 1
16:23:42.183 -> Error: motor driver left signaled fault
16:23:42.183 -> Error: motor driver right signaled fault
16:23:42.183 -> IMU gyro calibration (robot must be static)... 2
16:23:43.066 -> charger conn=0 chgEnabled=0 chgTime=0 charger: 0.02 V 0.00 A bat: 27.71 V diffV=-0.28 slope(v/min)=0.00 slopeLowCounter=1
16:23:43.205 -> IMU gyro calibration (robot must be static)... 3
16:23:43.205 -> motor fault recover counter 2
16:23:43.250 -> Error: motor driver right signaled fault
16:23:44.188 -> IMU gyro calibration (robot must be static)... 4
16:23:44.268 -> motor fault recover counter 3
16:23:44.355 -> Error: motor driver right signaled fault
16:23:45.197 -> IMU gyro calibration (robot must be static)... 5
16:23:45.380 -> motor fault recover counter 4
16:23:45.427 -> Error: motor driver right signaled fault
16:23:46.190 -> 0:0:14 ctlDur=0.02 op=ImuCalibration(initiatedByOperator 0)->Idle freem=237483 sp=20000084 bat=27.72,0.000(0.18) chg=0.16,0(0.01) diff=-12.487 tg=0.00,0.00 x=0.00 y=0.00 delta=0.18 tow=0 lon=0.00000000 lat=0.00000000 h=0.0 n=0.00 e=0.00 d=0.00 sol=0 age=14.15
16:23:46.236 -> IMU gyro calibration (robot must be static)... 6
16:23:46.468 -> motor fault recover counter 5
16:23:46.515 -> Error: motor driver right signaled fault
16:23:47.260 -> IMU gyro calibration (robot must be static)... 7
16:23:47.568 -> motor fault recover counter 6
16:23:47.614 -> Error: motor driver right signaled fault
16:23:48.267 -> IMU gyro calibration (robot must be static)... 8
16:23:48.637 -> motor fault recover counter 7
16:23:48.684 -> Error: motor driver right signaled fault
16:23:49.240 -> IMU gyro calibration (robot must be static)... 9
16:23:49.724 -> motor fault recover counter 8
16:23:49.755 -> Error: motor driver right signaled fault
16:23:50.250 -> IMU gyro calibration (robot must be static)... 10
16:23:50.828 -> motor fault recover counter 9
16:23:50.875 -> Error: motor driver right signaled fault
16:23:51.142 -> 0:0:19 ctlDur=0.02 op=ImuCalibration(initiatedByOperator 0)->Idle freem=237483 sp=20000084 bat=27.74,0.000(0.28) chg=0.16,0(0.01) diff=-21.883 tg=0.00,0.00 x=0.00 y=0.00 delta=0.18 tow=0 lon=0.00000000 lat=0.00000000 h=0.0 n=0.00 e=0.00 d=0.00 sol=0 age=19.15
16:23:51.279 -> IMU gyro calibration (robot must be static)... 11
16:23:51.876 -> motor fault recover counter 10
16:23:51.876 -> ERROR: motor recovery failed
16:23:51.944 -> Error: motor driver right signaled fault
16:23:52.038 -> Info - LoopTime(ms) now=3 min=2 mean=2.88 max=8
16:23:52.316 -> IMU gyro calibration (robot must be static)... 12
16:23:53.010 -> motor fault recover counter 1
16:23:53.056 -> Error: motor driver right signaled fault
16:23:53.282 -> IMU gyro calibration (robot must be static)... 13
16:23:54.052 -> motor fault recover counter 2
16:23:54.139 -> Error: motor driver right signaled fault
16:23:54.325 -> IMU gyro calibration (robot must be static)... 14
16:23:55.181 -> motor fault recover counter 3
16:23:55.213 -> Error: motor driver right signaled fault
16:23:55.302 -> IMU gyro calibration (robot must be static)... 15
MarioFFK
Member
Ich habe keine Ahnung was man hier nehmen muss Ich weiß nur eines das Ich BL Motoren haben aber mir sagen die ganzen Bezeichnungen im Code nix.
Ich lese da nur als Kommentar welche Farbe die Kappe hat und das altere einen weißen Stecker haben ich habe ein weißen Stecker weiß aber das ich mit Sicherheit keine alten Motoren habe.
Ich weiß echt nicht wie ich hier zu potte kommen soll.
Ich lese da nur als Kommentar welche Farbe die Kappe hat und das altere einen weißen Stecker haben ich habe ein weißen Stecker weiß aber das ich mit Sicherheit keine alten Motoren habe.
Ich weiß echt nicht wie ich hier zu potte kommen soll.
Ja, du hast BL-Motoren, soviel ist mir auch klar. Das Problem sind vermutlich die Treiber, die auf deinen Bildern auf den Motoren sitzen. Die müssen passen, sonst wird das nichts. Die alten Bürstenmotoren, die in der config mit verschiedenen Kappen und Steckern aufgelistet sind, sind uninteressant für dich, kannst du alle auskommentiert lassen. Du musst nur die richtigen BL-Treiber aktivieren. Welche du da hast, weiß ich nicht. Hast du irgendwelche Angaben dazu auf der Rechnung?