Du verwendest einen veralteten Browser. Es ist möglich, dass diese oder andere Websites nicht korrekt angezeigt werden.
Du solltest ein Upgrade durchführen oder einen alternativen Browser verwenden.
Du solltest ein Upgrade durchführen oder einen alternativen Browser verwenden.
Arctic Hare mod by Jussi
- Ersteller jussip
- Erstellt am
For RFID.
Like i tell you before : avoid 125Khz readers (issue with perimeter).
Actualy i work on:
This one : very easy to interface with the PI (it's keyboard simulator) and work on USB with the raspberry,
(but the reading distance is only 3 or 4 cm with my tag), so you need to put the antena very near the ground.
So if you want to do fast test it's OK.
search on eBay : "13.56MHZ RFID USB Sans Contact Lecteur Carte à Puce IC Lecteur de cartes Noir"


And this one:
on Ebay "PN5180 NFC RF I Sensor ISO15693 RFID High Frequency IC card ICODE2 Read&Write"
Here the reading distance is very good with the ISO15693 card (near 15 20 cm) ,i have no tag and hope it's exist to test.
Unfortunatly the library use SPI interface and it's very complex with the PCB1.3 But i prefer to work on it and maybe with ESP32 between the reader and the PCB1.3, but for the moment it's work only with the UNO.
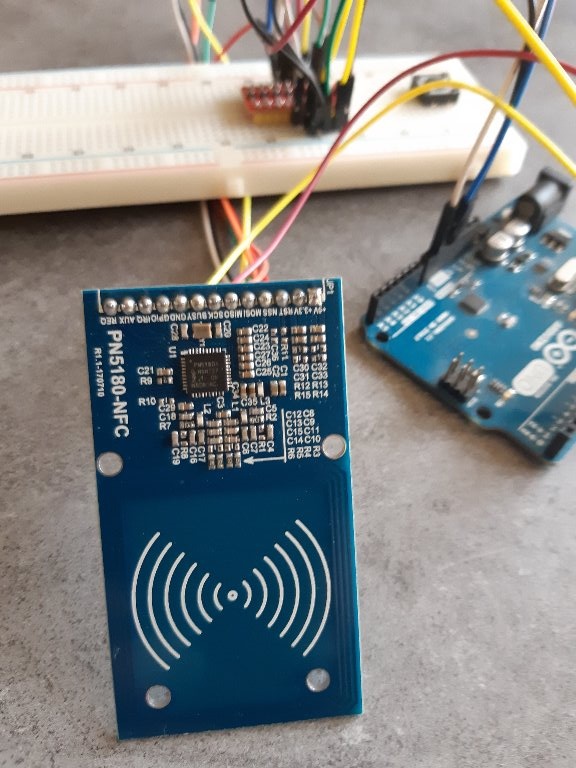
Attachment: https://forum.ardumower.de/data/media/kunena/attachments/3545/20190523_190430.jpg/
Like i tell you before : avoid 125Khz readers (issue with perimeter).
Actualy i work on:
This one : very easy to interface with the PI (it's keyboard simulator) and work on USB with the raspberry,
(but the reading distance is only 3 or 4 cm with my tag), so you need to put the antena very near the ground.
So if you want to do fast test it's OK.
search on eBay : "13.56MHZ RFID USB Sans Contact Lecteur Carte à Puce IC Lecteur de cartes Noir"
And this one:
on Ebay "PN5180 NFC RF I Sensor ISO15693 RFID High Frequency IC card ICODE2 Read&Write"
Here the reading distance is very good with the ISO15693 card (near 15 20 cm) ,i have no tag and hope it's exist to test.
Unfortunatly the library use SPI interface and it's very complex with the PCB1.3 But i prefer to work on it and maybe with ESP32 between the reader and the PCB1.3, but for the moment it's work only with the UNO.
Attachment: https://forum.ardumower.de/data/media/kunena/attachments/3545/20190523_190430.jpg/

Zuletzt bearbeitet von einem Moderator:
No ,to 3.3V (Vin).
The GY88 factory use the same i2c adress as the RTC so you need to shunt AD0 to have a new free adress for PCB1.3
So:
Vin to 3.3V
G_AD0 to Vin
SLC to SCL
SDA to SDA
GND to GND
other pin are not used
JC2 to 3.3V
Here the picture:
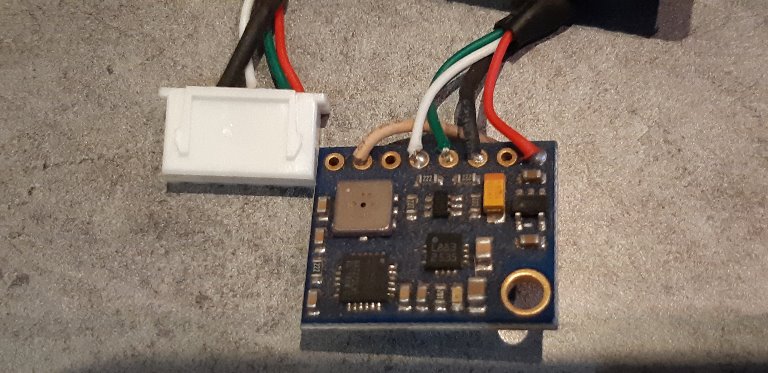
Attachment: https://forum.ardumower.de/data/media/kunena/attachments/3545/20190525_213333.jpg/
The GY88 factory use the same i2c adress as the RTC so you need to shunt AD0 to have a new free adress for PCB1.3
So:
Vin to 3.3V
G_AD0 to Vin
SLC to SCL
SDA to SDA
GND to GND
other pin are not used
JC2 to 3.3V
Here the picture:
Attachment: https://forum.ardumower.de/data/media/kunena/attachments/3545/20190525_213333.jpg/

Zuletzt bearbeitet von einem Moderator:
If the hardware is ok,use the Pi console and pfop to activate and calibrate the IMU.
If you have trouble maybe you need to view the startup message,Unfortunatly it's not possible on the PI because the DUE start faster than Raspberry.
To Do, you need to deactivate the Pi into Pfod setting R/C etc...
Change in mower.h
to have the Data on the serial and not serialUsb.
Now you can use the arduino IDE console to check the startup and follow the calibration process.
To do only one time or after changing position of the IMU in the mower.
Accel/Gyro calibration
Into Pfop Setting / IMU / Accel Gyro Initial Calibration more than 30sec duration
Click and do not move the mower you need to see wait.. , wait.. etc ...... on the console .
When it's finish the Tilt and roll need to be near 0 and move when the mower is inclinate.
Compass calibration (THE IMU need to be as far as possible from magnet or metal parts)
Into Pfop Setting / IMU / Accel Gyro Initial Calibration more than 30sec duration
click and move the mower in all possible position until no new data are coming in the console.
click again to stop the calibration.
Finaly you need into IMU setting have a good result when roll the mower on GYRO yaw
Check this old post (maybe the soft is new but the concept on bylane and compass is the same).
https://www.ardumower.de/index.php/de/forum/software-control/1349-azurit-full-odometry-mouvement-control?start=20#13951
If you have trouble maybe you need to view the startup message,Unfortunatly it's not possible on the PI because the DUE start faster than Raspberry.
To Do, you need to deactivate the Pi into Pfod setting R/C etc...
Change in mower.h
Code:
#define Console Serial
#define CONSOLE_BAUDRATE    115200       // baudrate used for PC

//#define Console SerialUSB
//#define CONSOLE_BAUDRATE    250000       // baudrate used for Raspberry PI console
to have the Data on the serial and not serialUsb.
Now you can use the arduino IDE console to check the startup and follow the calibration process.
To do only one time or after changing position of the IMU in the mower.
Accel/Gyro calibration
Into Pfop Setting / IMU / Accel Gyro Initial Calibration more than 30sec duration
Click and do not move the mower you need to see wait.. , wait.. etc ...... on the console .
When it's finish the Tilt and roll need to be near 0 and move when the mower is inclinate.
Compass calibration (THE IMU need to be as far as possible from magnet or metal parts)
Into Pfop Setting / IMU / Accel Gyro Initial Calibration more than 30sec duration
click and move the mower in all possible position until no new data are coming in the console.
click again to stop the calibration.
Finaly you need into IMU setting have a good result when roll the mower on GYRO yaw
Check this old post (maybe the soft is new but the concept on bylane and compass is the same).
https://www.ardumower.de/index.php/de/forum/software-control/1349-azurit-full-odometry-mouvement-control?start=20#13951
???????:dry:your pictures wires are Vin which is meant for 5v
It's 3.3V ,red wire on the Bottom of connector.
NO for Accel Gyrocalibration steps what are in wiki are not needed? All sides up etc.
First part of the WIKI is Gyro Accel calibration of GY801 and it's not the same for GY88 (simply Don't move the Mower until setup is finish)
The Compass is same as the Wiki.
3.3v wire should be in board 3v3 not Vin. It's all here http://www.haoyuelectronics.com/Attachment/GY-88/GY-88.SCH.jpg (except how to wire G_AD0  )
)The gyro use the compass to do that on startup ,after lane nr change,and after each delay you set in setting Imu
Normaly on startup, if you dont move the mower value are the same.
Go to Pfod setting IMU the compass and Gyro need to be equal.
When roll manualy the mower the Gyro need to be accurate but not the compass.
Normaly on startup, if you dont move the mower value are the same.
Go to Pfod setting IMU the compass and Gyro need to be equal.
When roll manualy the mower the Gyro need to be accurate but not the compass.
Hi.
Remember magnetic or metalic part near the compass and the value change.
For example North and South are not opposite !!!!!
It's exactly the issue The compass is not OK Inside the mower.And it's why i Don't use it in the drive heading
If you have a smartphone with compass you can test it and see the same result each time you approch the phone and mower.
btw if the IMU work,the mower need to drive in perfect line and when you roll it manualy while driving it need to find again automaticly the heading.
Also what is the result of the Test Imu ?
How is locate the IMU Inside the mower (magnet, metal ??)
try again only the compass calibration.
Roll the mower upsidedown etc....in all position you can, until no new data coming in console and click again to stop calibration.check in the console that the data are saved.
Reboot all
And test the bylane mowing or slope mowing(if you have)
try again only the compass calibration.
Roll the mower upsidedown etc....in all position you can, until no new data coming in console and click again to stop calibration.check in the console that the data are saved.
Reboot all
And test the bylane mowing or slope mowing(if you have)