Du verwendest einen veralteten Browser. Es ist möglich, dass diese oder andere Websites nicht korrekt angezeigt werden.
Du solltest ein Upgrade durchführen oder einen alternativen Browser verwenden.
Du solltest ein Upgrade durchführen oder einen alternativen Browser verwenden.
Akku wird nicht voll geladen
- Ersteller jaschek
- Erstellt am

Bei meinem Ardumower war es das (blaue) Laderelais auf dem Ardumower-PCB (K3 im Schaltbild unten) welches nicht mehr richtig durchschalten wollte (es zog noch hörbar an aber lies nach einer Weile von selber los). Nach dem Wechsel wurde dann wieder richtig vollgeladen...
Deine Fehlerbeschreibung ist leicht anders, trotzdem kannst Du ja mal Ladespannung an den verschiedenen Stellen messen etc. wie hier beschrieben:
 wiki.ardumower.de
Deine Fehlerbeschreibung ist leicht anders, trotzdem kannst Du ja mal Ladespannung an den verschiedenen Stellen messen etc. wie hier beschrieben:
How to find defective components – www.wiki.ardumower.de
Zuletzt bearbeitet:

Silberstreifen
Active member
ich hatte das Problem auch. Bei mir haben 2 kleine Änderungen in der battery.cpp geholfen:
Zeile 190:
Zeile 190:
ersetzen durchfloat w = 0.999;
und in Zeile 261float w = 0.975;
ersetzen durchchargingCompleted = true;
Die erste Änderung sorgt dafür, dass Spannungsänderungen schneller zum Tragen kommen. Die 2. Änderung setzt den Counter zurück, der verhindert, dass der Ladevorgang wieder startet.batteryVoltageSlopeLowCounter = 0;
hoglibogli
Member
Ich hatte diese Änderungen bei mir eingebaut, jetzt lädt er voll. Leider zeigt er jetzt fälschlicherweise auch Charge an, wenn er im Idle ist. Ich hab noch nicht ganz verstanden wofür float w hier zuständig ist. Kann mich da jemand aufklären?ich hatte das Problem auch. Bei mir haben 2 kleine Änderungen in der battery.cpp geholfen:
Zeile 190:
ersetzen durch
und in Zeile 261
ersetzen durch
Die erste Änderung sorgt dafür, dass Spannungsänderungen schneller zum Tragen kommen. Die 2. Änderung setzt den Counter zurück, der verhindert, dass der Ladevorgang wieder startet.
Silberstreifen
Active member
Der w-Wert definiert die Mittelungsdauer. Je näher der Wert an 1 ist, desto größer die Dauer, die gemittelt wird.Ich hab noch nicht ganz verstanden wofür float w hier zuständig ist. Kann mich da jemand aufklären?
Verstehe ich nicht. Ladegerät ist nicht angeschlossen?Leider zeigt er jetzt fälschlicherweise auch Charge an, wenn er im Idle ist.
hoglibogli
Member
Das Ladegerät ist nicht angeschlossen.
Da hab ich meine Frage unklar formuliert, ich bin mir nicht ganz sicher wofür BatterySlope benötigt wird und in welcher Form das den Start bzw. die Beendigung des Ladevorgangs beeinflusst. Ich hab versucht das in der batteryc.cpp nachzuvollziehen, aber so richtig durchgedrungen bin ich leider noch nicht.Der w-Wert definiert die Mittelungsdauer. Je näher der Wert an 1 ist, desto größer die Dauer, die gemittelt wird.
Silberstreifen
Active member
Wenn der batteryVoltageSlopeLowCounter größer 5 ist, wird der Ladevorgang beendet. Der Counter zählt hoch, wenn die Änderung der Batteriespannung beim Laden kleiner als 0.002 ist. Die Änderung der Ladespannung wird durch den w-Wert stark geglättet, wodurch die Änderung der Ladespannung stark verzögert ankommt und damit -wenigstens bei mir- der Ladevorgang abgebrochen wurde, bevor er eigentlich gestartet hat. Durch die Reduzierung des w-Werts passiert das nicht mehr.
Das ist ja merkwürdig. Das kenne ich bei mir nicht.Das Ladegerät ist nicht angeschlossen.
hoglibogli
Member
Könnte es sein, das Batteryslope auch Entladung als Charging registrieren könnte? Im Code wird ja der ABS Wert genommen:
Da bei mir ja insgesamt 7 Regler verbaut sind, die im Leerlauf auch Strom verbrauchen, sinkt die Batterie Spannung langsam ab im Idle. Die Regler laufen nicht übers PCB bei mir, bedeutet es wird nur der Ladestrom erfasst, aber nicht die "Betriebs Ströme".
Code:
if (abs(batteryVoltageSlope) < 0.002){
batteryVoltageSlopeLowCounter = min(10, batteryVoltageSlopeLowCounter + 1);Silberstreifen
Active member
Nein, der Algorithmus dient zum Stoppen des Ladevorgangs, nicht zum Starten.
hoglibogli
Member
Seltsam, muss ich mich mal weiter durch den Code wühlen um das zu verstehen.
Ich habe ein seltsames Phänomen - nachdem am Anfang in der Dockingstation der Ladevorgang bei ca. 26,5V abgebrochen wurde, aber direkt am Kabel normal bis 100% aufgeladen wurde (nach dem Biegen an der Dockingstation hat es dann da auch wieder bis 100% funktioniert), habe ich plötzlich wieder nur so Ladevorgänge bis 26,5V. Und dies sowohl in der Docking Station als auch am Kabel.ich hatte das Problem auch. Bei mir haben 2 kleine Änderungen in der battery.cpp geholfen:
Zeile 190:
ersetzen durch
und in Zeile 261
ersetzen durch
Die erste Änderung sorgt dafür, dass Spannungsänderungen schneller zum Tragen kommen. Die 2. Änderung setzt den Counter zurück, der verhindert, dass der Ladevorgang wieder startet.
Ich habe gerade Deine vorgeschlagenen Änderungen durchgeführt - leider macht das auch keinen Unterschied. Noch eine Idee hierzu?
Silberstreifen
Active member
hmmm, bei mir sieht das dann so aus

Wenn er bei 26.5V abbricht, liegt das entweder an einem zu geringen Strom/Spannungsänderung oder einer defekten Verbindung (Relais/Kontakte). Um wieviel ist denn die Ladespannung höher als die Batteriespannung?
Wenn er bei 26.5V abbricht, liegt das entweder an einem zu geringen Strom/Spannungsänderung oder einer defekten Verbindung (Relais/Kontakte). Um wieviel ist denn die Ladespannung höher als die Batteriespannung?
Irgendwie seltsam, der 1. Ladevorgang hat auch nach mehrmaligem Neustart bei 26,5V aufgehört zu laden. Dann habe ich genäht und aktuell lädt er immer noch und ist schon bei 27V und er lädt noch.
Die Ladespannung lag bei 28,5V als er heute mittag nicht mehr weitergeladen hat. Das Relais schaltet zuverlässig, das Ladegerät hat die LED rot.
Die Ladespannung lag bei 28,5V als er heute mittag nicht mehr weitergeladen hat. Das Relais schaltet zuverlässig, das Ladegerät hat die LED rot.

EinEinfach
Well-known member
@Silberstreifen habe gestern auf 322 auf meinem Selbstbau upgedatet. Lief alles gut, bis der Mäher zum Laden angedockt hat, nach einiger Zeit bemerkte ich, dass die Akkuspannung bei etwa über 26V hing (Normalerweise habe ich über 28V als 100% eingestellt). Mit Deinen Änderungen in der FW funktioniert es wieder wie gewohnt.
Danke
Danke

Wolfgang Dümchen
Member
Die Änderung bringt Besserung. Danke.ich hatte das Problem auch. Bei mir haben 2 kleine Änderungen in der battery.cpp geholfen:
Zeile 190:
ersetzen durch
und in Zeile 261
ersetzen durch
Die erste Änderung sorgt dafür, dass Spannungsänderungen schneller zum Tragen kommen. Die 2. Änderung setzt den Counter zurück, der verhindert, dass der Ladevorgang wieder startet.
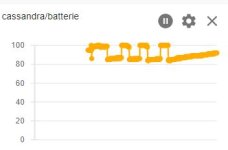
Der komplette Ladevorgang läuft nun durch (z.B. von 30% bis 100%) Dann aber "Erhaltungsladezyklus" ab 85 % siehe Bild. Erst wie "alt" in kurzen Zyklen, Dann wohl wieder lang bis 100%. Da wäre mir statt 85% 90 oder höher lieber. Gewollt?
Silberstreifen
Active member
hmm, sieht deutlich anders aus, als bei mir und kann ich durch den Code und die verbaute Technik auch nicht nachvollziehen. Die Ladesteuerung schaltet das Ladegerät nur an und aus. Langsam und schnell laden kann die Technik nicht umsetzen. Ich hänge hier mal meine komplette battery.h
...und battery.cpp an.// Ardumower Sunray
// Copyright (c) 2013-2020 by Alexander Grau, Grau GmbH
// Licensed GPLv3 for open source use
// or Grau GmbH Commercial License for commercial use (http://grauonline.de/cms2/?page_id=153)
// Ardumower battery management
#ifndef BATTERY_H
#define BATTERY_H
class Battery {
public:
bool docked; // robot in docking?
bool batMonitor;
float batGoHomeIfBelow;
float batFullVoltage;
float batSwitchOffIfBelow; // switch off battery if below voltage (Volt)
int batSwitchOffIfIdle; // switch off battery if idle (minutes)
int enableChargingTimeout;
float batFullCurrent;
float batteryVoltage; // volts
float batteryVoltageLast;
float chargingVoltBatteryVoltDiff;
float batteryVoltageSlope; // slope (volts/minute)
float chargingVoltage; // volts
float chargingCurrent; // amps
float startChargingIfBelow;
bool chargingEnabled;
int chargingEnabledDelay;
int chargingCompletedDelay; // ensure that loadingcurrent or loadingvoltage triggers 'chargingCompleted' condition for a longer period
bool chargingCompleted;
void begin();
void run();
void setIsDocked(bool state);
bool isDocked();
bool chargerConnected();
bool badChargerContact();
void enableCharging(bool flag);
bool shouldGoHome();
bool chargingHasCompleted();
bool underVoltage();
void resetIdle();
void switchOff();
protected:
int batteryVoltageSlopeLowCounter;
int startupPhase;
unsigned long nextBatteryTime ;
bool switchOffByOperator;
unsigned long timeMinutes;
bool chargerConnectedState;
bool badChargerContactState;
bool switchOffAllowedUndervoltage;
bool switchOffAllowedIdle;
unsigned long switchOffTime;
unsigned long chargingStartTime;
unsigned long nextCheckTime;
unsigned long nextEnableTime;
unsigned long nextPrintTime;
unsigned long nextSlopeTime;
};
#endif
Kannst ja mal probieren, ob das dann besser funktioniert.// Ardumower Sunray
// Copyright (c) 2013-2020 by Alexander Grau, Grau GmbH
// Licensed GPLv3 for open source use
// or Grau GmbH Commercial License for commercial use (http://grauonline.de/cms2/?page_id=153)
#include "battery.h"
#include "config.h"
#include "helper.h"
#include "motor.h"
#include "robot.h"
#include "buzzer.h"
#include <Arduino.h>
// lithium akkus sollten bis zu einem bestimmten wert CC also constant current geladen werden
// und danach mit CV constant voltage
// um die lebensdauer zu erhöhen kann man die max spannung herabsetzen
// wir verwenden im Ardumower ein 7S (7 * 4.2V)
// voll geladen ist dann bei 29.4V schluss
// wenn man z.B. die spannung von 4.2V pro zelle auf 4.1V herab setzt (85–90% charged) kann man die lebensdauer
// verdoppeln - das gleiche gilt bei der endladung
// lithium cells
// ardumower: Sony US18650 VTC5, 7 cells in series, nominal volage 3.6v
// alfred: Samsung INR18650-15M, 7 cells in series, nominal voltage 3.6v
void Battery::begin()
{
startupPhase = 0;
nextBatteryTime = 0;
nextCheckTime = 0;
nextEnableTime = 0;
batteryVoltageSlopeLowCounter = 0;
nextSlopeTime = 0;
timeMinutes=0;
chargingVoltage = 0;
chargingEnabledDelay =0;
chargingCompletedDelay =0;
batteryVoltage = 0;
chargerConnectedState = false;
badChargerContactState = false;
chargingCompleted = false;
chargingEnabled = true;
docked = false;
batMonitor = true; // monitor battery and charge voltage?
batGoHomeIfBelow = GO_HOME_VOLTAGE; // 21.5 drive home voltage (Volt)
batSwitchOffIfBelow = 18.9; // switch off battery if below voltage (Volt)
batSwitchOffIfIdle = 300; // switch off battery if idle (seconds)
// The battery will charge if both battery voltage is below that value and charging current is above that value.
batFullCurrent = BAT_FULL_CURRENT; // 0.2 current flowing when battery is fully charged (A)
batFullVoltage = BAT_FULL_VOLTAGE; //28.7 voltage when battery is fully charged (we charge to only 90% to increase battery life time)
enableChargingTimeout = 10 * 60; // if battery is full, wait this time before enabling charging again (seconds)
startChargingIfBelow = batFullVoltage - 0.05; // start charging if battery voltage is below this value.
batteryVoltage = 0;
batteryVoltageLast = 0;
batteryVoltageSlope = 0;
chargingVoltBatteryVoltDiff = 0;
switchOffByOperator = false;
switchOffAllowedUndervoltage = BAT_SWITCH_OFF_UNDERVOLTAGE;
switchOffAllowedIdle = BAT_SWITCH_OFF_IDLE;
enableCharging(false);
resetIdle();
}
// controls charging relay
void Battery::enableCharging(bool flag){
if (chargingEnabled == flag) return;
DEBUG(F("enableCharging "));
DEBUGLN(flag);
chargingEnabled = flag;
batteryDriver.enableCharging(flag);
nextPrintTime = 0;
}
bool Battery::chargerConnected(){
return chargerConnectedState;
}
bool Battery::isDocked(){
return docked;
}
void Battery::setIsDocked(bool state){
CONSOLE.print("battery.setIsDocked ");
CONSOLE.println(state);
docked = state;
}
bool Battery::badChargerContact(){
return badChargerContactState;
}
bool Battery::chargingHasCompleted(){
return chargingCompleted;
}
bool Battery::shouldGoHome(){
if (startupPhase < 2) return false;
return (batteryVoltage < batGoHomeIfBelow);
}
bool Battery::underVoltage(){
if (startupPhase < 2) return false;
return (batteryVoltage < batSwitchOffIfBelow);
}
void Battery::resetIdle(){
switchOffTime = millis() + batSwitchOffIfIdle * 1000;
}
void Battery::switchOff(){
CONSOLE.println("switching-off battery by operator...");
switchOffByOperator = true;
}
void Battery::run(){
if (startupPhase == 0) {
// give some time to establish communication to external hardware etc.
nextBatteryTime = millis() + 2000;
startupPhase++;
return;
}
if (millis() < nextBatteryTime) return;
nextBatteryTime = millis() + 50;
if (startupPhase == 1) startupPhase = 2;
// voltage
float voltage = batteryDriver.getChargeVoltage();
if (abs(chargingVoltage-voltage) > 10) {
chargingVoltage = voltage;
chargingVoltBatteryVoltDiff = 0;
}
chargingVoltage = 0.9 * chargingVoltage + 0.1* voltage;
voltage = batteryDriver.getBatteryVoltage();
if (abs(batteryVoltage-voltage) > 10) {
batteryVoltage = voltage;
batteryVoltageLast = voltage;
chargingVoltBatteryVoltDiff = 0;
}
float w = 0.997;
//if (chargerConnectedState) w = 0.9;
if (chargingEnabled) w = 0.9;
batteryVoltage = w * batteryVoltage + (1.0-w) * voltage;
// difference charging voltage and battery voltage
chargingVoltBatteryVoltDiff = 0.99 * chargingVoltBatteryVoltDiff + 0.01 * (chargingVoltage - batteryVoltage);
// current
chargingCurrent = w * chargingCurrent + (1.0-w) * batteryDriver.getChargeCurrent();
if (!chargerConnectedState){
if (chargingVoltage > 7){
chargerConnectedState = true;
DEBUG(F("CHARGER CONNECTED chgV="));
DEBUG(chargingVoltage);
DEBUG(F(" batV="));
DEBUGLN(batteryVoltage);
buzzer.sound(SND_OVERCURRENT, true);
}
}
if (millis() >= nextCheckTime){
nextCheckTime = millis() + 5000;
if (chargerConnectedState){
if (chargingVoltage <= 5){
chargerConnectedState = false;
nextEnableTime = millis() + 5000; // reset charging enable time
DEBUG(F("CHARGER DISCONNECTED chgV="));
DEBUG(chargingVoltage);
DEBUG(F(" batV="));
DEBUGLN(batteryVoltage);
}
}
timeMinutes = (millis()-chargingStartTime) / 1000 /60;
if (underVoltage()) {
DEBUG(F("SWITCHING OFF (undervoltage) batV="));
DEBUG(batteryVoltage);
DEBUG("<");
DEBUGLN(batSwitchOffIfBelow);
buzzer.sound(SND_OVERCURRENT, true);
if (switchOffAllowedUndervoltage) batteryDriver.keepPowerOn(false);
} else if ((millis() >= switchOffTime) || (switchOffByOperator)) {
if ((switchOffAllowedIdle) || (switchOffByOperator)) {
DEBUGLN(F("SWITCHING OFF (idle timeout)"));
buzzer.sound(SND_OVERCURRENT, true);
batteryDriver.keepPowerOn(false);
}
} else batteryDriver.keepPowerOn(true);
// battery volage slope
//float w = 0.999;
float w = 0.975; // 80% of of voltagejump in about 5 minutes
batteryVoltageSlope = w * batteryVoltageSlope + (1-w) * (batteryVoltage - batteryVoltageLast) * 60.0/5.0; // 5s => 1min
batteryVoltageLast = batteryVoltage;
if (millis() >= nextSlopeTime){
nextSlopeTime = millis() + 60000; // 1 minute
badChargerContactState = false;
if (chargerConnectedState){
if (!chargingCompleted){
if (chargingVoltBatteryVoltDiff < -1.0){
//if (batteryVoltageSlope < 0){
badChargerContactState = true;
DEBUG(F("CHARGER BAD CONTACT chgV="));
DEBUG(chargingVoltage);
DEBUG(" batV=");
DEBUG(batteryVoltage);
DEBUG(" diffV=");
DEBUG(chargingVoltBatteryVoltDiff);
DEBUG(" slope(v/min)=");
DEBUGLN(batteryVoltageSlope);
}
}
}
if (abs(batteryVoltageSlope) < 0.002){
batteryVoltageSlopeLowCounter = min(10, batteryVoltageSlopeLowCounter + 1);
} else {
batteryVoltageSlopeLowCounter = 0; //max(0, batteryVoltageSlopeLowCounter - 1);
}
}
if (millis() >= nextPrintTime){
nextPrintTime = millis() + 60000; // 1 minute
//print();
/*DEBUG(F("charger conn="));
DEBUG(chargerConnected());
DEBUG(F(" chgEnabled="));
DEBUG(chargingEnabled);
DEBUG(F(" chgTime="));
DEBUG(timeMinutes);
DEBUG(F(" charger: "));
DEBUG(chargingVoltage);
DEBUG(F(" V "));
DEBUG(chargingCurrent);
DEBUG(F(" A "));
DEBUG(F(" bat: "));
DEBUG(batteryVoltage);
DEBUG(F(" V "));
DEBUG(F("switchOffAllowed="));
DEBUG(switchOffAllowed);
DEBUGLN(); */
}
}
if (millis() > nextEnableTime){
nextEnableTime = millis() + 5000;
if (chargerConnectedState){
// charger in connected state
if (chargingEnabled){
//if ((timeMinutes > 180) || (chargingCurrent < batFullCurrent)) {
// https://github.com/Ardumower/Sunray/issues/32
if (chargingCompletedDelay >= 12) { // chargingCompleted check first after 12 * 5000ms = 60sec.
chargingCompleted = ((chargingCurrent <= batFullCurrent) || (batteryVoltage >= batFullVoltage) || (batteryVoltageSlopeLowCounter > 5));
}else{
chargingCompletedDelay++;
}
if (chargingCompleted) {
// stop charging
nextEnableTime = millis() + 1000 * enableChargingTimeout; // check charging current again in X minutes
batteryVoltageSlopeLowCounter = 0; // reset Counter for new Start
enableCharging(false);
}
}else{
if(batteryVoltage < startChargingIfBelow){chargingEnabledDelay++;}else{chargingEnabledDelay = 0;}
if (chargingEnabledDelay >= 6 || batteryVoltage < (batFullVoltage - 1.0)) {
// start charging
chargingCompleted = false;
chargingCompletedDelay = 0; // reset chargingCompleteted delay counter
chargingEnabledDelay = 0;
enableCharging(true);
chargingStartTime = millis();
}
}
}else{
// reset to avoid direct undocking after docking
chargingCompleted = false;
chargingCompletedDelay = 0; // reset chargingCompleteted delay counter
}
}
}

Silberstreifen
Active member
nein, beide Werte (Akkuspannung und Ladestrom) kannst du in der config.h einstellen und werden berücksichtigt.Hi,
ist es wirklich so, daß die Akkuspannung als Kriterium für den Ladezustand benutzt wird?
Eine Auswertung des Stromes findet nicht statt?
Grüße
Andreas