Du verwendest einen veralteten Browser. Es ist möglich, dass diese oder andere Websites nicht korrekt angezeigt werden.
Du solltest ein Upgrade durchführen oder einen alternativen Browser verwenden.
Du solltest ein Upgrade durchführen oder einen alternativen Browser verwenden.
NGP driver for PCB1.4
- Ersteller bernard
- Erstellt am

You probably mean a modified NGP firmware ("rm18.ino") for the PCB1.4 to be used for the existing "SerialRobotDriver"  ... (so not a new Sunray driver, but a new PCB1.4 firmware for the SerialRobotDriver?) - or what exactly is you goal?

 github.com
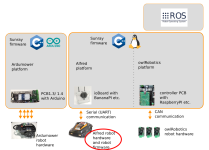
AmRobotDriver (Arduino): PCB1.4 hardware
SerialRobotDriver (Raspberry): using serial interface to control NGP ("rm18.ino") or other firmware
CanRobotDriver (Raspberry): using CAN bus interface to control owlPlatform hardware
... (so not a new Sunray driver, but a new PCB1.4 firmware for the SerialRobotDriver?) - or what exactly is you goal? Sunray/alfred/firmware at master · Ardumower/Sunray
Ardumower Sunray. Contribute to Ardumower/Sunray development by creating an account on GitHub.
github.com
AmRobotDriver (Arduino): PCB1.4 hardware
SerialRobotDriver (Raspberry): using serial interface to control NGP ("rm18.ino") or other firmware
CanRobotDriver (Raspberry): using CAN bus interface to control owlPlatform hardware
Zuletzt bearbeitet:

EinEinfach
Well-known member
I did some try’s and wrote ngp fw for due, I was able compile and run it on due, but without PCB 1.4. some parts was missing (like watchdog). I2C is also connected directly to RPI. I don’t know why I didn’t finished it, maybe because I switched to pico in my project.
If you interested in my work progress, I can look on my old pc if I find my modified code
If you interested in my work progress, I can look on my old pc if I find my modified code
This is what i mean :or what exactly is you goal?
SerialRobotDriver (Raspberry): using serial interface to control NGP with a firmware into AGCM4
,so i think it's the same process as ALFRED, but with PCB1.3 or 1.4 and AGCM4.
My actual issue:
On some area (free of tree or wall) mower run hundred of time and back to station without any stop in full auto mode , and on other area with big tree ,GPS jump into invalid or float very often .
And inside my garage it's Invalid if GPS is connected to PCB and Float when i connect it in my laptop (antenna at the same location)
Also i never see any issue on RTK in my LUBA in all location always Fix.
So maybe i can try to connect directly the GPS to raspberry Pi port and check if it's not a power supply issue or noise coming from PCB1.3 supply.
Yes of course, if you can find it ,it help me to write the AGCM4 firmware.I did some try’s and wrote ngp fw for due, I was able compile and run it on due, but without PCB 1.4. some parts was missing (like watchdog). I2C is also connected directly to RPI. I don’t know why I didn’t finished it, maybe because I switched to pico in my project.
If you interested in my work progress, I can look on my old pc if I find my modified code
EinEinfach
Well-known member
Ok, just create a VS-Code Platform IO project for due, and replace the content of main.cpp with this code. Compiling still working. I'm not sure, but I think you have to connect RPI over Due native port for serial communication.
P.S.: Watchdog seems woking too
P.S.: Watchdog seems woking too
C++:
/*
  Alfred MCU firmware (for RM24A/18 robot mower)
  provides Sunray-compatible robot driver (serial robot driver)
  NOTE: For compiling this file on the Alfred, see README (https://github.com/Ardumower/Sunray/blob/master/alfred/README.md)

  * MCU1 (main): STM32F103VET 512K flash/64K SRAM
        flash size       0x80000
        bootloader start 0x8000000
  * MCU2 (perimeter): STM32F302xB-xC/STM32F303xB-xC (Cortex-M4, 256 KB)
  * 2x A4931ET BL driver ( https://inst.eecs.berkeley.edu/~ee192/sp18/files/A4931-Datasheet.pdf )
  *   Hangzhou Ruimeng Tech MS4931  (https://datasheet.lcsc.com/lcsc/1809131539_Hangzhou-Ruimeng-Tech-MS4931_C231944.pdf)
  * TM1652 display ( https://github.com/maxint-rd/TM16xx )

  RM24  J1 display SWD connectors (top: peri MCU, bottom: main MCU)
    1 rst
    2 sda
    3 clk
    4 GND
    5 3.3V

  STM32 F4 discovery SWD connector (if used as ST-Link programmer)
    1
    2 clk
    3 GND
    4 sda
    5 rst
    6

  RM24  P15 serial2 connector     Arduino
    1 TX                            RX1
    2 RX                            TX1
    3 GND                           GND
    4 5V                            5V

  --------------NOT USED---------------------
  J1: perimeter,  J2: main unit

  RM24  16 pin display connector (top pcb view)
    16 J1_SWDIO                15 J1_NRST
    14 J1_SWCLK                13 J1_3.3V
    12 J2_SWRST                11 PD10/safekey
    10 PC7/home                9 PC8/start
    8  PC9/area3/softRx        7 PA8/area2
    6  PA9/area1/tx1/softTx    5 PA11/led_status
    4  J2_SWDIO                3 J2_SWCLK
    2  GND                     1 J2_3.3V

  RM24  BL motor connector
    HC   HB  HA  5v
    GND  U   v   W


  steps for compiling on a PC:

  1. install Arduino STM32 board libraries ('STMicroelectronics 1.9.0'):   https://github.com/stm32duino/Arduino_Core_STM32
     https://idyl.io/arduino/how-to/program-stm32-blue-pill-stm32f103c8t6/

  2. Using Arduino IDE:
    a) choose board: Generic STM32F1 series
    b) part number: Generic F103VE
    c) flash this file ('rm18.ino') to bottom MCU J1 via ST-Link (SWD protocol)
     st-link v2 tool: https://github.com/rogerclarkmelbourne/Arduino_STM32/tree/master/tools/win/stlink

  3. flash sunray.ino with these chassis settings:
    #define DRV_SERIAL_ROBOT  1
    #define MPU6050
    #define TICKS_PER_REVOLUTION  304
    #define WHEEL_BASE_CM         39         // wheel-to-wheel distance (cm), 36
    #define WHEEL_DIAMETER        205        // wheel diameter (mm), 250
    #define MOTOR_PID_KP     1.0    // AM 2.0
    #define MOTOR_PID_KI     0.0    // AM 0.03
    #define MOTOR_PID_KD     0.0    // AM 0.03


  protocol examples:
    request protocol version:  AT+V,0x16

*/

//#include <IWatchdog.h>
//#include <SoftwareSerial.h>
#include <Arduino.h>

//#define DEBUG 1

#define VER "Arduino DUE,1.0.0"

#define pinSwdCLK          PA14
#define pinSwdSDA          PA13

#define pinRain            44
#define pinLift2           35
#define pinLift1           35
#define pinLift1_2         PB0
#define pinBumperX         39
#define pinBumperY         38

#define pinBatteryT        PA6
#define pinChargeV         PA7
#define pinChargeV2        PB1
#define pinChargeI         PC4
#define pinBatteryV        PC5
#define pinBatteryRX       PB6

#define pinMotorRightPWM   3
//#define pinMotorRightBrake PB12
#define pinMotorRightDir   33
#define pinMotorRightImp   CANRX
#define pinMotorRightCurr  A0

#define pinMotorLeftPWM    5
//#define pinMotorLeftBrake  PD8
#define pinMotorLeftDir    31
#define pinMotorLeftImp    DAC0
#define pinMotorLeftCurr   A1

#define pinMotorMowPWM     2
#define pinMotorMowImp     A11
//#define pinMotorMowBrake   PB15
#define pinMotorMowDir     29
#define pinMotorMowFault   26
#define pinMotorMowCurr    A3

#define pinOVCheck         PE14

#define pinKeySafe         PD10
#define pinRelay           PD11

#define pinPower           PD12
#define pinCheckPower      PD13

#define pinKeyHome         PC7
#define pinKeyStart        PC8
#define pinKeyArea3        PC9
#define pinKeyArea2        PA8
#define pinKeyArea1        PA9    // same as pinUsart1TX
#define pinKeyLED          PA10   // same as pinUsart1RX
#define pinKeyLEDStatus    PA11
#define pinStopButtonB     PD7
//#define pinStopButton      PD2

// STM32F302xB-xC/STM32F303xB-xC (Cortex-M4, 256 KB)
#define pinUsartRX3        PC11
#define pinUsartTX3        PC10

#define pinLoraReset       PC12
#define pinLoraSCK         PB3
#define pinLoraMISO        PB4
#define pinLoraMOSI        PB5
#define pinLoraBusy        PE1

#define pinBluetoothTX     PD5
#define pinBluetoothRX     PD6

#define pinUsart1RX        PA10  // same as pinKeyLED
#define pinUsart1TX        PA9   // same as pinKeyArea1

#define pinMpuEnable       PB7
#define pinSCL             PB8
#define pinSDA             PB9
#define pinWpEEPROM        PE0

//#define TEST_PIN_ODOMETRY 1
//#define TEST_PINS  1

volatile int odomTicksLeft  = 0;
volatile int odomTicksRight = 0;
volatile int odomTicksMow = 0;

volatile unsigned long motorLeftTicksTimeout = 0;
volatile unsigned long motorRightTicksTimeout = 0;
volatile unsigned long motorMowTicksTimeout = 0;

volatile unsigned long motorLeftTransitionTime = 0;
volatile unsigned long motorRightTransitionTime = 0;
volatile unsigned long motorMowTransitionTime = 0;

volatile float motorLeftDurationMax = 0;
volatile float motorRightDurationMax = 0;
volatile float motorMowDurationMax = 0;

volatile bool stopButton = false;
volatile int testValue = false;


float batVoltage = 0;
float batVoltageLP = 0;
float chgVoltage = 0;
float chgCurrent = 0;
float chgCurrentLP = 0;
float mowCurr = 0;
float mowCurrLP = 0;
int mowRecoveryState = 0;
float motorLeftCurr = 0;
float motorRightCurr = 0;
float motorLeftCurrLP = 0;
float motorRightCurrLP = 0;
float batteryTemp = 0;
int leftSpeedSet = 0;
int rightSpeedSet = 0;
int mowSpeedSet = 0;
//float leftSpeedCurr = 0;
//float rightSpeedCurr = 0;
//float mowSpeedCurr = 0;
bool motorOverload = false;
bool motorMowFault = false;
int bumperX = 0;
int bumperY = 0;
int liftLeft = 0;
int liftRight = 0;
int rain = 0;
float rainLP = 0;
bool raining = false;
bool lift = false;
float liftLeftLP = 0;
float liftRightLP = 0;
bool bumper = false;
bool ovCheck = false;
bool enableTractionBrakes = false;
bool chargerConnected = false;

String cmd;
String cmdResponse;

unsigned long motorTimeout = 0;
unsigned long motorOverloadTimeout = 0;
unsigned long nextBatTime = 0;
unsigned long nextMotorSenseTime = 0;
unsigned long stopButtonTimeout = 0;
unsigned long nextMotorControlTime = 0;
unsigned long mowBrakeStateTimeout = 0;
int mowBrakeState = 0;

// choose one UART to use for communication
//HardwareSerial mSerial(pinUsartRX3, pinUsartTX3);  // rx, tx        - UART for perimeter MCU comm
//HardwareSerial mSerial(pinUsart1RX, pinUsart1TX); // rx, tx         - UART available at display panel
//SoftwareSerial mSerial(pinKeyArea3, pinKeyArea1);   // rx, tx        - SoftUART available at display panel
//HardwareSerial mSerial2(pinBluetoothRX, pinBluetoothTX);  // rx, tx  - UART available at NGP PCB

//#define CONSOLE mSerial
#define CONSOLE SerialUSB
//#define CONSOLE_BAUDRATE 19200 // 9600
#define CONSOLE_BAUDRATE 115200

//#define CONSOLE2 mSerial2
#define CONSOLE2 Serial
#define CONSOLE2_BAUDRATE 115200


//#define SUPER_SPIKE_ELIMINATOR 1  // advanced spike elimination  (experimental, comment out to disable)


// answer Bluetooth with CRC
void cmdAnswer(String s){
  byte crc = 0;
  for (int i=0; i < s.length(); i++) crc += s[i];
  s += F(",0x");
  if (crc <= 0xF) s += F("0");
  s += String(crc, HEX);
  s += F("\r\n");
  //CONSOLE.print(s);
  cmdResponse = s;
}

void OdometryMowISR(){
  if (digitalRead(pinMotorMowImp) == LOW) return;
  if (millis() < motorMowTicksTimeout) return; // eliminate spikes
  #ifdef SUPER_SPIKE_ELIMINATOR
    unsigned long duration = millis() - motorMowTransitionTime;
    if (duration > 5) duration = 0;
    motorMowTransitionTime = millis();
    motorMowDurationMax = 0.7 * max(((float)motorMowDurationMax), ((float)duration));
    motorMowTicksTimeout = millis() + motorMowDurationMax;
  #else
    motorMowTicksTimeout = millis() + 3;
  #endif
  odomTicksMow++;
}

void OdometryLeftISR(){
  if (digitalRead(pinMotorLeftImp) == LOW) return;
  if (millis() < motorLeftTicksTimeout) return; // eliminate spikes
  #ifdef SUPER_SPIKE_ELIMINATOR
    unsigned long duration = millis() - motorLeftTransitionTime;
    if (duration > 5) duration = 0;
    motorLeftTransitionTime = millis();
    motorLeftDurationMax = 0.7 * max(((float)motorLeftDurationMax), ((float)duration));
    motorLeftTicksTimeout = millis() + motorLeftDurationMax;
  #else
    motorLeftTicksTimeout = millis() + 3;
  #endif
  odomTicksLeft++;
}

void OdometryRightISR(){
  if (digitalRead(pinMotorRightImp) == LOW) return;
  if (millis() < motorRightTicksTimeout) return; // eliminate spikes
  #ifdef SUPER_SPIKE_ELIMINATOR
    unsigned long duration = millis() - motorRightTransitionTime;
    if (duration > 5) duration = 0;
    motorRightTransitionTime = millis();
    motorRightDurationMax = 0.7 * max(((float)motorRightDurationMax), ((float)duration));
    motorRightTicksTimeout = millis() + motorRightDurationMax;
  #else
    motorRightTicksTimeout = millis() + 3;
  #endif
  odomTicksRight++;

  #ifdef TEST_PIN_ODOMETRY
    testValue = !testValue;
    digitalWrite(pinKeyArea2, testValue);
  #endif
}

// void stopButtonISR(){
//   if (millis() < stopButtonTimeout) return;
//   stopButtonTimeout = millis() + 5;
//   if (digitalRead(pinStopButton) == HIGH){
//     stopButton = true;
//   } else {
//     stopButton = false;
//   }
// }

void mower(){
  if (abs(mowSpeedSet) > 0){
    if (millis() > mowBrakeStateTimeout){
      mowBrakeStateTimeout = millis() + 1000;
      if (mowSpeedSet >= 0){
        digitalWrite(pinMotorMowDir, LOW);  // set mower direction forward
      } else {
        digitalWrite(pinMotorMowDir, HIGH); // set mower direction backwards
      }
      if (mowBrakeState >= 3){
        //digitalWrite(pinRelay, HIGH); // motor brake off
        //analogWrite(pinMotorMowPWM, 255);
        analogWrite(pinMotorMowPWM, mowSpeedSet);  // set mower speed
      }
      // else {
      //   if (mowBrakeState % 2 == 0){
      //     digitalWrite(pinRelay, HIGH); // motor brake off
      //     analogWrite(pinMotorMowPWM, 255);
      //   } else {
      //     digitalWrite(pinRelay, LOW); // motor brake on
      //     analogWrite(pinMotorMowPWM, 0);
      //   }
      // }
      if (mowBrakeState < 20) mowBrakeState++;
    }
  } else {
    mowBrakeStateTimeout = millis();
    mowBrakeState = 0;
    //digitalWrite(pinRelay, LOW);  // motor brake on
    analogWrite(pinMotorMowPWM, 0); // mower speed zero
  }
}

// void power(bool flag){
//   if (flag){
//     digitalWrite(pinPower, HIGH);
//   } else {
//     digitalWrite(pinPower, LOW);
//   }
// }

// 0 = off, 255 = full speed
void motor(){
  enableTractionBrakes = false;
  if (motorOverload) {
    leftSpeedSet = 0;
    rightSpeedSet = 0;
  }

  // bugfix MS4931 brushless driver sending incorrectly odometry/tire speeds for very low PWM values (e.g. 5)
  if ((leftSpeedSet > 0) && (leftSpeedSet < 15)) leftSpeedSet = 15;
  if ((rightSpeedSet > 0) && (rightSpeedSet < 15)) rightSpeedSet = 15;
  if ((leftSpeedSet < 0) && (leftSpeedSet > -15)) leftSpeedSet = -15;
  if ((rightSpeedSet < 0) && (rightSpeedSet > -15)) rightSpeedSet = -15;

  // traction brakes
  if ((leftSpeedSet == 0) && (rightSpeedSet == 0)){
    enableTractionBrakes = true;
  }

  // ----- left traction motor ------
  // verhindert dass das PWM Signal 0 wird. Der Driver braucht einen kurzen Impuls um das PWM zu erkennen.
  // Wenn der z.B. vom max. PWM Wert auf 0 bzw. das Signal auf Low geht, behält er den vorherigen Wert bei und der Motor stoppt nicht
  //if (abs(leftSpeedSet) < 2) {
  //  if (leftSpeedSet > 0) leftSpeedSet = 2;
  //    else leftSpeedSet = -2;
  //}
  if (leftSpeedSet >= 0){
    digitalWrite(pinMotorLeftDir, HIGH);
  } else {
    digitalWrite(pinMotorLeftDir, LOW);
  }
  analogWrite(pinMotorLeftPWM, 255-abs(leftSpeedSet));
  //digitalWrite(pinMotorLeftBrake, !enableTractionBrakes);   // set brakes

  // ----- right traction motor ------
  // verhindert dass das PWM Signal 0 wird. Der Driver braucht einen kurzen Impuls um das PWM zu erkennen.
  // Wenn der z.B. vom max. PWM Wert auf 0 bzw. das Signal auf Low geht, behält er den vorherigen Wert bei und der Motor stoppt nicht
  //if (abs(rightSpeedSet) < 2) {
  //  if (rightSpeedSet > 0) rightSpeedSet = 2;
  //   else rightSpeedSet = -2;
  //}
  if (rightSpeedSet >= 0){
    digitalWrite(pinMotorRightDir, LOW);
  } else {
    digitalWrite(pinMotorRightDir, HIGH);
  }
  analogWrite(pinMotorRightPWM, 255-abs(rightSpeedSet));
  //digitalWrite(pinMotorRightBrake, !enableTractionBrakes);  // set brakes
}


void readSensorsHighFrequency(){
  //chgVoltage = ((float)analogRead(pinChargeV))/25.0 + 3.0;
  chgVoltage = 0;
  bool connected = (chgVoltage > 7.0);
  if (chargerConnected != connected) {
    // charger connected/unconnected event
    chargerConnected = connected;
  }
}

void readSensors(){
  if (millis() > stopButtonTimeout + 20000){
    stopButton = false;
  }
  // battery  voltage
  //batVoltage = ((float)analogRead(pinBatteryV))/25.0 + 3.0;
  batVoltage = 25;
  float w = 0.99;
  batVoltageLP = w * batVoltageLP + (1.0-w) * batVoltage;

  //batteryTemp = ((float)analogRead(pinChargeV)) / 10.0 - 50.0;
  batteryTemp = 20;
  //ovCheck = digitalRead(pinOVCheck);
  ovCheck = LOW;
  motorMowFault = (digitalRead(pinMotorMowFault) == LOW);
  motorMowFault = HIGH;

  // rain (lift low-pass filtering)
  rain = analogRead(pinRain);
  w = 0.99;
  rainLP = w * rainLP + (1.0-w) * ((float)rain);
  raining = (rainLP > 50);

  // lift
  liftRight = digitalRead(pinLift1);
  liftLeft = digitalRead(pinLift2);

  // bumper (low-pass filtering)
  bumperX = digitalRead(pinBumperX);
  bumperY = digitalRead(pinBumperY);
  bumper = !bumperX || !bumperY;

  lift = !liftRight || !liftLeft;


#ifdef DEBUG
  if (stopButton){
    CONSOLE.println("STOP BUTTON");
  }
  if (lift){
    CONSOLE.println("LIFT");
  }
  if (bumper){
    CONSOLE.println("BUMPER");
  }
  if (motorMowFault){
    CONSOLE.println("MOTOR MOW FAULT");
  }
#endif
}


// read left/right gear motor current
void readMotorCurrent(){
  // calibrated on 'black/orange' NGP robot:
  //motorLeftCurr = ((float)analogRead(pinMotorLeftCurr)) / 150.0;
  //motorRightCurr = ((float)analogRead(pinMotorRightCurr)) / 150.0;
  //mowCurr = ((float)analogRead(pinMotorMowCurr)) / 65.0;

  // calibrated on 'grey/orange' NGP robot:
  motorLeftCurr = pow( ((float)analogRead(pinMotorLeftCurr)), 1.0/3.0) /4.0;
  motorRightCurr = pow( ((float)analogRead(pinMotorRightCurr)), 1.0/3.0) /4.0;
  mowCurr = pow( ((float)analogRead(pinMotorMowCurr)), 1.0/3.0) /2.0;

  // low-pass filter
  float w = 0.9;
  motorLeftCurrLP  = w * motorLeftCurrLP + (1.0-w) * motorLeftCurr;
  motorRightCurrLP = w * motorRightCurrLP + (1.0-w) * motorRightCurr;
  w = 0.99;
  mowCurrLP = w * mowCurrLP + (1.0-w) * mowCurr;

  if ((mowCurrLP > 4.0) || (motorLeftCurrLP > 1.5) || (motorRightCurrLP > 1.5)) {
    // too much current: turn off motors
    //motor(0, 0);
    //mower(false);
    motorOverload = true;
    motorOverloadTimeout = millis() + 2000;
  }

  // charging current (reading charging current does not work for some reason...)
  // maximum charging current is 1.7 amps
  //chgCurrent = ((float)analogRead(pinChargeI)) * 1.0;
  chgCurrent = 0;
  w = 0.99;
  chgCurrentLP = w * chgCurrentLP + (1.0-w) * chgCurrent;

  motorLeftCurrLP = 0.1;
  motorRightCurrLP = 0.1;
  mowCurrLP = 0.1;
}


void setup() {

  // power
  //pinMode(pinPower, INPUT);
  //pinMode(pinCheckPower, INPUT);
  //power(true);

  delay(2000);
  CONSOLE.begin(CONSOLE_BAUDRATE);
  CONSOLE2.begin(CONSOLE2_BAUDRATE);

  #ifdef TEST_PIN_ODOMETRY
    pinMode(pinKeyArea2, OUTPUT); // odometry test pin
  #endif

  #ifdef TEST_PINS
    // for testing only
    pinMode(pinKeyStart, OUTPUT);
    pinMode(pinKeyArea1, OUTPUT);
    pinMode(pinKeyArea2, OUTPUT);
    pinMode(pinKeyArea3, OUTPUT);
    pinMode(pinKeyHome, OUTPUT);
    pinMode(pinKeyLED, OUTPUT);
    pinMode(pinKeyLEDStatus, OUTPUT);
    pinMode(pinKeySafe, OUTPUT);
  #endif

  //pinMode(pinOVCheck, INPUT);
  pinMode(pinRain, INPUT);

  //battery
  //pinMode(pinBatteryV, INPUT);
  //pinMode(pinChargeV, INPUT);
  //pinMode(pinChargeI, INPUT);

  // lift
  pinMode(pinLift1, INPUT_PULLUP);
  pinMode(pinLift2, INPUT_PULLUP);

  // bumper (obstacle)
  pinMode(pinBumperX, INPUT_PULLUP);
  pinMode(pinBumperY, INPUT_PULLUP);

  // mower
  //analogWriteFrequency(20000); // 8000

  pinMode(pinMotorMowCurr, INPUT);
  pinMode(pinMotorMowPWM, OUTPUT);
  pinMode(pinMotorMowFault, INPUT_PULLUP);
  pinMode(pinMotorMowImp, INPUT_PULLUP);
  attachInterrupt(digitalPinToInterrupt(pinMotorMowImp), OdometryMowISR, CHANGE);
  //pinMode(pinRelay, OUTPUT);
  //pinMode(pinMotorMowBrake, OUTPUT);
  pinMode(pinMotorMowDir, OUTPUT);
  digitalWrite(pinMotorMowDir, HIGH);
  //digitalWrite(pinMotorMowBrake, LOW);


  // motor left
  pinMode(pinMotorLeftCurr, INPUT);
  pinMode(pinMotorLeftPWM, OUTPUT);
  //pinMode(pinMotorLeftBrake, OUTPUT);
  pinMode(pinMotorLeftDir, OUTPUT);
  pinMode(pinMotorLeftImp, INPUT_PULLUP);
  attachInterrupt(digitalPinToInterrupt(pinMotorLeftImp), OdometryLeftISR, CHANGE);

  // motor right
  pinMode(pinMotorRightCurr, INPUT);
  pinMode(pinMotorRightPWM, OUTPUT);
  //pinMode(pinMotorRightBrake, OUTPUT);
  pinMode(pinMotorRightDir, OUTPUT);
  pinMode(pinMotorRightImp, INPUT_PULLUP);
  attachInterrupt(digitalPinToInterrupt(pinMotorRightImp), OdometryRightISR, CHANGE);

  //pinMode(pinLoraSCK, OUTPUT);
  //pinMode(pinSCL, OUTPUT);
  //pinMode(pinLoraMOSI, OUTPUT);

  // emergency button:
  // The microcontroller has a built-in pull-up resistor of 50k.
  // Two emergency stop switches are connected in series, and the switch is normally closed - when the MCU detects a high level, it stops
  //pinMode(pinStopButton, INPUT_PULLUP);
  //pinMode(pinStopButtonB, OUTPUT);
  //digitalWrite(pinStopButtonB, LOW);
  //attachInterrupt(digitalPinToInterrupt(pinStopButton), stopButtonISR, CHANGE);

  //IWatchdog.begin(6000000); // 6sec
  watchdogSetup();
  watchdogEnable(6000L); // 6sec
}

unsigned nextInfoTime = 0;
int lps = 0;


// request motor
// AT+M,20,20,1
void cmdMotor(){
  if (cmd.length()<6) return;
  int counter = 0;
  int lastCommaIdx = 0;
  int left=0;
  int right=0;
  int mow=0;
  //bool mow=false;
  for (int idx=0; idx < cmd.length(); idx++){
    char ch = cmd[idx];
    //mSerial.print("ch=");
    //mSerial.println(ch);
    if ((ch == ',') || (idx == cmd.length()-1)){
      int intValue = cmd.substring(lastCommaIdx+1, ch==',' ? idx : idx+1).toInt();
      if (counter == 1){
          left = intValue;
      } else if (counter == 2){
          right = intValue;
      } else if (counter == 3){
          //mow = (intValue > 0);
          mow = intValue;
      }
      counter++;
      lastCommaIdx = idx;
    }
  }
#ifdef DEBUG
  CONSOLE.print("left=");
  CONSOLE.print(left);
  CONSOLE.print(" right=");
  CONSOLE.print(right);
  CONSOLE.print(" mow=");
  CONSOLE.println(mow);
#endif
  leftSpeedSet = left;
  rightSpeedSet = right;
  mowSpeedSet = mow;
  //if (mow) mowSpeedSet = 255;
  //  else mowSpeedSet = 0;
  //if (!motorOverload) {
    // non-overload state
    //motor(left, right);
    //mower(mow);
  //} else {
    // overload state
    //digitalWrite(pinMotorLeftBrake, LOW);  // enable brakes
    //digitalWrite(pinMotorRightBrake, LOW);  // enable brakes
  //}
  motorTimeout = millis() + 3000;
  String s = F("M");
  s += ",";
  s += odomTicksLeft;
  s += ",";
  s += odomTicksRight;
  s += ",";
  s += odomTicksMow;
  s += ",";
  s += chgVoltage;
  s += ",";
  s += int(bumper);
  s += ",";
  s += int(lift);
  s += ",";
  s += int(stopButton);
  cmdAnswer(s);
}

// perform hang test (watchdog should trigger)
void cmdTriggerWatchdog(){
  String s = F("Y");
  cmdAnswer(s);
  while(true); // never returns
}

// request version
void cmdVersion(){
  String s = F("V,");
  s += F(VER);
  cmdAnswer(s);
}


// request summary
void cmdSummary(){
  String s = F("S,");
  s += batVoltage;
  s += ",";
  s += chgVoltage;
  s += ",";
  s += chgCurrentLP;
  s += ",";
  s += int(lift);
  s += ",";
  s += int(bumper);
  s += ",";
  s += int(raining);
  s += ",";
  //s += int(motorMowFault);
  s += int(motorOverload);
  s += ",";
  s += mowCurrLP;
  s += ",";
  s += motorLeftCurrLP;
  s += ",";
  s += motorRightCurrLP;
  s += ",";
  s += batteryTemp;
  cmdAnswer(s);
}


// process request
void processCmd(bool checkCrc){
  cmdResponse = "";
  if (cmd.length() < 4) return;
  byte expectedCrc = 0;
  int idx = cmd.lastIndexOf(',');
  if (idx < 1){
    if (checkCrc){
#ifdef DEBUG
      CONSOLE.println("CRC ERROR");
#endif
      return;
    }
  } else {
    for (int i=0; i < idx; i++) expectedCrc += cmd[i];
    String s = cmd.substring(idx+1, idx+5);
    int crc = strtol(s.c_str(), NULL, 16);
    if (expectedCrc != crc){
      if (checkCrc){
#ifdef DEBUG
        CONSOLE.print("CRC ERROR");
        CONSOLE.print(crc,HEX);
        CONSOLE.print(",");
        CONSOLE.print(expectedCrc,HEX);
        CONSOLE.println();
#endif
        return;
      }
    } else {
      // remove CRC
      cmd = cmd.substring(0, idx);
      //CONSOLE.println(cmd);
    }
  }
  if (cmd[0] != 'A') return;
  if (cmd[1] != 'T') return;
  if (cmd[2] != '+') return;
  if (cmd[3] == 'V') cmdVersion();
  if (cmd[3] == 'M') cmdMotor();
  if (cmd[3] == 'S') cmdSummary();
  if (cmd[3] == 'Y') {
    if (cmd.length() <= 4){
      cmdTriggerWatchdog();   // for developers
    } else {
      //if (cmd[4] == '2') cmdGNSSReboot();   // for developers
      //if (cmd[4] == '3') cmdSwitchOffRobot();   // for developers
    }
  }

}


// process console input
void processConsole(){
  char ch;
  if (CONSOLE.available()) {
    unsigned long timeout = millis() + 10;
    //battery.resetIdle();
    while ( (CONSOLE.available()) && (millis() < timeout) ){
      ch = CONSOLE.read();
      if ((ch == '\r') || (ch == '\n')) {
#ifdef DEBUG
        CONSOLE.println(cmd);
#endif
        processCmd(true);
        CONSOLE.print(cmdResponse);
        cmd = "";
      } else if (cmd.length() < 500){
        cmd += ch;
      }
    }
  }
  if (CONSOLE2.available()) {
    unsigned long timeout = millis() + 10;
    //battery.resetIdle();
    while ( (CONSOLE2.available()) && (millis() < timeout) ){
      ch = CONSOLE2.read();
      if ((ch == '\r') || (ch == '\n')) {
#ifdef DEBUG
        CONSOLE2.println(cmd);
#endif
        processCmd(true);
        CONSOLE2.print(cmdResponse);
        cmd = "";
      } else if (cmd.length() < 500){
        cmd += ch;
      }
    }
  }
}


void printInfo(){
  CONSOLE.print("tim=");
  CONSOLE.print(millis() / 1000);
  CONSOLE.print(" lps=");
  CONSOLE.print(lps);
  CONSOLE.print(" bat=");
  CONSOLE.print(batVoltage);
  CONSOLE.print(" V");
  CONSOLE.print(" chg=");
  CONSOLE.print(chgVoltage);
  CONSOLE.print(" V/");
  CONSOLE.print(chgCurrent);
  CONSOLE.print(" A");
  CONSOLE.print(" mF=");
  CONSOLE.print(motorMowFault);
  CONSOLE.print(" imp=");
  CONSOLE.print(odomTicksLeft);
  CONSOLE.print(",");
  CONSOLE.print(odomTicksRight);
  CONSOLE.print(",");
  CONSOLE.print(odomTicksMow);
  CONSOLE.print(" ");
  CONSOLE.print(" lift=");
  CONSOLE.print(liftLeft);
  CONSOLE.print(",");
  CONSOLE.print(liftRight);
  CONSOLE.print(" bum=");
  CONSOLE.print(bumperX);
  CONSOLE.print(",");
  CONSOLE.print(bumperY);
  CONSOLE.print(" rain=");
  CONSOLE.print(rain);
  CONSOLE.print(" ov=");
  CONSOLE.print(ovCheck);
  CONSOLE.println();
}

void writePulse(int pin, int count){
  for (int i=0; i < count; i++){
    digitalWrite(pin, true);
    delay(1) ;
    digitalWrite(pin, false);
    delay(1);
  }
}

//


void loop() {

  if (millis() > nextMotorControlTime){
    nextMotorControlTime = millis() + 20;
    motor();
    mower();
    readSensorsHighFrequency();
  }

  if (millis() > motorTimeout){
    leftSpeedSet = 0;
    rightSpeedSet = 0;
    mowSpeedSet = 0;
    //motor(0,0);
    //mower(false);
  }

  processConsole();

  if (millis() > nextInfoTime){
    nextInfoTime = millis() + 1000;
    #ifdef DEBUG
      printInfo();
    #endif
    lps = 0;
    #ifdef TEST_PINS
      testPins();
    #endif
  }

  if (millis() > nextBatTime){
    nextBatTime = millis() + 100;
    readSensors();
  }

  if (millis() > nextMotorSenseTime){
    nextMotorSenseTime = millis() + 100;
    readMotorCurrent();
  }

  if (millis() > motorOverloadTimeout){
    // allow motor to turn on again after timeout
    motorOverload = false;
  }

  /*if (counter % 2 == 0){
    digitalWrite(pinLoraSCK, HIGH);
    digitalWrite(pinLoraMOSI, HIGH);
    digitalWrite(pinSCL, HIGH);
  } else {
    digitalWrite(pinLoraSCK, LOW);
    digitalWrite(pinLoraMOSI, LOW);
    digitalWrite(pinSCL, LOW);
  }*/

  lps++;
  //IWatchdog.reload();
  watchdogReset();
}