Is there a way to increase the speed when controlling to mower from sunray? I feel like the speed settings for float and fix are easy to find and modify but the controller speed I cannot change anywhere. Anyone have suggestion? @Mr. Tree not sure if you’ve messed with this in your code but it would be very nice to have a more dynamic speed of the robot.
Du verwendest einen veralteten Browser. Es ist möglich, dass diese oder andere Websites nicht korrekt angezeigt werden.
Du solltest ein Upgrade durchführen oder einen alternativen Browser verwenden.
Du solltest ein Upgrade durchführen oder einen alternativen Browser verwenden.
Mower speed from Sunray
- Ersteller mfethe
- Erstellt am
Michael1966
Member
I'm not sure if I understood you,
You can set how fast the rover should drive in the Spee(m/s) app. I have the best results with the default 0.20
Others can only be found in the Sunray master Adruino VG Michael
You can set how fast the rover should drive in the Spee(m/s) app. I have the best results with the default 0.20
Others can only be found in the Sunray master Adruino VG Michael

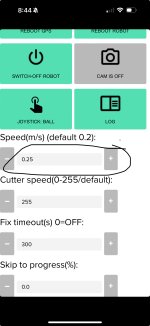
I think manual speed is not manageable by the user using sunray AppSo I should be able to control my robot speed here (see picture)? When I change it there I don’t see any difference in the joystick controlled speed just mowing speed.Anhang anzeigen 7497
The slider is for Auto mowing speed .
I'm using Alfred with Sunray, not Ardumower. During my implementation and set-up 2 years ago, I first used manual steering of Alfred with "Joystick-Ball" to record the perimeter and exclusions, but after some attempts switched to carrying the robot from point to point around the perimeter. Much quicker and more efficient in my view.
However I think to recall, the movement speed of the robot while using joystick ball was dependant on how far I moved the ball with my fingertip away from center (the more away from center the faster the robot moved in that direction).
For me on my small iPhone screen (or/and with my big fingertips ) that was too unprecise and cumbersome for perimeter recording. That's why I switched to carrying the robot around during set-up.
However I think to recall, the movement speed of the robot while using joystick ball was dependant on how far I moved the ball with my fingertip away from center (the more away from center the faster the robot moved in that direction).
For me on my small iPhone screen (or/and with my big fingertips
) that was too unprecise and cumbersome for perimeter recording. That's why I switched to carrying the robot around during set-up.