ICM20948 in Sunray verwenden

Algo

Active member
Da ich statt der der MPU6050 nun die neuere IMU ICM20948 mit Sunray verwende,
hier eine kleine Anleitung wie man sie, solange keine offizielle Unterstüzung in Sunray erfolgt ist, einbinden kann.

Vielen Dank an erster Stelle für die ganze Arbeit die @WhatATest sich gemacht hat!!!
Sein Pullrequest ist hier zu finden bzw. die Anleitung basiert auf dessen Daten:

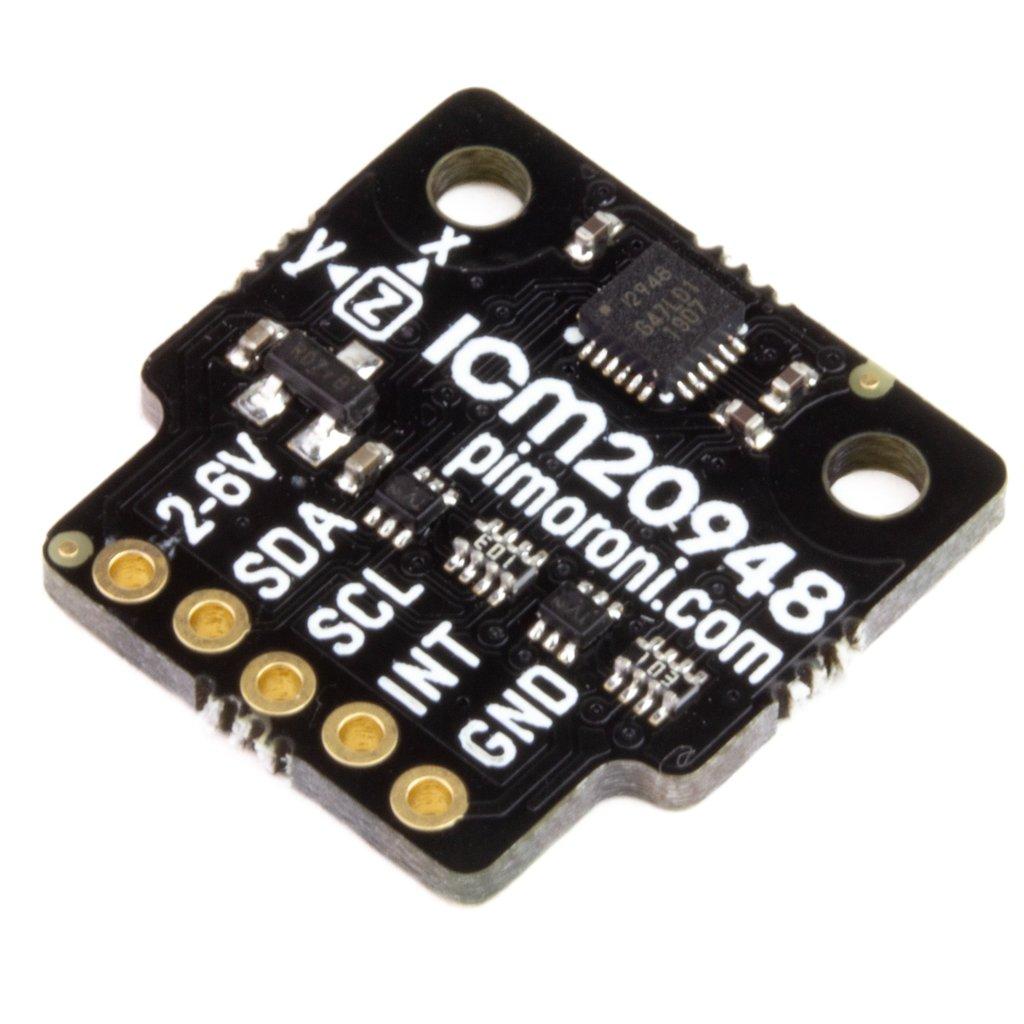
Ich habe die ICM20948 von Pimoroni in Verwendung
Sie wird genauso wie die MPU6050 angeschlossen, der INT Anschluss bleibt unbelegt.
Edit 27.05.2024:
Es muss noch die Verbinung beim ADDR+1 (roter Strich) beim Pimoroni durchtrennt werden:
1716796988165.png
Edit Ende

Eingangsspannung bzw. Jumper ist egal, weil sie 3,3V und auch 5V unterstützt.
Als Halterung habe ich meine https://www.thingiverse.com/thing:5022421 weiterverwendet, den letzten Halt erhält sie durch etwas Isolierband.

Nun zur Einbindung in Sunray (verwende den letzten Sunray Release 1.0318.
- Download des Brunch
- entpacken des Ordners aus dem Brunch sunray/src/icm in den Ordner vom SunrayRelease sunray/src
- entpacken der Dateien icmDriver.ccp und icmDriver.h aus dem Brunch sunray/src/driver in den Ordner vom SunrayRelease sunray/src/driver
- Alle Änderungen die hier mit dem orangen Kästchen links sind in den jeweiligen Dateien vom Sunrayrelease abändern bzw. ergänzen.
- in der config.h müssen dann sowohl die MPU6050 und ICM20948 aktiviert werden (nicht wundern, geht aktuell leider nicht anders)
 
Zuletzt bearbeitet:
Zitat "TDK InvenSense":
NRND (Not Recommended for New Design):
MPU6050/9050/9250/9255 etc.
ICM-20948/ICM-20648 etc.

Recommended for New Design (s. hier):
ICM-42670-P / ICM-42688-P

=> die oberen Chips wird es in ein paar Jahren nur noch schwer (bzw. teuer) für neue PCB's zu kaufen geben weil abgekündigte Chips in der Regel nicht mehr produziert werden (die Programmierung unterscheided sich teilweise erheblich, daher werden ständig neue Sunray-Software-Treiber benötigt und der "ICM-20948" ist auch nur ein weiterer Zwischenschritt ;)... PS: Der Pull-Request wurde mit einigen Korrekturen in den Master-Zweig eingepflegt - für 64-Bit Systeme wie Raspberry-PI muss das ganze noch getestet werden (da gab es für 64-Bit Systeme im MPU-Code einen Bugfix damit es mit der MPU-IMU lief) )
 
Zuletzt bearbeitet:
Hat der Sensor einen merklichen Vorteil zum MPU6050?
habe mal das Thema umbenannt, ich wollte das Thema hier eigentlich nur erstellen um eine alternative IMU verwenden zu können und die Einbindung in Sunray auch anderen zu erleichtern.

Persönlich hatte ich etliche Probleme mit den MPU6050, in meiner Mähggy ist die zweite drin, die geht immerhin nun schon seit 2 Jahren. Bei meinem zweiten Mäher hatte ich bisher kein Glück und bin daher froh um eine Alternative. Wenn ich mir einige Posts hier im Forum von anderen bzgl. der MPU6050 anschaue bin ich kein Einzelfall, die Qualität scheint sehr zu schwanken. Der Langzeittest fehlt natürlich bei der ICM20948.
Einen wirklichen Vorteil gibts meiner Meinung nach nicht so lange sie vefügbar ist und man eine funktionierende erwischt, die ICM ist teurer und die Funktionen sind ja an sich gleich was Sunray betrifft.

Aber schön, dass die Implementierung/Pullrequest von @WhatATest es nun in den Masterzweig gefunden hat. :) Danke Alexander
 
I just checked why a MPU needs to be defined.
Seems like the mpu library requires one to be defined to compile and arduino IDE tries compile everything whether its included or not.

Changing line 56 in inv_mpu.c from:
Code:
#error  Which gyro are you using? Define MPUxxxx in your compiler options.
to something like
Code:
#define MPU6050
should do the trick.
 
Zuletzt bearbeitet:
Hallo zusammen,

ich hab mal testweise auch zwei ICM20948 bestellt und wie beschrieben verlötet. AD0 gibt es beim ICM20948 nicht... also auch keine Brücke.
Die Einstellung auf ICM20948 in der config.h wurde in der Sunray 1.0.322 durchgeführt.
An den Jumpern auf dem v1.3 Board wurde nichts verändert (bleibt bei 3,3V)

Die Firmware lässt sich übertragen, aber wenn es an den Start geht, bekomme ich an der Stelle wo normaler weise die Kalibrierung läuft und mit Piepsen bestätigt wird einen "COMM CRC Error"

Wieder zurück auf die MPU6050 oder MPU9255 laufen beide sauber durch.

Da beide gekauften ICM20948 (von BerryBase) das gleiche Verhalten zeigen, möchte ich einen Hardwaredefekt erstmal ausschließen.

In welche Richtung kann ich noch suchen?

Besten Dank schonmal für Eure Hilfe

Martin
 
Hi WhatATest,

thanks for your help...

Code:
Test ICM20948 ##########################################

SD card found!
RESET cause: power-on
Sunray,1.0.319
compiled for: Adafruit Grand Central M4
using robot driver: AmRobotDriver
robot id: 77:06:87:48:53:35:37:4e:36:20:20:20:ff:03:33:47
MOTOR_DRIVER_BRUSHLESS: no
enableCharging 0
probing for HM-10 module (NOTE: will fail for ESP32)...
trying to detect Bluetooth 4.0/BLE (HM-10 module) (make sure your phone is NOT connected)9600...
BLE: AT
trying to detect Bluetooth 4.0/BLE (HM-10 module) (make sure your phone is NOT connected)115200...
BLE: AT
error: no BLE module found!
ENABLE_PASS
ENABLE_TILT_DETECTION
FREEWHEEL_IS_AT_BACKSIDE: 1
WHEEL_BASE_CM: 36
WHEEL_DIAMETER: 260
ENABLE_ODOMETRY_ERROR_DETECTION: 0
TICKS_PER_REVOLUTION: 525
MOTOR_FAULT_CURRENT: 6.00
MOTOR_OVERLOAD_CURRENT: 1.00
USE_LINEAR_SPEED_RAMP: 1
MOTOR_PID_KP: 2.00
MOTOR_PID_KI: 0.03
MOTOR_PID_KD: 0.03
MOW_PWM: 200
MOW_FAULT_CURRENT: 8.00
MOW_OVERLOAD_CURRENT: 2.00
ENABLE_OVERLOAD_DETECTION: 1
ENABLE_FAULT_DETECTION: 1
ENABLE_FAULT_OBSTACLE_AVOIDANCE: 0
ENABLE_RPM_FAULT_DETECTION: 0
SONAR_INSTALLED
SONAR_ENABLE: 0
SONAR_TRIGGER_OBSTACLES: 1
RAIN_ENABLE: 0
BUMPER_ENABLE: 0
BUMPER_DEADTIME: 500
BUMPER_TRIGGER_DELAY: 10
BUMPER_MAX_TRIGGER_TIME: 30
CURRENT_FACTOR: 0.50
GO_HOME_VOLTAGE: 21.50
BAT_FULL_VOLTAGE: 28.70
BAT_FULL_CURRENT: 0.20
BAT_SWITCH_OFF_IDLE: 1
BAT_SWITCH_OFF_UNDERVOLTAGE: 1
REQUIRE_VALID_GPS: 1
GPS_SPEED_DETECTION: 1
GPS_MOTION_DETECTION: 1
GPS_REBOOT_RECOVERY: 1
GPS_CONFIG: 1
GPS_CONFIG_FILTER: 1
CPG_CONFIG_FILTER_MINELEV: 10
CPG_CONFIG_FILTER_NCNOTHRS: 10
CPG_CONFIG_FILTER_CNOTHRS: 25
ALLOW_ROUTE_OUTSIDE_PERI_METER: 1.00
OBSTACLE_DETECTION_ROTATION: 0
KIDNAP_DETECT: 1
KIDNAP_DETECT_ALLOWED_PATH_TOLERANCE: 2.00
DOCKING_STATION: 1
DOCK_IGNORE_GPS: 1
DOCK_AUTO_START: 0
TARGET_REACHED_TOLERANCE: 0.10
STANLEY_CONTROL_P_NORMAL: 3.40
STANLEY_CONTROL_K_NORMAL: 2.30
STANLEY_CONTROL_P_SLOW: 1.00
STANLEY_CONTROL_K_SLOW: 0.05
BUTTON_CONTROL: 1
USE_TEMP_SENSOR: 0
BUZZER_ENABLE
SERIAL_BUFFER_SIZE=1024 (increase if you experience GPS checksum errors)
-----------------------------------------------------
UBLOX::begin serial
using gps driver: UBLOX
trying to connect to ublox f9p...
NOTE: if GPS is not responding either set 'GPS_CONFIG=false' in config.h or perform GPS wire fix (see Wiki)
trying baud 115200
ERROR: GPS receiver is not responding
trying baud 38400
ERROR: GPS receiver is not responding
trying baud 115200
ERROR: GPS receiver is not responding
trying baud 38400
GPS receiver found!
ublox f9p: sending GPS rover configuration...
idx=0...OK
idx=1...OK
idx=2...OK
config sent successfully
sizeof Point=4
map load... ok
map dump - mapCRC=-227592
points: 
perimeter pts: 30
exclusion pts: 5
exclusions: 1
dock pts: 8
mow pts: 233
first mow point:-1.81,0.22
free pts: 0
mowPointsIdx=0 dockPointsIdx=0 freePointsIdx=0 wayMode=3
probing for ESP8266 (NOTE: will fail for ESP32)...
WIFI (ESP8266) not found! If you have ESP8266 and the problem persist, you may need to flash your ESP to firmware 2.2.1
resuming is activated
state load... ok
dumpState:  X=0.00 Y=0.00 delta=0.00 mapCRC=-227592 mowPointsIdx=0 dockPointsIdx=0 freePointsIdx=0 wayMode=3 op=0 sensor=0 sonar.enabled=0 fixTimeout=0 absolutePosSource=0 lon=0.00 lat=0.00 mowPwm=200 finishAndRestart=0 motorMowForwardSet=1
timetable (UTC times)    00 01 02 03 04 05 06 07 08 09 10 11 12 13 14 15 16 17 18 19 20 21 22 23 
timetable (UTC times) mon                            *  *  *  *  *  *  *  *  *  *  *             
timetable (UTC times) tue                            *  *  *  *  *  *  *  *  *  *  *             
timetable (UTC times) wed                            *  *  *  *  *  *  *  *  *  *  *             
timetable (UTC times) thu                            *  *  *  *  *  *  *  *  *  *  *             
timetable (UTC times) fri                            *  *  *  *  *  *  *  *  *  *  *             
timetable (UTC times) sat                            *  *  *  *  *  *  *  *  *  *  *             
timetable (UTC times) sun                            *  *  *  *  *  *  *  *  *  *  *             
* means mowing allowed
current GPS UTC weektime: dayOfWeek=mon  hour=0
timetable enabled: 0
mowing allowed: 1
WARN: PID unmet cycle time Ta=18.31 TaMax=0.20
batTemp=998  cpuTemp=36
GPS time (UTC): dayOfWeek=sun  hour=0
AUTOSTOP: timetable is disabled
AUTOSTART: not defined DOCK_AUTO_START
sending encryptMode=1 encryptChallenge=17
COMM CRC ERROR: ?R)Q*.v/1
0:0:27 ctlDur=0.00 op= freem=236579 sp=20000078 bat=0.00,0.000(0.00) chg=0.00,0(0.00) diff=0.000 tg=-1.81,0.22 x=0.00 y=0.00 delta=0.00 tow=3200 lon=0.00000000 lat=0.00000000 h=0.0 n=0.00 e=0.00 d=0.00 sol=0 age=27.94
WARNING - LoopTime: 27936 - 27936 - 279.36 - 27936ms
ublox chka error, msgclass=1, msgid=3C, msglen=40: 0!=3
0:0:32 ctlDur=0.02 op= freem=236579 sp=2000197C bat=27.72,0.000(0.00) chg=0.19,0(0.01) diff=-12.479 tg=-1.81,0.22 x=0.00 y=0.00 delta=0.00 tow=137344400 lon=0.00000000 lat=0.00000000 h=0.0 n=0.00 e=0.00 d=0.00 sol=0 age=32.93
0:0:37 ctlDur=0.02 op= freem=236579 sp=2000197C bat=27.70,-0.000(0.01) chg=0.18,0(0.01) diff=-21.850 tg=-1.81,0.22 x=0.00 y=0.00 delta=0.00 tow=137349400 lon=0.00000000 lat=0.00000000 h=0.0 n=0.00 e=0.00 d=0.00 sol=0 age=37.94
Info - LoopTime: 20 - 2 - 3.06 - 20ms
0:0:42 ctlDur=0.02 op= freem=236579 sp=2000197C bat=27.69,-0.000(0.00) chg=0.18,0(0.01) diff=-25.356 tg=-1.81,0.22 x=0.00 y=0.00 delta=0.00 tow=137354400 lon=0.00000000 lat=0.00000000 h=0.0 n=0.00 e=0.00 d=0.00 sol=0 age=42.93
0:0:47 ctlDur=0.02 op= freem=236579 sp=2000197C bat=27.69,-0.000(0.01) chg=0.18,0(0.01) diff=-26.689 tg=-1.81,0.22 x=0.00 y=0.00 delta=0.00 tow=137359400 lon=13.xxxxxxxx lat=52.xxxxxxxx h=227.5 n=0.00 e=0.00 d=0.00 sol=0 age=47.93
Info - LoopTime: 2 - 2 - 2.92 - 7ms
0:0:52 ctlDur=0.02 op= freem=236579 sp=2000197C bat=27.68,-0.000(0.02) chg=0.18,0(0.01) diff=-27.197 tg=-1.81,0.22 x=0.00 y=0.00 delta=0.00 tow=137364400 lon=13.xxxxxxxx lat=52.xxxxxxxx h=227.5 n=0.00 e=0.00 d=0.00 sol=0 age=52.93
GPS time (UTC): dayOfWeek=mon  hour=14
AUTOSTOP: timetable is disabled
AUTOSTART: not defined DOCK_AUTO_START
0:0:57 ctlDur=0.02 op= freem=236579 sp=2000197C bat=27.68,-0.001(0.01) chg=0.18,0(0.01) diff=-27.386 tg=-1.81,0.22 x=0.00 y=0.00 delta=0.00 tow=137369200 lon=13.xxxxxxxx lat=52.xxxxxxxx h=227.5 n=0.00 e=0.00 d=0.00 sol=0 age=57.93
Info - LoopTime: 3 - 2 - 2.92 - 7ms
0:1:2 ctlDur=0.02 op= freem=236579 sp=20000078 bat=27.68,-0.001(0.01) chg=0.18,0(0.01) diff=-27.456 tg=-1.81,0.22 x=0.00 y=0.00 delta=0.00 tow=137374200 lon=13.xxxxxxxx lat=52.xxxxxxxx h=227.5 n=0.00 e=0.00 d=0.00 sol=0 age=62.94
0:1:7 ctlDur=0.02 op= freem=236579 sp=2000197C bat=27.68,-0.001(0.00) chg=0.19,0(0.01) diff=-27.479 tg=-1.81,0.22 x=0.01 y=0.00 delta=0.00 tow=137375000 lon=13.xxxxxxxx lat=52.xxxxxxxx h=227.5 n=0.00 e=0.00 d=0.00 sol=0 age=67.94
Info - LoopTime: 3 - 2 - 2.93 - 7ms
sending encryptMode=1 encryptChallenge=17
0:1:12 ctlDur=0.02 op= freem=236227 sp=2000197C bat=27.68,-0.001(0.02) chg=0.18,0(0.01) diff=-27.492 tg=-1.81,0.22 x=0.01 y=0.00 delta=0.00 tow=137375000 lon=13.xxxxxxxx lat=52.xxxxxxxx h=227.5 n=0.00 e=0.00 d=0.00 sol=0 age=72.94
0:1:17 ctlDur=0.02 op= freem=236227 sp=2000197C bat=27.68,-0.001(0.01) chg=0.18,0(0.01) diff=-27.494 tg=-1.81,0.22 x=0.01 y=0.00 delta=0.00 tow=137375000 lon=13.xxxxxxxx lat=52.xxxxxxxx h=227.5 n=0.00 e=0.00 d=0.00 sol=0 age=77.95
Info - LoopTime: 22 - 2 - 3.08 - 22ms
sending encryptMode=1 encryptChallenge=17
0:1:22 ctlDur=0.02 op= freem=236227 sp=2000197C bat=27.68,-0.001(0.01) chg=0.18,0(0.01) diff=-27.491 tg=-1.81,0.22 x=0.01 y=0.00 delta=0.00 tow=137375000 lon=13.xxxxxxxx lat=52.xxxxxxxx h=227.5 n=0.00 e=0.00 d=0.00 sol=0 age=82.95
batTemp=998  cpuTemp=37
GPS time (UTC): dayOfWeek=mon  hour=14
AUTOSTOP: timetable is disabled
AUTOSTART: not defined DOCK_AUTO_START
0:1:27 ctlDur=0.02 op= freem=236227 sp=20000078 bat=27.68,-0.001(0.02) chg=0.19,0(0.01) diff=-27.490 tg=-1.81,0.22 x=0.01 y=0.00 delta=0.00 tow=137375000 lon=13.xxxxxxxx lat=52.xxxxxxxx h=227.5 n=0.00 e=0.00 d=0.00 sol=0 age=87.96
Info - LoopTime: 2 - 2 - 3.96 - 102ms
0:1:32 ctlDur=0.02 op= freem=236227 sp=2000197C bat=27.67,-0.001(0.00) chg=0.19,0(0.01) diff=-27.490 tg=-1.81,0.22 x=0.01 y=0.00 delta=0.00 tow=137375000 lon=13.xxxxxxxx lat=52.xxxxxxxx h=227.5 n=0.00 e=0.00 d=0.00 sol=0 age=92.96
0:1:37 ctlDur=0.02 op= freem=236227 sp=2000197C bat=27.67,-0.001(0.01) chg=0.19,0(0.01) diff=-27.489 tg=-1.81,0.22 x=0.01 y=0.00 delta=0.00 tow=137375000 lon=13.xxxxxxxx lat=52.xxxxxxxx h=227.5 n=0.00 e=0.00 d=0.00 sol=0 age=97.96
Info - LoopTime: 3 - 2 - 3.06 - 22ms
0:1:42 ctlDur=0.02 op= freem=236227 sp=2000197C bat=27.67,-0.001(0.00) chg=0.20,0(0.01) diff=-27.484 tg=-1.81,0.22 x=0.01 y=0.00 delta=0.00 tow=137375000 lon=13.xxxxxxxx lat=52.xxxxxxxx h=227.5 n=0.00 e=0.00 d=0.00 sol=0 age=102.96
0:1:47 ctlDur=0.02 op= freem=236227 sp=2000197C bat=27.67,-0.001(0.01) chg=0.18,0(0.01) diff=-27.483 tg=-1.81,0.22 x=0.01 y=0.00 delta=0.00 tow=137375000 lon=13.xxxxxxxx lat=52.xxxxxxxx h=227.5 n=0.00 e=0.00 d=0.00 sol=0 age=107.96
Info - LoopTime: 3 - 2 - 3.06 - 21ms
sending encryptMode=1 encryptChallenge=17
absolutePosSource=1 lon=13.xxxxxxxx lat=52.xxxxxxxx
dumpState:  X=0.01 Y=0.00 delta=0.00 mapCRC=-227592 mowPointsIdx=0 dockPointsIdx=0 freePointsIdx=0 wayMode=3 op=0 sensor=0 sonar.enabled=0 fixTimeout=0 absolutePosSource=1 lon=13.xx lat=52.xx mowPwm=200 finishAndRestart=0 motorMowForwardSet=1
save state... ok
0:1:52 ctlDur=0.02 op= freem=236227 sp=2000197C bat=27.67,-0.001(0.00) chg=0.19,0(0.01) diff=-27.484 tg=-1.81,0.22 x=0.01 y=0.00 delta=0.00 tow=137375000 lon=13.xxxxxxxx lat=52.xxxxxxxx h=227.5 n=0.00 e=0.00 d=0.00 sol=0 age=112.96
GPS time (UTC): dayOfWeek=mon  hour=14
AUTOSTOP: timetable is disabled
AUTOSTART: not defined DOCK_AUTO_START
0:1:57 ctlDur=0.02 op= freem=236227 sp=2000197C bat=27.67,-0.001(0.01) chg=0.20,0(0.01) diff=-27.481 tg=-1.81,0.22 x=0.01 y=0.00 delta=0.00 tow=137375000 lon=13.xxxxxxxx lat=52.xxxxxxxx h=227.5 n=0.00 e=0.00 d=0.00 sol=0 age=117.96
Info - LoopTime: 3 - 2 - 3.05 - 20ms
0:2:2 ctlDur=0.02 op= freem=236227 sp=2000197C bat=27.67,-0.001(0.01) chg=0.19,0(0.01) diff=-27.480 tg=-1.81,0.22 x=0.01 y=0.00 delta=0.00 tow=137375000 lon=13.xxxxxxxx lat=52.xxxxxxxx h=227.5 n=0.00 e=0.00 d=0.00 sol=0 age=122.96
0:2:7 ctlDur=0.02 op= freem=236227 sp=2000197C bat=27.67,-0.001(0.00) chg=0.18,0(0.01) diff=-27.478 tg=-1.81,0.22 x=0.01 y=0.00 delta=0.00 tow=137375000 lon=13.xxxxxxxx lat=52.xxxxxxxx h=227.5 n=0.00 e=0.00 d=0.00 sol=0 age=127.96
Info - LoopTime: 3 - 2 - 2.93 - 19ms
0:2:12 ctlDur=0.02 op= freem=236227 sp=2000197C bat=27.67,-0.001(0.00) chg=0.19,0(0.01) diff=-27.475 tg=-1.81,0.22 x=0.01 y=0.00 delta=0.00 tow=137375000 lon=13.xxxxxxxx lat=52.xxxxxxxx h=227.5 n=0.00 e=0.00 d=0.00 sol=0 age=132.96
0:2:17 ctlDur=0.02 op= freem=236227 sp=2000197C bat=27.67,-0.001(0.01) chg=0.19,0(0.01) diff=-27.474 tg=-1.81,0.22 x=0.01 y=0.00 delta=0.00 tow=137375000 lon=13.xxxxxxxx lat=52.xxxxxxxx h=227.5 n=0.00 e=0.00 d=0.00 sol=0 age=137.97
Info - LoopTime: 2 - 2 - 3.05 - 21ms
0:2:22 ctlDur=0.02 op= freem=236227 sp=2000197C bat=27.67,-0.001(0.01) chg=0.19,0(0.01) diff=-27.474 tg=-1.81,0.22 x=0.01 y=0.00 delta=0.00 tow=137375000 lon=13.xxxxxxxx lat=52.xxxxxxxx h=227.5 n=0.00 e=0.00 d=0.00 sol=0 age=142.98
batTemp=998  cpuTemp=37
GPS time (UTC): dayOfWeek=mon  hour=14
AUTOSTOP: timetable is disabled
AUTOSTART: not defined DOCK_AUTO_START
0:2:27 ctlDur=0.02 op= freem=236227 sp=2000197C bat=27.67,-0.001(0.01) chg=0.20,0(0.01) diff=-27.472 tg=-1.81,0.22 x=0.01 y=0.00 delta=0.00 tow=137375000 lon=13.xxxxxxxx lat=52.xxxxxxxx h=227.5 n=0.00 e=0.00 d=0.00 sol=0 age=147.97
Info - LoopTime: 3 - 2 - 3.84 - 103ms
0:2:32 ctlDur=0.02 op= freem=236227 sp=2000197C bat=27.67,-0.001(0.00) chg=0.20,0(0.01) diff=-27.472 tg=-1.81,0.22 x=0.01 y=0.00 delta=0.00 tow=137375000 lon=13.xxxxxxxx lat=52.xxxxxxxx h=227.5 n=0.00 e=0.00 d=0.00 sol=0 age=152.98
0:2:37 ctlDur=0.02 op= freem=236227 sp=2000197C bat=27.67,-0.001(0.01) chg=0.21,0(0.01) diff=-27.469 tg=-1.81,0.22 x=0.01 y=0.00 delta=0.00 tow=137375000 lon=13.xxxxxxxx lat=52.xxxxxxxx h=227.5 n=0.00 e=0.00 d=0.00 sol=0 age=157.98
Info - LoopTime: 3 - 2 - 3.06 - 21ms
0:2:42 ctlDur=0.02 op= freem=236227 sp=2000197C bat=27.66,-0.001(0.02) chg=0.20,0(0.01) diff=-27.467 tg=-1.81,0.22 x=0.01 y=0.00 delta=0.00 tow=137375000 lon=13.xxxxxxxx lat=52.xxxxxxxx h=227.5 n=0.00 e=0.00 d=0.00 sol=0 age=162.98
0:2:47 ctlDur=0.02 op= freem=236227 sp=2000197C bat=27.66,-0.001(0.00) chg=0.20,0(0.01) diff=-27.468 tg=-1.81,0.22 x=0.01 y=0.00 delta=0.00 tow=137375000 lon=13.xxxxxxxx lat=52.xxxxxxxx h=227.5 n=0.00 e=0.00 d=0.00 sol=0 age=167.99
Info - LoopTime: 2 - 2 - 3.05 - 21ms
0:2:52 ctlDur=0.02 op= freem=236227 sp=2000197C bat=27.66,-0.001(0.01) chg=0.19,0(0.01) diff=-27.465 tg=-1.81,0.22 x=0.01 y=0.00 delta=0.00 tow=137375000 lon=13.xxxxxxxx lat=52.xxxxxxxx h=227.5 n=0.00 e=0.00 d=0.00 sol=0 age=172.97
GPS time (UTC): dayOfWeek=mon  hour=14
AUTOSTOP: timetable is disabled
AUTOSTART: not defined DOCK_AUTO_START
0:2:57 ctlDur=0.02 op= freem=236227 sp=2000197C bat=27.66,-0.001(0.02) chg=0.19,0(0.01) diff=-27.466 tg=-1.81,0.22 x=0.01 y=0.00 delta=0.00 tow=137375000 lon=13.xxxxxxxx lat=52.xxxxxxxx h=227.5 n=0.00 e=0.00 d=0.00 sol=0 age=177.98
Info - LoopTime: 3 - 2 - 2.93 - 10ms
0:3:2 ctlDur=0.02 op= freem=236227 sp=2000197C bat=27.66,-0.001(0.00) chg=0.20,0(0.01) diff=-27.464 tg=-1.81,0.22 x=0.01 y=0.00 delta=0.00 tow=137375000 lon=13.xxxxxxxx lat=52.xxxxxxxx h=227.5 n=0.00 e=0.00 d=0.00 sol=0 age=182.98
0:3:7 ctlDur=0.02 op= freem=236227 sp=2000197C bat=27.66,-0.001(0.01) chg=0.20,0(0.01) diff=-27.462 tg=-1.81,0.22 x=0.01 y=0.00 delta=0.00 tow=137375000 lon=13.xxxxxxxx lat=52.xxxxxxxx h=227.5 n=0.00 e=0.00 d=0.00 sol=0 age=187.98
Info - LoopTime: 3 - 2 - 2.92 - 7ms
0:3:12 ctlDur=0.02 op= freem=236227 sp=2000197C bat=27.66,-0.001(0.01) chg=0.20,0(0.01) diff=-27.462 tg=-1.81,0.22 x=0.01 y=0.00 delta=0.00 tow=137375000 lon=13.xxxxxxxx lat=52.xxxxxxxx h=227.5 n=0.00 e=0.00 d=0.00 sol=0 age=192.99
0:3:17 ctlDur=0.02 op= freem=236227 sp=2000197C bat=27.66,-0.001(0.02) chg=0.20,0(0.01) diff=-27.461 tg=-1.81,0.22 x=0.01 y=0.00 delta=0.00 tow=137375000 lon=13.xxxxxxxx lat=52.xxxxxxxx h=227.5 n=0.00 e=0.00 d=0.00 sol=0 age=197.99
Info - LoopTime: 3 - 2 - 3.04 - 20ms


Code:
Test MPU9255 ######################################


SD card found!
RESET cause: power-on
Sunray,1.0.319
compiled for: Adafruit Grand Central M4
using robot driver: AmRobotDriver
robot id: 77:06:87:48:53:35:37:4e:36:20:20:20:ff:03:33:47
MOTOR_DRIVER_BRUSHLESS: no
enableCharging 0
probing for HM-10 module (NOTE: will fail for ESP32)...
trying to detect Bluetooth 4.0/BLE (HM-10 module) (make sure your phone is NOT connected)9600...
BLE: AT
trying to detect Bluetooth 4.0/BLE (HM-10 module) (make sure your phone is NOT connected)115200...
BLE: AT
error: no BLE module found!
ENABLE_PASS
ENABLE_TILT_DETECTION
FREEWHEEL_IS_AT_BACKSIDE: 1
WHEEL_BASE_CM: 36
WHEEL_DIAMETER: 260
ENABLE_ODOMETRY_ERROR_DETECTION: 0
TICKS_PER_REVOLUTION: 525
MOTOR_FAULT_CURRENT: 6.00
MOTOR_OVERLOAD_CURRENT: 1.00
USE_LINEAR_SPEED_RAMP: 1
MOTOR_PID_KP: 2.00
MOTOR_PID_KI: 0.03
MOTOR_PID_KD: 0.03
MOW_PWM: 200
MOW_FAULT_CURRENT: 8.00
MOW_OVERLOAD_CURRENT: 2.00
ENABLE_OVERLOAD_DETECTION: 1
ENABLE_FAULT_DETECTION: 1
ENABLE_FAULT_OBSTACLE_AVOIDANCE: 0
ENABLE_RPM_FAULT_DETECTION: 0
SONAR_INSTALLED
SONAR_ENABLE: 0
SONAR_TRIGGER_OBSTACLES: 1
RAIN_ENABLE: 0
BUMPER_ENABLE: 0
BUMPER_DEADTIME: 500
BUMPER_TRIGGER_DELAY: 10
BUMPER_MAX_TRIGGER_TIME: 30
CURRENT_FACTOR: 0.50
GO_HOME_VOLTAGE: 21.50
BAT_FULL_VOLTAGE: 28.70
BAT_FULL_CURRENT: 0.20
BAT_SWITCH_OFF_IDLE: 1
BAT_SWITCH_OFF_UNDERVOLTAGE: 1
REQUIRE_VALID_GPS: 1
GPS_SPEED_DETECTION: 1
GPS_MOTION_DETECTION: 1
GPS_REBOOT_RECOVERY: 1
GPS_CONFIG: 1
GPS_CONFIG_FILTER: 1
CPG_CONFIG_FILTER_MINELEV: 10
CPG_CONFIG_FILTER_NCNOTHRS: 10
CPG_CONFIG_FILTER_CNOTHRS: 25
ALLOW_ROUTE_OUTSIDE_PERI_METER: 1.00
OBSTACLE_DETECTION_ROTATION: 0
KIDNAP_DETECT: 1
KIDNAP_DETECT_ALLOWED_PATH_TOLERANCE: 2.00
DOCKING_STATION: 1
DOCK_IGNORE_GPS: 1
DOCK_AUTO_START: 0
TARGET_REACHED_TOLERANCE: 0.10
STANLEY_CONTROL_P_NORMAL: 3.40
STANLEY_CONTROL_K_NORMAL: 2.30
STANLEY_CONTROL_P_SLOW: 1.00
STANLEY_CONTROL_K_SLOW: 0.05
BUTTON_CONTROL: 1
USE_TEMP_SENSOR: 0
BUZZER_ENABLE
SERIAL_BUFFER_SIZE=1024 (increase if you experience GPS checksum errors)
-----------------------------------------------------
UBLOX::begin serial
using gps driver: UBLOX
trying to connect to ublox f9p...
NOTE: if GPS is not responding either set 'GPS_CONFIG=false' in config.h or perform GPS wire fix (see Wiki)
trying baud 115200
ERROR: GPS receiver is not responding
trying baud 38400
ERROR: GPS receiver is not responding
trying baud 115200
ERROR: GPS receiver is not responding
trying baud 38400
GPS receiver found!
ublox f9p: sending GPS rover configuration...
idx=0...OK
idx=1...OK
idx=2...OK
config sent successfully
sizeof Point=4
map load... ok
map dump - mapCRC=-334981
points: 
perimeter pts: 30
exclusion pts: 5
exclusions: 1
dock pts: 8
mow pts: 340
first mow point:-1.81,0.22
free pts: 0
mowPointsIdx=0 dockPointsIdx=0 freePointsIdx=0 wayMode=3
probing for ESP8266 (NOTE: will fail for ESP32)...
WIFI (ESP8266) not found! If you have ESP8266 and the problem persist, you may need to flash your ESP to firmware 2.2.173
MPU9255 found
using imu driver: MpuDriver
resuming is activated
state load... ok
dumpState:  X=0.12 Y=-0.11 delta=-0.79 mapCRC=-334981 mowPointsIdx=72 dockPointsIdx=1 freePointsIdx=1 wayMode=2 op=0 sensor=6 sonar.enabled=0 fixTimeout=60 absolutePosSource=1 lon=13.xx lat=52.xx mowPwm=200 finishAndRestart=0 motorMowForwardSet=1
timetable (UTC times)    00 01 02 03 04 05 06 07 08 09 10 11 12 13 14 15 16 17 18 19 20 21 22 23 
timetable (UTC times) mon                            *  *  *  *  *  *  *  *  *  *  *             
timetable (UTC times) tue                            *  *  *  *  *  *  *  *  *  *  *             
timetable (UTC times) wed                            *  *  *  *  *  *  *  *  *  *  *             
timetable (UTC times) thu                            *  *  *  *  *  *  *  *  *  *  *             
timetable (UTC times) fri                            *  *  *  *  *  *  *  *  *  *  *             
timetable (UTC times) sat                            *  *  *  *  *  *  *  *  *  *  *             
timetable (UTC times) sun                            *  *  *  *  *  *  *  *  *  *  *             
* means mowing allowed
current GPS UTC weektime: dayOfWeek=mon  hour=0
timetable enabled: 0
mowing allowed: 1
WARN: PID unmet cycle time Ta=12.16 TaMax=0.20
batTemp=998  cpuTemp=32
GPS time (UTC): dayOfWeek=sun  hour=0
AUTOSTOP: timetable is disabled
AUTOSTART: not defined DOCK_AUTO_START
==> changeOp:ImuCalibration(initiatedByOperator 0)->Idle
IMU gyro calibration (robot must be static)... 1
0:0:21 ctlDur=0.00 op=ImuCalibration(initiatedByOperator 0)->Idle freem=236751 sp=200000B0 bat=0.00,0.000(0.00) chg=0.00,0(0.00) diff=0.000 tg=-0.30,0.31 x=0.12 y=-0.11 delta=-0.79 tow=2200 lon=0.00000000 lat=0.00000000 h=0.0 n=0.00 e=0.00 d=0.00 sol=0 age=21.80
WARNING - LoopTime: 21795 - 21795 - 217.95 - 21795ms
ublox chka error, msgclass=1, msgid=3C, msglen=40: 12!=10
IMU gyro calibration (robot must be static)... 2
sending encryptMode=1 encryptChallenge=7
IMU gyro calibration (robot must be static)... 3
IMU gyro calibration (robot must be static)... 4
IMU gyro calibration (robot must be static)... 5
0:0:26 ctlDur=0.02 op=ImuCalibration(initiatedByOperator 0)->Idle freem=236011 sp=200019AC bat=27.66,0.000(0.00) chg=0.13,0(0.00) diff=-12.623 tg=-0.30,0.31 x=0.12 y=-0.11 delta=-0.79 tow=150231200 lon=0.00000000 lat=0.00000000 h=0.0 n=0.00 e=0.00 d=0.00 sol=0 age=26.80
IMU gyro calibration (robot must be static)... 6
IMU gyro calibration (robot must be static)... 7
IMU gyro calibration (robot must be static)... 8
IMU gyro calibration (robot must be static)... 9
IMU gyro calibration (robot must be static)... 10
0:0:31 ctlDur=0.02 op=ImuCalibration(initiatedByOperator 0)->Idle freem=235907 sp=200019AC bat=27.66,0.000(0.00) chg=0.14,0(0.00) diff=-21.905 tg=-0.30,0.31 x=0.12 y=-0.11 delta=-0.79 tow=150236200 lon=0.00000000 lat=0.00000000 h=0.0 n=0.00 e=0.00 d=0.00 sol=0 age=31.80
Info - LoopTime: 20 - 2 - 3.07 - 20ms
IMU gyro calibration (robot must be static)... 11
IMU gyro calibration (robot must be static)... 12
IMU gyro calibration (robot must be static)... 13
IMU gyro calibration (robot must be static)... 14
IMU gyro calibration (robot must be static)... 15
==> changeOp:Idle(initiatedByOperator 0)
OP_IDLE
Motor::setMowState 0
dumpState:  X=0.12 Y=-0.11 delta=-0.92 mapCRC=-334981 mowPointsIdx=72 dockPointsIdx=1 freePointsIdx=1 wayMode=4 op=0 sensor=6 sonar.enabled=0 fixTimeout=60 absolutePosSource=1 lon=13.xx lat=52.xx mowPwm=200 finishAndRestart=0 motorMowForwardSet=1
save state... ok
0:0:36 ctlDur=0.02 op=Idle(initiatedByOperator 0) freem=235907 sp=200019AC bat=27.66,0.000(0.00) chg=0.14,0(0.00) diff=-25.386 tg=-0.30,0.31 x=0.12 y=-0.11 delta=-0.92 tow=150241200 lon=-29.xxxxxxxx lat=64.xxxxxxxx h=17265.3 n=0.00 e=0.00 d=0.00 sol=0 age=36.80
0:0:41 ctlDur=0.02 op=Idle(initiatedByOperator 0) freem=235907 sp=200019AC bat=27.66,0.000(0.01) chg=0.13,0(0.00) diff=-26.720 tg=-0.30,0.31 x=0.12 y=-0.11 delta=-0.92 tow=150246200 lon=-6.xxxxxxxx lat=47.xxxxxxxx h=11456.1 n=0.00 e=0.00 d=0.00 sol=0 age=41.80
Info - LoopTime: 20 - 2 - 3.07 - 53ms
0:0:46 ctlDur=0.02 op=Idle(initiatedByOperator 0) freem=235907 sp=200019AC bat=27.66,0.000(0.02) chg=0.14,0(0.00) diff=-27.224 tg=-0.30,0.31 x=0.12 y=-0.11 delta=-0.92 tow=150251200 lon=-7.xxxxxxxx lat=47.xxxxxxxx h=11663.8 n=0.00 e=0.00 d=0.00 sol=0 age=46.80
GPS time (UTC): dayOfWeek=mon  hour=17
AUTOSTOP: timetable is disabled
AUTOSTART: not defined DOCK_AUTO_START
0:0:51 ctlDur=0.02 op=Idle(initiatedByOperator 0) freem=235907 sp=200019AC bat=27.66,0.000(0.01) chg=0.14,0(0.00) diff=-27.410 tg=-0.30,0.31 x=0.12 y=-0.11 delta=-0.92 tow=150256200 lon=-6.xxxxxxxx lat=47.xxxxxxxx h=11665.8 n=0.00 e=0.00 d=0.00 sol=0 age=51.80
Info - LoopTime: 3 - 2 - 3.09 - 20ms
0:0:56 ctlDur=0.02 op=Idle(initiatedByOperator 0) freem=235907 sp=200019AC bat=27.66,0.000(0.00) chg=0.14,0(0.00) diff=-27.482 tg=-0.30,0.31 x=0.12 y=-0.11 delta=-0.92 tow=150261200 lon=13.xxxxxxxx lat=52.xxxxxxxx h=90.1 n=0.00 e=0.00 d=0.00 sol=0 age=0.04
GPS jump: 4.90
0:1:1 ctlDur=0.02 op=Idle(initiatedByOperator 0) freem=235907 sp=200019AC bat=27.66,0.000(0.00) chg=0.14,0(0.01) diff=-27.506 tg=-0.30,0.31 x=0.67 y=4.45 delta=-0.92 tow=150266200 lon=13.xxxxxxxx lat=52.xxxxxxxx h=90.4 n=-222.73 e=-4304.38 d=1.03 sol=1 age=0.28
Info - LoopTime: 22 - 1 - 3.09 - 22ms
0:1:6 ctlDur=0.02 op=Idle(initiatedByOperator 0) freem=235907 sp=200019AC bat=27.66,0.000(0.01) chg=0.14,0(0.00) diff=-27.517 tg=-0.30,0.31 x=0.24 y=3.93 delta=-0.92 tow=150271200 lon=13.xxxxxxxx lat=52.xxxxxxxx h=91.4 n=-223.27 e=-4304.80 d=0.05 sol=1 age=0.29
0:1:11 ctlDur=0.02 op=Idle(initiatedByOperator 0) freem=235907 sp=200019AC bat=27.66,-0.000(0.02) chg=0.14,0(0.00) diff=-27.519 tg=-0.30,0.31 x=-0.11 y=3.41 delta=-0.92 tow=150276000 lon=13.xxxxxxxx lat=52.xxxxxxxx h=92.0 n=-223.79 e=-4305.16 d=-0.54 sol=1 age=0.35
Info - LoopTime: 21 - 2 - 3.08 - 22ms


THX

Martin
 
The ICM is not being detected.

Can you double check its properly wired?
Also, seems like the pimoroni defaults to 0x68, you might need to cut the trace on the back. Did you have to do this @Algo?
 
The ICM is not being detected.

Can you double check its properly wired?
Also, seems like the pimoroni defaults to 0x68, you might need to cut the trace on the back. Did you have to do this @Algo?
Nein hab ich nicht gemacht, ist wie ich es oben beschrieben habe angeschlossen. Nur Power, SCL, SDA und GND. Int bleibt unbelegt, ADO gibts ja nicht also auch nichts.
0x68 ist standard vom Pomidori.


Hallo zusammen,

ich hab mal testweise auch zwei ICM20948 bestellt und wie beschrieben verlötet. AD0 gibt es beim ICM20948 nicht... also auch keine Brücke.
Die Einstellung auf ICM20948 in der config.h wurde in der Sunray 1.0.322 durchgeführt.
An den Jumpern auf dem v1.3 Board wurde nichts verändert (bleibt bei 3,3V)

Die Firmware lässt sich übertragen, aber wenn es an den Start geht, bekomme ich an der Stelle wo normaler weise die Kalibrierung läuft und mit Piepsen bestätigt wird einen "COMM CRC Error"

Wieder zurück auf die MPU6050 oder MPU9255 laufen beide sauber durch.

Da beide gekauften ICM20948 (von BerryBase) das gleiche Verhalten zeigen, möchte ich einen Hardwaredefekt erstmal ausschließen.

In welche Richtung kann ich noch suchen?

Besten Dank schonmal für Eure Hilfe

Martin

Mh muss ich mal in meine Console schauen ob ich auch den Fehler mit dem CRC habe.
Die 15 Pipser beim Start habe ich auch nicht, nur einen, dachte aber dass das vielleicht aus dem Code genommen wurde, ganz früher bei Sunray waren es irgendwann mal 10.
 
@WhatATest
Big Thanks ;)

Auf der Rückseite des Pimoroni Boards gibt es eine Brücke die mit "ADDR+1" beschriftet ist. Die dünne Verbindung lässt sich mit einem Skalpell durchtrennen. Und ab dann funktioniert alles ohne weitere Anpassung in der lcmDriver.cpp und die Kalibrierung läuft auch mit 15x piepsen durch.

Ergebnis:

Code:
SD card found!
RESET cause: software
Sunray,1.0.319
compiled for: Adafruit Grand Central M4
using robot driver: AmRobotDriver
robot id: 77:06:87:48:53:35:37:4e:36:20:20:20:ff:03:33:47
MOTOR_DRIVER_BRUSHLESS: no
enableCharging 0
probing for HM-10 module (NOTE: will fail for ESP32)...
trying to detect Bluetooth 4.0/BLE (HM-10 module) (make sure your phone is NOT connected)9600...
BLE: AT
trying to detect Bluetooth 4.0/BLE (HM-10 module) (make sure your phone is NOT connected)115200...
BLE: AT
error: no BLE module found!
ENABLE_PASS
ENABLE_TILT_DETECTION
FREEWHEEL_IS_AT_BACKSIDE: 1
WHEEL_BASE_CM: 36
WHEEL_DIAMETER: 260
ENABLE_ODOMETRY_ERROR_DETECTION: 0
TICKS_PER_REVOLUTION: 525
MOTOR_FAULT_CURRENT: 3.00
MOTOR_OVERLOAD_CURRENT: 1.00
USE_LINEAR_SPEED_RAMP: 1
MOTOR_PID_KP: 2.00
MOTOR_PID_KI: 0.03
MOTOR_PID_KD: 0.03
MOW_PWM: 220
MOW_FAULT_CURRENT: 6.00
MOW_OVERLOAD_CURRENT: 3.00
ENABLE_OVERLOAD_DETECTION: 1
ENABLE_FAULT_DETECTION: 1
ENABLE_FAULT_OBSTACLE_AVOIDANCE: 0
ENABLE_RPM_FAULT_DETECTION: 0
SONAR_INSTALLED
SONAR_ENABLE: 0
SONAR_TRIGGER_OBSTACLES: 0
RAIN_ENABLE: 0
BUMPER_ENABLE: 0
BUMPER_DEADTIME: 50
BUMPER_TRIGGER_DELAY: 50
BUMPER_MAX_TRIGGER_TIME: 30
CURRENT_FACTOR: 0.50
GO_HOME_VOLTAGE: 21
BAT_FULL_VOLTAGE: 28.00
BAT_FULL_CURRENT: 0.40
BAT_SWITCH_OFF_IDLE: 1
BAT_SWITCH_OFF_UNDERVOLTAGE: 1
REQUIRE_VALID_GPS: 1
GPS_SPEED_DETECTION: 1
GPS_MOTION_DETECTION: 1
GPS_REBOOT_RECOVERY: 1
GPS_CONFIG: 1
GPS_CONFIG_FILTER: 1
CPG_CONFIG_FILTER_MINELEV: 8
CPG_CONFIG_FILTER_NCNOTHRS: 8
CPG_CONFIG_FILTER_CNOTHRS: 20
ALLOW_ROUTE_OUTSIDE_PERI_METER: 1.00
OBSTACLE_DETECTION_ROTATION: 0
KIDNAP_DETECT: 1
KIDNAP_DETECT_ALLOWED_PATH_TOLERANCE: 2.00
DOCKING_STATION: 1
DOCK_IGNORE_GPS: 1
DOCK_AUTO_START: 0
TARGET_REACHED_TOLERANCE: 0.07
STANLEY_CONTROL_P_NORMAL: 3.40
STANLEY_CONTROL_K_NORMAL: 2.30
STANLEY_CONTROL_P_SLOW: 1.00
STANLEY_CONTROL_K_SLOW: 0.05
BUTTON_CONTROL: 1
USE_TEMP_SENSOR: 0
BUZZER_ENABLE
SERIAL_BUFFER_SIZE=1024 (increase if you experience GPS checksum errors)
-----------------------------------------------------
UBLOX::begin serial
using gps driver: UBLOX
trying to connect to ublox f9p...
NOTE: if GPS is not responding either set 'GPS_CONFIG=false' in config.h or perform GPS wire fix (see Wiki)
trying baud 115200
ERROR: GPS receiver is not responding
trying baud 38400
ERROR: GPS receiver is not responding
trying baud 115200
ERROR: GPS receiver is not responding
trying baud 38400
GPS receiver found!
ublox f9p: sending GPS rover configuration...
idx=0...OK
idx=1...OK
idx=2...OK
config sent successfully
sizeof Point=4
map load... ok
map dump - mapCRC=-275332
points:
perimeter pts: 38
exclusion pts: 5
exclusions: 1
dock pts: 9
mow pts: 289
first mow point:-1.81,0.22
free pts: 0
mowPointsIdx=0 dockPointsIdx=0 freePointsIdx=0 wayMode=3
probing for ESP8266 (NOTE: will fail for ESP32)...
WIFI (ESP8266) not found! If you have ESP8266 and the problem persist, you may need to flash your ESP to firmware 2.2.1
ICM 20948 found
using imu driver: IcmDriver
resuming is activated
state load... ok
dumpState:  X=0.12 Y=-0.11 delta=-0.75 mapCRC=-275332 mowPointsIdx=16 dockPointsIdx=3 freePointsIdx=3 wayMode=2 op=0 sensor=0 sonar.enabled=0 fixTimeout=60 absolutePosSource=1 lon=13.xx lat=52.xx mowPwm=255 finishAndRestart=0 motorMowForwardSet=0
timetable (UTC times)    00 01 02 03 04 05 06 07 08 09 10 11 12 13 14 15 16 17 18 19 20 21 22 23
timetable (UTC times) mon                            *  *  *  *  *  *  *  *  *  *  *            
timetable (UTC times) tue                            *  *  *  *  *  *  *  *  *  *  *            
timetable (UTC times) wed                            *  *  *  *  *  *  *  *  *  *  *            
timetable (UTC times) thu                            *  *  *  *  *  *  *  *  *  *  *            
timetable (UTC times) fri                            *  *  *  *  *  *  *  *  *  *  *            
timetable (UTC times) sat                            *  *  *  *  *  *  *  *  *  *  *            
timetable (UTC times) sun                            *  *  *  *  *  *  *  *  *  *  *            
* means mowing allowed
current GPS UTC weektime: dayOfWeek=mon  hour=0
timetable enabled: 0
mowing allowed: 1
WARN: PID unmet cycle time Ta=13.00 TaMax=0.20
WARN: PID unmet cycle time Ta=13.01 TaMax=0.20

==> changeOp:ImuCalibration(initiatedByOperator 0)->Idle
IMU gyro calibration (robot must be static)... 1
IMU gyro calibration (robot must be static)... 2
IMU gyro calibration (robot must be static)... 3
IMU gyro calibration (robot must be static)... 4
IMU gyro calibration (robot must be static)... 5
IMU gyro calibration (robot must be static)... 6
IMU gyro calibration (robot must be static)... 7
IMU gyro calibration (robot must be static)... 8
IMU gyro calibration (robot must be static)... 9
IMU gyro calibration (robot must be static)... 10
IMU gyro calibration (robot must be static)... 11
IMU gyro calibration (robot must be static)... 12
IMU gyro calibration (robot must be static)... 13
IMU gyro calibration (robot must be static)... 14
IMU gyro calibration (robot must be static)... 15
==> changeOp:Idle(initiatedByOperator 0)
OP_IDLE
IdleOp::begin switch off all motors
Motor::setMowState PWM OFFdumpState:  X=0.12 Y=-0.11 delta=-1.63 mapCRC=-275332 mowPointsIdx=16 dockPointsIdx=3 freePointsIdx=3 wayMode=4 op=0 sensor=0 sonar.enabled=0 fixTimeout=60 absolutePosSource=1 lon=13.xx lat=52.xx mowPwm=255 finishAndRestart=0 motorMowForwardSet=0
save state... ok
 
Zuletzt bearbeitet:
Mh muss ich mal in meine Console schauen ob ich auch den Fehler mit dem CRC habe.
Die 15 Pipser beim Start habe ich auch nicht, nur einen, dachte aber dass das vielleicht aus dem Code genommen wurde, ganz früher bei Sunray waren es irgendwann mal 10.
Also ich habe diese Ausgabe in der Console hier ist kein CRC Fehler:
Mh dann läuft mein Mäher scheinbar grad ohne IMU, in der config habe ich 0x69 stehen (könnte schwören das war 0x68) :confused:
Dann schneide ich auch mal die Verbindung durch...
War einfach nur glücklich, dass mein Mäher mal ohne die MPU6050 endlich wieder ordentlich gefahren ist, dachte daher es funktioniert alles mit der neuen ICM, das mit dem Pipsen führte ich auf eventuelle Codeänderungen zurück, weil es ja in der Vergangenheit auch schon Änderungen gegeben hatte.

Code:
SD card found!
RESET cause: power-on
Sunray,1.0.318
compiled for: Adafruit Grand Central M4
using robot driver: AmRobotDriver
robot id: 3c:59:7b:14:53:50:53:38:4a:20:20:20:ff:15:35:2e
MOTOR_DRIVER_BRUSHLESS: yes
enableCharging 0
probing for HM-10 module (NOTE: will fail for ESP32)...
trying to detect Bluetooth 4.0/BLE (HM-10 module) (make sure your phone is NOT connected)9600...
BLE: AT
trying to detect Bluetooth 4.0/BLE (HM-10 module) (make sure your phone is NOT connected)115200...
BLE: AT
AT+V,0x16
error: no BLE module found!
rcmodel.cpp RCModel::begin  RC-Mode enabled in config
FREEWHEEL_IS_AT_BACKSIDE: 1
WHEEL_BASE_CM: 64
WHEEL_DIAMETER: 295
ENABLE_ODOMETRY_ERROR_DETECTION: 0
TICKS_PER_REVOLUTION: 2210
MOTOR_DRIVER_BRUSHLESS
MOTOR_DRIVER_BRUSHLESS_MOW_JYQD
MOTOR_DRIVER_BRUSHLESS_GEARS_JYQD
MOTOR_FAULT_CURRENT: 8.00
MOTOR_OVERLOAD_CURRENT: 8.00
USE_LINEAR_SPEED_RAMP: 0
MOTOR_PID_KP: 1.80
MOTOR_PID_KI: 0.01
MOTOR_PID_KD: 0.01
MOTOR_LEFT_SWAP_DIRECTION
MOTOR_RIGHT_SWAP_DIRECTION
MAX_MOW_PWM: 175
MOW_FAULT_CURRENT: 8.00
MOW_OVERLOAD_CURRENT: 10.00
ENABLE_OVERLOAD_DETECTION: 0
ENABLE_FAULT_DETECTION: 0
ENABLE_FAULT_OBSTACLE_AVOIDANCE: 0
ENABLE_RPM_FAULT_DETECTION: 0
SONAR_INSTALLED
SONAR_ENABLE: 0
SONAR_TRIGGER_OBSTACLES: 0
RAIN_ENABLE: 0
BUMPER_ENABLE: 0
BUMPER_DEADTIME: 1000
BUMPER_TRIGGER_DELAY: 300
BUMPER_MAX_TRIGGER_TIME: 30
CURRENT_FACTOR: 2.94
GO_HOME_VOLTAGE: 21.00
BAT_FULL_VOLTAGE: 29.00
BAT_FULL_CURRENT: 0.10
BAT_SWITCH_OFF_IDLE: 0
BAT_SWITCH_OFF_UNDERVOLTAGE: 0
REQUIRE_VALID_GPS: 1
GPS_SPEED_DETECTION: 1
GPS_MOTION_DETECTION: 1
GPS_REBOOT_RECOVERY: 1
GPS_CONFIG: 1
GPS_CONFIG_FILTER: 1
CPG_CONFIG_FILTER_MINELEV: 10
CPG_CONFIG_FILTER_NCNOTHRS: 10
CPG_CONFIG_FILTER_CNOTHRS: 30
ALLOW_ROUTE_OUTSIDE_PERI_METER: 0.10
OBSTACLE_DETECTION_ROTATION: 1
KIDNAP_DETECT: 0
KIDNAP_DETECT_ALLOWED_PATH_TOLERANCE: 1.00
DOCKING_STATION: 0
DOCK_IGNORE_GPS: 0
DOCK_AUTO_START: 0
TARGET_REACHED_TOLERANCE: 0.10
STANLEY_CONTROL_P_NORMAL: 0.40
STANLEY_CONTROL_K_NORMAL: 0.04
STANLEY_CONTROL_P_SLOW: 0.40
STANLEY_CONTROL_K_SLOW: 0.04
BUTTON_CONTROL: 1
USE_TEMP_SENSOR: 0
BUZZER_ENABLE
SERIAL_BUFFER_SIZE=1024 (increase if you experience GPS checksum errors)
-----------------------------------------------------
UBLOX::begin serial
using gps driver: UBLOX
trying to connect to ublox f9p...
NOTE: if GPS is not responding either set 'GPS_CONFIG=false' in config.h or perform GPS wire fix (see Wiki)
trying baud 115200
GPS receiver found!
ublox f9p: sending GPS rover configuration...
idx=0...OK
idx=1...OK
idx=2...OK
config sent successfully
sizeof Point=4
map load... ok
map dump - mapCRC=-968523
points:
perimeter pts: 235
exclusion pts: 74
exclusions: 6
dock pts: 0
mow pts: 293
first mow point:-33.40,-3.06
free pts: 0
mowPointsIdx=0 dockPointsIdx=0 freePointsIdx=0 wayMode=3
probing for ESP8266 (NOTE: will fail for ESP32)...
WIFI (ESP8266) not found! If you have ESP8266 and the problem persist, you may need to flash your ESP to firmware 2.2.1
resuming is activated
state load... ok
dumpState:  X=-36.35 Y=-2.64 delta=1.66 mapCRC=-968523 mowPointsIdx=258 dockPointsIdx=1 freePointsIdx=1 wayMode=4 op=0 sensor=17 sonar.enabled=0 fixTimeout=60 absolutePosSource=0 lon=0.00 lat=0.00 pwmMaxMow=139 finishAndRestart=0 motorMowForwardSet=0
timetable (UTC times)    00 01 02 03 04 05 06 07 08 09 10 11 12 13 14 15 16 17 18 19 20 21 22 23
timetable (UTC times) mon                            *  *  *  *  *  *  *  *  *  *  *         
timetable (UTC times) tue                            *  *  *  *  *  *  *  *  *  *  *         
timetable (UTC times) wed                            *  *  *  *  *  *  *  *  *  *  *         
timetable (UTC times) thu                            *  *  *  *  *  *  *  *  *  *  *         
timetable (UTC times) fri                            *  *  *  *  *  *  *  *  *  *  *         
timetable (UTC times) sat                            *  *  *  *  *  *  *  *  *  *  *         
timetable (UTC times) sun                            *  *  *  *  *  *  *  *  *  *  *         
* means mowing allowed
current GPS UTC weektime: dayOfWeek=mon  hour=0
timetable enabled: 0
mowing allowed: 1
WARN: PID unmet cycle time Ta=8.84 TaMax=0.10
batTemp=998  cpuTemp=22
GPS time (UTC): dayOfWeek=sun  hour=13
AUTOSTOP: timetable is disabled
AUTOSTART: not defined DOCKING_STATION
sending encryptMode=0 encryptChallenge=0
0:0:16 ctlDur=0.00 freem=211291 sp=20000068 bat=0.00,0.000(0.01) chg=0.00,0(0.00) diff=0.000 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=47862400 lon=0.00000000 lat=0.00000000 h=0.0 n=0.00 e=0.00 d=0.00 sol=0 age=0.01
WARNING - LoopTime: 16938 - 16938 - 169.38 - 16938ms
ublox chka error, msgclass=1, msgid=12, msglen=24: 0!=1
sending encryptMode=0 encryptChallenge=0
absolutePosSource=0 lon=0.00000000 lat=0.00000000
0:0:21 ctlDur=0.02 freem=211187 sp=2000185C bat=26.53,0.000(0.42) chg=0.08,0(0.01) diff=-12.270 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=47870800 lon=44.39779344 lat=54.01761831 h=13962.1 n=0.00 e=0.00 d=0.00 sol=0 age=0.36
0:0:26 ctlDur=0.02 freem=211187 sp=2000185C bat=26.52,0.000(0.72) chg=0.11,0(0.01) diff=-21.251 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=47875800 lon=44.39751004 lat=54.00274901 h=13956.9 n=0.00 e=0.00 d=0.00 sol=0 age=0.37
Info - LoopTime: 7 - 2 - 3.00 - 7ms
0:0:31 ctlDur=0.02 freem=211187 sp=20000068 bat=26.52,-0.000(0.86) chg=0.09,0(0.02) diff=-24.522 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=47880800 lon=44.43232252 lat=54.01135760 h=13959.9 n=0.00 e=0.00 d=0.00 sol=0 age=0.37
0:0:36 ctlDur=0.02 freem=211083 sp=2000185C bat=26.51,-0.000(0.97) chg=0.08,0(0.01) diff=-25.740 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=47885800 lon=43.97111102 lat=54.19142134 h=14023.9 n=0.00 e=0.00 d=0.00 sol=0 age=0.36
Info - LoopTime: 6 - 2 - 2.99 - 7ms
0:0:41 ctlDur=0.02 freem=211083 sp=2000185C bat=26.50,-0.000(1.01) chg=0.06,0(0.01) diff=-26.167 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=47890800 lon=44.22832301 lat=53.97032515 h=13945.3 n=0.00 e=0.00 d=0.00 sol=0 age=0.36
GPS time (UTC): dayOfWeek=sun  hour=13
AUTOSTOP: timetable is disabled
AUTOSTART: not defined DOCKING_STATION
0:0:46 ctlDur=0.02 freem=211083 sp=2000185C bat=26.50,-0.000(1.02) chg=0.07,0(0.01) diff=-26.329 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=47895800 lon=11.74844174 lat=49.42123942 h=494.0 n=0.00 e=0.00 d=0.00 sol=0 age=0.37
Info - LoopTime: 7 - 2 - 2.99 - 7ms
0:0:51 ctlDur=0.02 freem=211083 sp=2000185C bat=26.50,-0.000(1.01) chg=0.08,0(0.01) diff=-26.386 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=47900800 lon=11.74844174 lat=49.42123942 h=494.0 n=0.00 e=0.00 d=0.00 sol=0 age=0.39
0:0:56 ctlDur=0.02 freem=211083 sp=2000185C bat=26.49,-0.000(1.02) chg=0.09,0(0.01) diff=-26.398 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=47905800 lon=11.74844174 lat=49.42123942 h=494.0 n=0.00 e=0.00 d=0.00 sol=0 age=0.39
Info - LoopTime: 7 - 2 - 3.00 - 7ms
0:1:1 ctlDur=0.02 freem=210883 sp=2000185C bat=26.48,-0.000(1.02) chg=0.08,0(0.01) diff=-26.397 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=47910800 lon=11.74844174 lat=49.42123942 h=494.0 n=0.00 e=0.00 d=0.00 sol=0 age=0.37
0:1:6 ctlDur=0.02 freem=210883 sp=2000185C bat=26.48,-0.001(1.00) chg=0.07,0(0.01) diff=-26.400 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=47915800 lon=11.74844174 lat=49.42123942 h=494.0 n=0.00 e=0.00 d=0.00 sol=0 age=0.38
Info - LoopTime: 7 - 2 - 2.99 - 7ms
0:1:11 ctlDur=0.02 freem=210883 sp=2000185C bat=26.47,-0.001(1.00) chg=0.09,0(0.01) diff=-26.393 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=47920800 lon=11.74844174 lat=49.42123942 h=494.0 n=0.00 e=0.00 d=0.00 sol=0 age=0.34
batTemp=998  cpuTemp=23
WARN: PID unmet cycle time Ta=0.13 TaMax=0.10
WARN: PID unmet cycle time Ta=0.14 TaMax=0.10
GPS time (UTC): dayOfWeek=sun  hour=13
AUTOSTOP: timetable is disabled
AUTOSTART: not defined DOCKING_STATION
0:1:16 ctlDur=0.02 freem=210883 sp=2000185C bat=26.46,-0.001(1.03) chg=0.09,0(0.01) diff=-26.383 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=47925800 lon=11.74844174 lat=49.42123942 h=494.0 n=0.00 e=0.00 d=0.00 sol=0 age=0.38
Info - LoopTime: 7 - 2 - 3.86 - 102ms
0:1:21 ctlDur=0.02 freem=210883 sp=2000185C bat=26.46,-0.001(0.98) chg=0.10,0(0.01) diff=-26.376 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=47930800 lon=11.74844174 lat=49.42123942 h=494.0 n=0.00 e=0.00 d=0.00 sol=0 age=0.37
0:1:26 ctlDur=0.02 freem=210883 sp=2000185C bat=26.45,-0.001(0.94) chg=0.07,0(0.01) diff=-26.375 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=47935800 lon=11.74844174 lat=49.42123942 h=494.0 n=0.00 e=0.00 d=0.00 sol=0 age=0.39
Info - LoopTime: 9 - 2 - 3.01 - 9ms
0:1:31 ctlDur=0.02 freem=210883 sp=20000068 bat=26.45,-0.001(0.93) chg=0.07,0(0.01) diff=-26.376 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=47940800 lon=11.74844174 lat=49.42123942 h=494.0 n=0.00 e=0.00 d=0.00 sol=0 age=0.39
0:1:36 ctlDur=0.02 freem=210883 sp=2000185C bat=26.44,-0.001(0.96) chg=0.10,0(0.01) diff=-26.366 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=47945800 lon=11.74844174 lat=49.42123942 h=494.0 n=0.00 e=0.00 d=0.00 sol=0 age=0.61
Info - LoopTime: 2 - 2 - 2.99 - 8ms
0:1:41 ctlDur=0.02 freem=210883 sp=2000185C bat=26.44,-0.001(0.96) chg=0.08,0(0.01) diff=-26.360 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=47950800 lon=11.74844174 lat=49.42123942 h=494.0 n=0.00 e=0.00 d=0.00 sol=0 age=0.52
GPS time (UTC): dayOfWeek=sun  hour=13
AUTOSTOP: timetable is disabled
AUTOSTART: not defined DOCKING_STATION
0:1:46 ctlDur=0.02 freem=210883 sp=2000185C bat=26.44,-0.001(0.94) chg=0.07,0(0.01) diff=-26.356 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=47955800 lon=11.74844174 lat=49.42123942 h=494.0 n=0.00 e=0.00 d=0.00 sol=0 age=0.60
Info - LoopTime: 3 - 2 - 3.00 - 8ms
0:1:51 ctlDur=0.02 freem=210883 sp=2000185C bat=26.43,-0.001(0.94) chg=0.10,0(0.01) diff=-26.351 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=47960800 lon=11.74844174 lat=49.42123942 h=494.0 n=0.00 e=0.00 d=0.00 sol=0 age=0.60
0:1:56 ctlDur=0.02 freem=210883 sp=2000185C bat=26.43,-0.001(0.92) chg=0.08,0(0.01) diff=-26.347 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=47965800 lon=11.74844174 lat=49.42123942 h=494.0 n=0.00 e=0.00 d=0.00 sol=0 age=0.43
Info - LoopTime: 3 - 2 - 2.99 - 8ms
0:2:1 ctlDur=0.02 freem=210883 sp=2000185C bat=26.42,-0.001(0.92) chg=0.08,0(0.01) diff=-26.340 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=47970800 lon=11.74844174 lat=49.42123942 h=494.0 n=0.00 e=0.00 d=0.00 sol=0 age=0.41
0:2:6 ctlDur=0.02 freem=210883 sp=2000185C bat=26.42,-0.001(0.92) chg=0.08,0(0.01) diff=-26.339 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=47975800 lon=11.74844174 lat=49.42123942 h=494.0 n=0.00 e=0.00 d=0.00 sol=0 age=0.36
Info - LoopTime: 2 - 2 - 2.97 - 8ms
0:2:11 ctlDur=0.02 freem=210883 sp=2000185C bat=26.42,-0.001(0.92) chg=0.10,0(0.01) diff=-26.335 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=47980800 lon=11.74844174 lat=49.42123942 h=494.0 n=0.00 e=0.00 d=0.00 sol=0 age=0.61
batTemp=998  cpuTemp=24
WARN: PID unmet cycle time Ta=0.10 TaMax=0.10
GPS time (UTC): dayOfWeek=sun  hour=13
AUTOSTOP: timetable is disabled
AUTOSTART: not defined DOCKING_STATION
0:2:16 ctlDur=0.02 freem=210883 sp=2000185C bat=26.41,-0.001(0.92) chg=0.08,0(0.01) diff=-26.329 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=47985800 lon=11.74844174 lat=49.42123942 h=494.0 n=0.00 e=0.00 d=0.00 sol=0 age=0.40
Info - LoopTime: 7 - 2 - 3.82 - 103ms
0:2:21 ctlDur=0.02 freem=210883 sp=2000185C bat=26.41,-0.001(0.91) chg=0.08,0(0.01) diff=-26.325 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=47990800 lon=11.74844174 lat=49.42123942 h=494.0 n=0.00 e=0.00 d=0.00 sol=0 age=0.32
0:2:26 ctlDur=0.02 freem=210883 sp=2000185C bat=26.41,-0.001(0.95) chg=0.10,0(0.01) diff=-26.320 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=47995800 lon=11.74844174 lat=49.42123942 h=494.0 n=0.00 e=0.00 d=0.00 sol=0 age=0.31
Info - LoopTime: 7 - 2 - 2.98 - 7ms
0:2:31 ctlDur=0.02 freem=210883 sp=2000185C bat=26.40,-0.001(0.95) chg=0.10,0(0.01) diff=-26.314 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=48000800 lon=11.74844174 lat=49.42123942 h=494.0 n=0.00 e=0.00 d=0.00 sol=0 age=0.38
0:2:36 ctlDur=0.02 freem=210883 sp=2000185C bat=26.40,-0.001(0.91) chg=0.09,0(0.01) diff=-26.308 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=48005800 lon=11.74840912 lat=49.42125482 h=549.2 n=0.00 e=0.00 d=0.00 sol=0 age=0.37
Info - LoopTime: 7 - 2 - 2.99 - 7ms
0:2:41 ctlDur=0.02 freem=210883 sp=2000185C bat=26.40,-0.001(0.93) chg=0.10,0(0.01) diff=-26.302 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=48010800 lon=11.74841283 lat=49.42124423 h=549.4 n=0.00 e=0.00 d=0.00 sol=0 age=0.23
GPS time (UTC): dayOfWeek=sun  hour=13
AUTOSTOP: timetable is disabled
AUTOSTART: not defined DOCKING_STATION
0:2:46 ctlDur=0.02 freem=210883 sp=20000068 bat=26.39,-0.002(0.90) chg=0.08,0(0.01) diff=-26.304 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=48015800 lon=11.74842232 lat=49.42123145 h=549.6 n=0.00 e=0.00 d=0.00 sol=0 age=0.40
Info - LoopTime: 9 - 2 - 3.01 - 9ms
0:2:51 ctlDur=0.02 freem=210883 sp=2000185C bat=26.39,-0.002(0.89) chg=0.09,0(0.01) diff=-26.300 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=48020800 lon=11.74841633 lat=49.42123211 h=549.0 n=0.00 e=0.00 d=0.00 sol=0 age=0.67
0:2:56 ctlDur=0.02 freem=210883 sp=20000068 bat=26.38,-0.002(0.87) chg=0.07,0(0.01) diff=-26.300 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=48025800 lon=11.74841633 lat=49.42123211 h=549.0 n=0.00 e=0.00 d=0.00 sol=0 age=0.40
Info - LoopTime: 7 - 2 - 2.98 - 7ms
0:3:1 ctlDur=0.02 freem=210883 sp=2000185C bat=26.38,-0.002(0.91) chg=0.09,0(0.01) diff=-26.296 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=48030800 lon=11.74842171 lat=49.42122011 h=549.9 n=0.00 e=0.00 d=0.00 sol=0 age=0.61
0:3:7 ctlDur=0.02 freem=210883 sp=2000185C bat=26.38,-0.002(0.88) chg=0.10,0(0.01) diff=-26.293 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=48035800 lon=11.74842543 lat=49.42121322 h=550.9 n=0.00 e=0.00 d=0.00 sol=0 age=1.42
Info - LoopTime: 7 - 2 - 2.99 - 8ms
0:3:12 ctlDur=0.02 freem=210883 sp=2000185C bat=26.38,-0.002(0.87) chg=0.10,0(0.01) diff=-26.288 tg=0.00,0.00 x=-36.35 y=-2.64 delta=1.66 tow=48040800 lon=11.74842013 lat=49.42120773 h=550.2 n=0.00 e=0.00 d=0.00 sol=0 age=0.62
GPS jump: 41.01
batTemp=998  cpuTemp=26
WARN: PID unmet cycle time Ta=0.12 TaMax=0.10
GPS time (UTC): dayOfWeek=sun  hour=13
AUTOSTOP: timetable is disabled
AUTOSTART: not defined DOCKING_STATION
0:3:17 ctlDur=0.02 freem=210883 sp=2000185C bat=26.38,-0.002(0.88) chg=0.09,0(0.01) diff=-26.283 tg=0.00,0.00 x=-33.10 y=-23.94 delta=1.66 tow=48045800 lon=11.74842502 lat=49.42120711 h=550.7 n=0.00 e=0.00 d=0.00 sol=0 age=0.33
Info - LoopTime: 8 - 2 - 3.76 - 102ms
0:3:22 ctlDur=0.02 freem=210883 sp=20000068 bat=26.37,-0.002(0.88) chg=0.08,0(0.01) diff=-26.284 tg=0.00,0.00 x=-33.10 y=-23.94 delta=1.66 tow=48050800 lon=11.74842160 lat=49.42120013 h=550.6 n=0.00 e=0.00 d=0.00 sol=0 age=0.42
0:3:27 ctlDur=0.02 freem=210883 sp=2000185C bat=26.36,-0.002(0.86) chg=0.08,0(0.01) diff=-26.283 tg=0.00,0.00 x=-33.10 y=-23.94 delta=1.66 tow=48055800 lon=11.74842202 lat=49.42119705 h=550.6 n=0.00 e=0.00 d=0.00 sol=0 age=0.37
Info - LoopTime: 6 - 2 - 2.98 - 6ms
0:3:32 ctlDur=0.02 freem=210883 sp=2000185C bat=26.36,-0.002(0.82) chg=0.11,0(0.01) diff=-26.272 tg=0.00,0.00 x=-33.10 y=-23.94 delta=1.66 tow=48060800 lon=11.74842084 lat=49.42119325 h=550.6 n=0.00 e=0.00 d=0.00 sol=0 age=0.60
0:3:37 ctlDur=0.02 freem=210883 sp=2000185C bat=26.36,-0.002(0.83) chg=0.07,0(0.01) diff=-26.272 tg=0.00,0.00 x=-33.10 y=-23.94 delta=1.66 tow=48065800 lon=11.74841714 lat=49.42119412 h=550.3 n=0.00 e=0.00 d=0.00 sol=0 age=0.60
Info - LoopTime: 8 - 2 - 2.99 - 8ms

ich ergänze mal meinen ersten Beitrag um die Modifikation am Pimoroni
 
Zuletzt bearbeitet:
  • Like
Reaktionen: f2k
Oben