Du verwendest einen veralteten Browser. Es ist möglich, dass diese oder andere Websites nicht korrekt angezeigt werden.
Du solltest ein Upgrade durchführen oder einen alternativen Browser verwenden.
Du solltest ein Upgrade durchführen oder einen alternativen Browser verwenden.
Ardumower seems drunk when mowing
- Ersteller RedProbe
- Erstellt am

Mr. Tree
Well-known member
Start Tuning with the Default values from config, best is... Leave p at 1 and tune lateral k First. But they Work together, tune with a speedsetting you plan to use, eg 0,40 m/s.
Once its stable, you can Shift both values the Same amount to get a slower or faster reaction to outside path disturbances. I personally tuned p value by deflecting the Mower with my feet at the backhandle. 1 to 1.5 should be good. Understand lateral as a reaction to General path Offset, and angular the difference Angle its looking to its Targetpoint. Both values Work against each other, because If its Offset to path but Looks perfectly to Point, k will try to make IT Turn to the path, but p doesnt Like IT and tries to make the Mower Look to the target Point.
Once its stable, you can Shift both values the Same amount to get a slower or faster reaction to outside path disturbances. I personally tuned p value by deflecting the Mower with my feet at the backhandle. 1 to 1.5 should be good. Understand lateral as a reaction to General path Offset, and angular the difference Angle its looking to its Targetpoint. Both values Work against each other, because If its Offset to path but Looks perfectly to Point, k will try to make IT Turn to the path, but p doesnt Like IT and tries to make the Mower Look to the target Point.
I've been trying and tuning the config of the mower.
I ran into a bug with the ODO test that I had to raise the PWM for the last part.
Since then I've reduced the ticks to what I expected it to be (as per default config)
That now looks fine.
The main problem I still run into, is that the mower overshoots the 180 degree turn when mowing lines.
After that it makes a S curve to get back on the line. Depending on the Stanley values this is happening fast or slow.
What I don't get is why it's not making the 180 degree turn in the right way.
Can anyone advise me what to do?
Mr. Tree
Well-known member
Basically, you are running in the same issues i observed with sunray behaviour too and started to tune or rewrite some code.
It´s now at an extend that alot of the kinematics and sensors.. obstacle etc is new or modified to a huge extend.
What you see has the culprit in linetracker.cpp, there is an angletotargetfits bool, and the mower is overshooting because its slow on reading the imu and it´s not slowing down when it comes near the target angle. In the orig code, even pwm to traction motors is newly limited to maxPwm or so.. i dont see a sense in that.
it will stop turning when it is +-20° in the target, that makes a possible 40* angletotargetfits == true, you never know where it will land. you can narrow this band, but then you will eventually end up with the mower swinging left,right,left,right.... etc. I did completely rewrite the linetracker and the turnings are exact now. Other thing is, in motor.cpp are some bugs, that make one wheel during turning stop.
Well those are interesting findings! I wasn't aware that such serious 'bugs' are in the official release.
So is it a true statement that there is no release which will have the mower rotate 180 degrees?
I also found this: https://github.com/ShadedSelf/Sunray-CE
Do you use that Mr. Tree? Or do you have several improvements in your own software?
If the turning is not accurate, then mowing lines will never work as expected.
If I recall correctly the official firmware should rotate properly, but I havent used it in a while so maybe thats the problem.
The version you linked is my fork, it has a bunch of bug fixes and improvements, you can try that one or MrTree´s and see if it fixes the issue.
The version you linked is my fork, it has a bunch of bug fixes and improvements, you can try that one or MrTree´s and see if it fixes the issue.

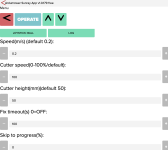
Actually you can use the Sunray app to test Stanley values but they will not be stored permanently. If you have found a good setting, you need to change those values in the config.I'm willing to try a lot, but it sounds complicated! ;-)
Will check that tomorrow.
When I use the grauonline.de/am site, I can not see the stanley setting can I?
I can use the site with the Nuviu browser on IOS, it works good when using ethernet/IP.